
Robohub.org
A mini robot to simplify dental treatment
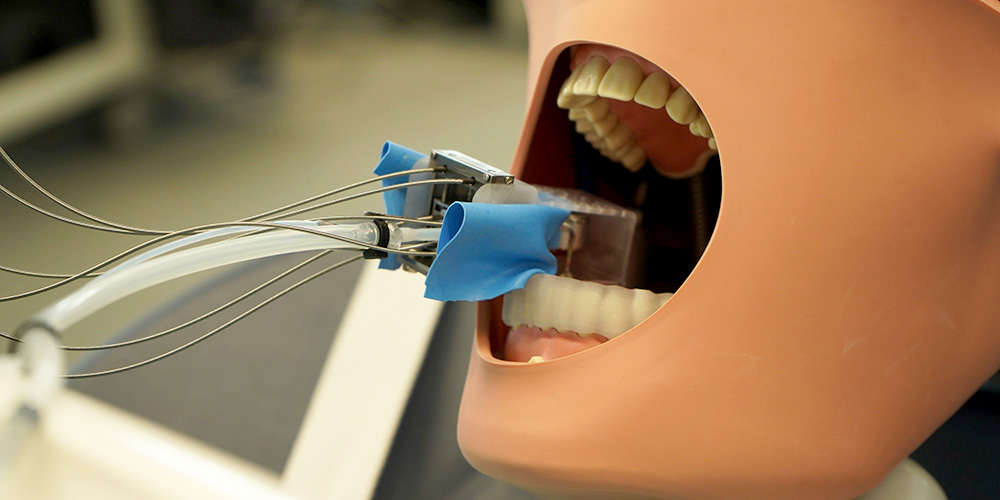 A miniature robot developed at the University of Basel could help prepare teeth for a crown. Photo: University of Basel, Catherine Weyer.
By Angelika Jacobs
A routine check-up at the dentist ends with bad news: tooth decay has left a large cavity, and the tooth needs a crown. The treatment requires several follow-up appointments. During the first appointment, the dentist removes the decay, fills the cavity and prepares the tooth for the crown. She then takes an impression and fits a temporary crown. The permanent crown is produced based on the impression and can only be placed at a later appointment.
In future, this process could become much faster thanks to a small dental robot developed by researchers at the Department of Biomedical Engineering at the University of Basel. The idea came from researchers at the University of Zurich, who were also involved in the development.
The prototype is about the size of a wine cork, measuring just 43 by 26 by 28 millimeters. Its motors and control system are located outside the robot and connected to it via flexible drive shafts, cables and tubes. “It is designed to be small enough to fit comfortably into an open mouth,” says Dr Yukiko Tomooka, first author of the paper in IEEE Transactions on Medical Robotics and Bionics, in which the research team presents the robot.
Fewer appointments at the dentist
The prototype, called “MIR” — short for “Miniature Intraoral Robot” — is designed to prepare teeth precisely according to a digital plan. The idea is that, after a scan during the first appointment, dentists could plan exactly how the robot should remove the tooth material and order the crown straight away, rather than waiting until a second appointment.
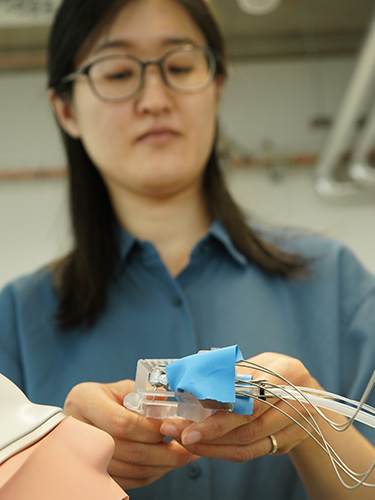 Dr Yukiko Tomooka mounting the dental robot on a model patient. Photo: University of Basel, Catherine Weyer.
Remarkably precise dental robot
The researchers tested their dental robot on tooth models made of synthetic resin and on a ceramic material with a hardness similar to that of tooth enamel. The robot prepares the tooth in two steps: first, it uses a wide drill to reduce the tooth surface, removing material from above. In the second step, a longer, thinner drill works on the sides of the tooth.
What is remarkable is how precisely the dental robot already works, even though it does not yet have any sensors to measure or even correct its position directly. In tests, the positional error was less than 0.2 millimeters, which will be further reduced after sensors are integrated into the system.
In addition to precision, the researchers are also measuring the forces generated during drilling. In the tests, these remained below five newtons, roughly equivalent to the gravitational force of a half-liter bottle of water. The team is also investigating the noise produced by the system in order to better assess its suitability for use in dental practice.
Sensors and camera to follow
Further work is still needed before MIR can be used in dental practices. As a next step, the researchers plan to integrate sensors and a camera into the robot so that the system can monitor its position and the progress of the treatment. “Even after a power outage, MIR would know where it is and where it needs to continue based on the sensor data,” explains research group leader Professor Georg Rauter. The aim is to achieve this without making the mini robot any larger.
Rauter’s team regularly works closely with practicing physicians and dentists to develop robots for medical applications. The dental robot was developed as part of an Innosuisse-funded project in collaboration with the Center for Dentistry at the University of Zurich, Basel-based Camlog Biotechnologies GmbH and the University of Bern.
Read the work in full
Miniature Intraoral Robot (MIR) for Minimally Invasive Tooth Preparation, Yukiko Tomooka, Carina Schmidt, Jenni Hjerppe, Marc Balmer, Ronald Jung, Raphael Mohler, Ahmet Yildiz, Murali Karnam, Manuela Eugster, Georg Rauter, IEEE Transactions on Medical Robotics and Bionics (2026).
AUAI is supported by:










