
Robohub.org
Black in Robotics ‘Meet The Members’ series: Nialah Wilson
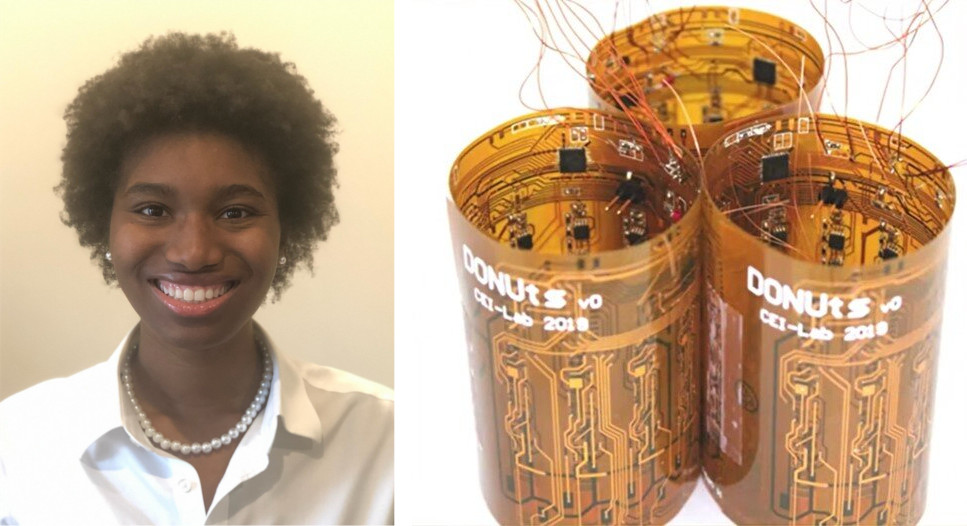
The roboticist Nialah Wilson along with the modular robot platform DONUts. [Image Credit: Scalable and Robust Fabrication, Operation, and Control of Compliant Modular Robots by Wilson*, Ceron*, Wilson, Horowitz and Petersen.]
The DONUts platform may look like a collection of bronze-colored, futuristic coffee cups, but everything becomes clearer as they begin to move. The group of modular robots dance in a well-choreographed symphony as magnets turn on and off allowing the modules to pull or push their neighbors. Using these simple interactions, the modular robots can achieve complex tasks such as energy harvesting [1].
Nialah Wilson is one of the key roboticists who helped bring these modular robots to life. Her team at the Collective Embodied Intelligence Lab from Cornell University needed to:
- Design the hardware using flexible printed circuit boards,
- Characterize the behavior of each module when the magnets were applied,
- Create the motion planning algorithms, and
- Implement the communication scheme which passes messages to neighbors saying to “turn on” or “turn off” their magnets and thus attract or repel one another.
Taking advantage of the right message, passed at the right time, is also one of the things that led to Nialah’s career in robotics.
One of the competitions that I did in high school was through the NAACP, and I only heard about that because of someone in my church, and I only knew about that because I talked to them.
— Nialah
We are excited to highlight Nialah’s robotics journey as well as the lessons she learned along the way in this ‘Meet the Members’ post for Black In Robotics.
Nialah’s trajectory
Nialah is from rural, Southwestern Virginia. A place that she is sure to remind you is the South. Despite the rural setting, Nialah had a plethora of opportunities to keep her curious mind busy.
I was always interested in taking stuff apart. My mom would always find different things like pens … destroyed around the house.
— Nialah
Her mom was wise enough to channel young Nialah’s knack for constructing and deconstructing devices into a competitive arena: robotics competitions.
“I was all-in” Nialah recalls when she talks about this time in her life. Initially, she was doing FIRST Lego Robotics League competitions in middle school and, later on, she was participating in whatever competitions she could find in high school (one of them being the longstanding tradition hosted by Virginia Western). Nialah’s experience made it a no-brainer for her to decide upon a degree in Mechanical Engineering when she arrived at Howard University.
She leveraged Howard’s powerful connections across the country to obtain a summer position at Sandia National Laboratories. Sandia had a lasting impact on Nialah; not only did she produce great work characterizing bellows systems that was later published [2], but she also found an interest in attending graduate school.
I was interested in grad school before [my internship at Sandia], but after that I was like ‘I gotta do a PhD.’ … I saw that the people doing the leading and pushing stuff forward all had PhDs and so I was like ‘Oh!’ if I get a PhD, then this can be my life…
— Nialah
When the time came to apply to graduate school, her mentor from Sandia was one of the key recommendation letters that supported her strong application.
Ultimately, Nialah picked the Collective Embodied Intelligence Lab at Cornell University for her PhD studies. There, she has moved away from working with experimental fluid theory and now works on many aspects of modular robots like the ones discussed above. To make groups of these robots achieve tasks in unstructured environments, she studies how to plan the group’s movement using gradient-based methods as well as how to make a group robust if an individual robot fails. In the future, she hopes to work more on how groups of such robots or drones interact with humans (i.e. Human Robot Interaction).
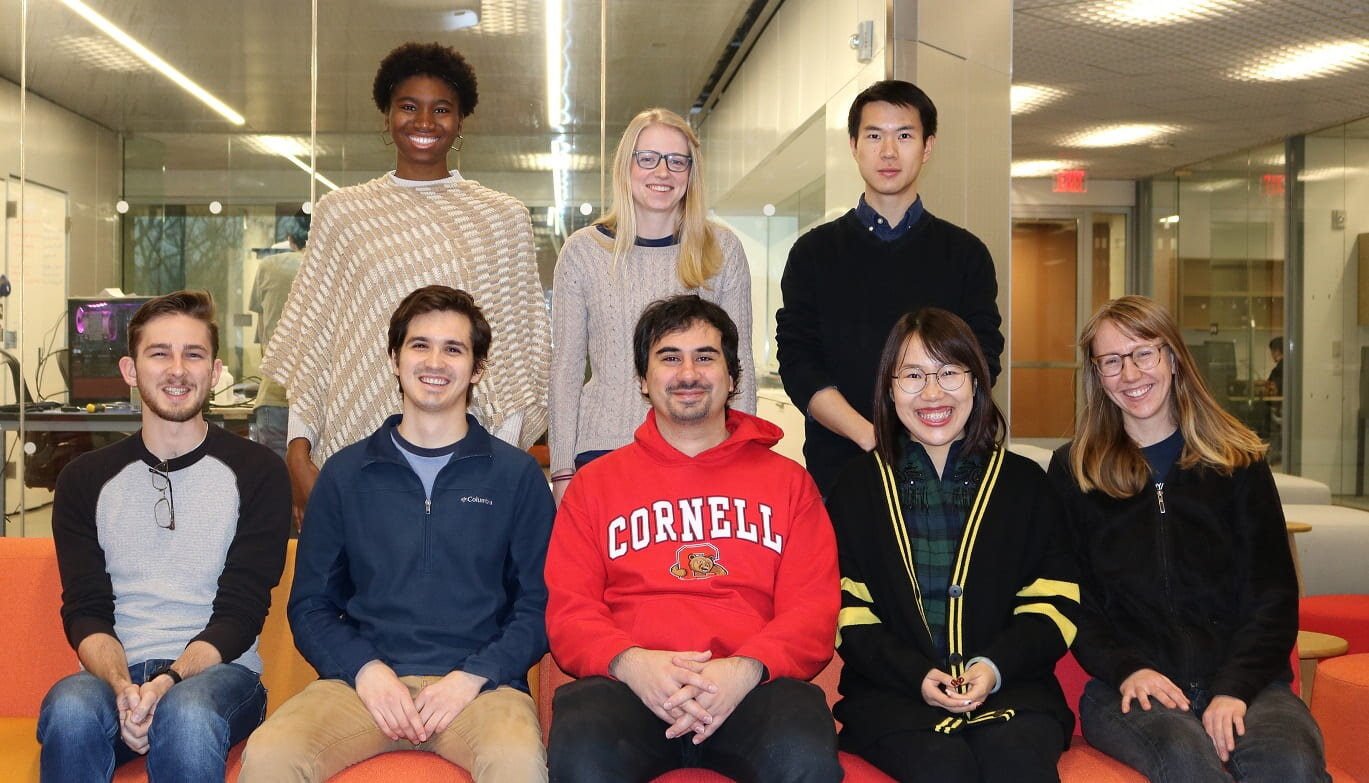
A group photo of the Collective Embodied Intelligence Lab at Cornell University including an excited Ms. Wilson (top left).
Nialah’s challenges
With the support of her strong Sandia mentor and others in her life, Nialah was well-prepared for many aspects of graduate school but highlighted a few challenges that she still had to overcome:
- Developing the research skills beyond what was required of her in her undergraduate experience
- Understanding how publications work and contribute to your progress in a PhD
- Getting used to a new climate (both socially and geographically)
What makes these challenges difficult is that they’re typically all arising at the same time.
I was figuring out [all of this] while taking different courses.
— Nialah
She recommended that graduate students try the following to prevent or overcome these challenges as well:
- Read as many research papers in your area as you can!
- Ask your advisor, or find a mentor, who can explain what’s expected of you and the various milestones required to finish your PhD.
- Step a little outside of your comfort zone to curate new friendships. Having a support system is key!
Nialah’s words of wisdom
Finally, Nialah offered the following words of wisdom for young roboticists:
One thing that I would say [to a younger version of myself] is: Look more into the different aspects of robotics, because robotics is a really big field. And I didn’t fully get [that] until I got to grad school…
— Nialah
And a few words for young people in general:
…that’s the biggest thing; finding people that are in the positions that I want to be in or are around those things and then reaching out to and talking to them. You learn new things and it opens doors for yourself as well.
— Nialah
If you would like to follow more of Nialah’s exploits, then feel free to follow her Google Scholar profile or her personal website.
Citations
[1] S. Ceron, N. Wilson, L. Horowitz and K. Petersen, “Comparative Analysis of Sensors in Rigid and Deformable Modular Robots for Shape Estimation,” 2019 International Symposium on Multi-Robot and Multi-Agent Systems (MRS), New Brunswick, NJ, USA, 2019, pp. 252–258, doi: 10.1109/MRS.2019.8901072.
[2] Nialah Jenae Wilson, “Bellows Characterization for Dynamic Systems with Damping and Multiphase Flow..” United States: N. p., 2015. Web.
Acknowledgements
Drafts of this article were corrected and improved by Nialah Wilson, Sophia Williams, and Nailah Seale. All current errors are the fault of Kwesi Rutledge. Please reach out to him if you spot any!
AUAI is supported by:










