
Robohub.org
Minesweepers: Towards a landmine-free world
Minesweepers International Outdoor Robotic Competition on Humanitarian Demining
Detection and removal of antipersonnel landmines is, at present, a serious problem of political, economical, environmental and humanitarian dimensions in many countries across the world. It is estimated that there are 110 million landmines in the ground right now; one for every 52 inhabitants on the planet. These mines kill or maim more than 5,000 people annually. If demining efforts remain about the same as they are now, and no new mines are laid, it will still take 1100 years to get rid of all the world’s active land mines because current conventional methods of removal are very slow, inefficient, dangerous and costly. Robotic systems can provide efficient, reliable, adaptive and cost effective solutions for the problem of landmines and unexploded ordnance (UXO) contamination.
Minesweepers: Towards a Landmine-free World was initiated in 2012 as the first international outdoor robotic competition on humanitarian demining by the IEEE Robotics and Automation Society – Egypt Chapter, which won the Chapter of the Year Award in IEEE Region 8 that year. It aims to raise public awareness of the seriousness of landmines and UXO contamination and the role of science and technology in addressing these; it also aims to foster robotics research in the area of humanitarian demining by motivating professors, engineers and students to work on innovative solutions for this serious problem.
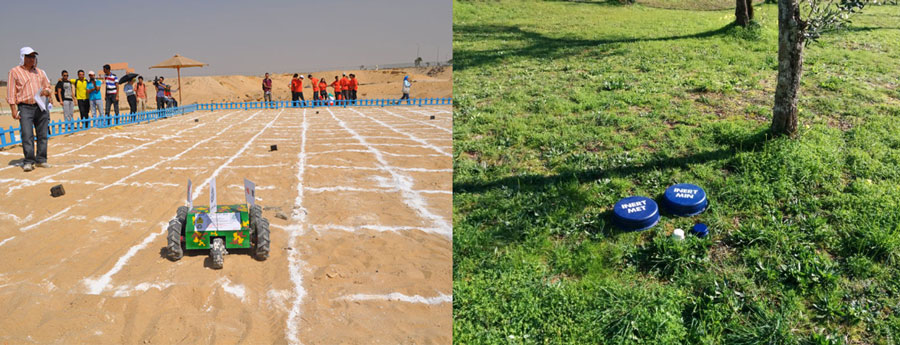
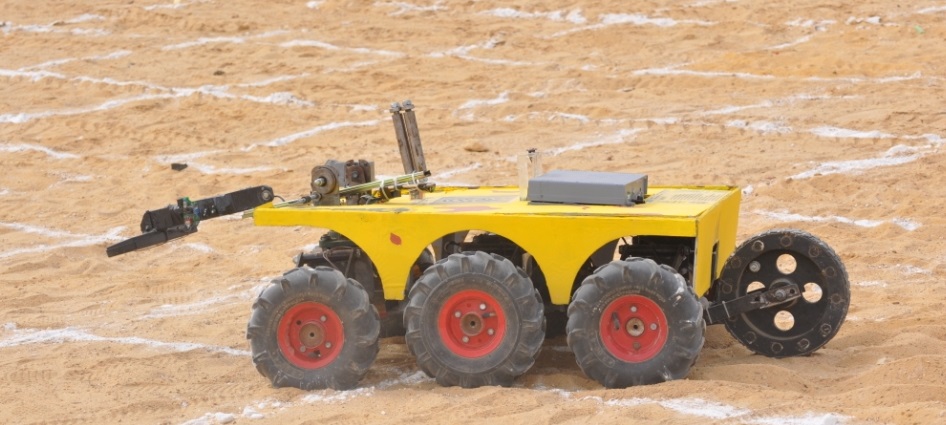
In this competition, each participating team constructs a teleoperated/autonomous unmanned ground/aerial vehicle that must be able to search for underground and aboveground anti-personnel landmines and UXOs. The position and the type of each detected object are visualized and overlaid on the minefield map. The robot must be able to navigate through rough terrain that mimics a real minefield. Teams can participate in one of the following categories:
- Minesweepers – Academia: For undergraduate and postgraduate students where only metallic objects must be detected in the competition arena and landmine detection and minefield mapping are required.
- Minesweepers – Juniors: For elementary and high school students where only metallic objects must be detected in the competition arena and only landmine detection is required.
- Minesweepers – Industry: For professional companies where metallic and non-metallic objects with different dimensions and profiles must be detected in the competition arena, and landmine detection, landmine imaging and minefield mapping are required.
The competition arena of Minesweepers 2014 is an open area with a size of 20 x 20 m, delimited by 4 GPS coordinates. The competition area will be marked by plastic tape for visualization purposes, and there is a virtual fence to stop the robots from going outside the competition area. There are no mines in a stripe of 0.5 m of terrain along the borders of the competition area. Most of the arena is covered by low grass with a few trees, some steep inclines, ditches and culverts.
The ultimate goal of the Minesweepers competition is to put into practice the new strategic mission of IEEE, “…to foster technological innovation and excellence for the benefit of humanity” and to serve as an educational and a research forum to provide efficient, reliable, adaptive and cost-effective solutions for the serious problem of humanitarian demining in many affected countries in the world. The competition also motivates the participants to create new companies and industries geared towards minefield reconnaissance and mapping technologies. Moreover, the applicability of the robotic systems presented in this competition can be extended to a wide range of other applications such as security and surveillance, search and rescue, health monitoring of civil infrastructure, pipeline monitoring, and environment monitoring.
The third edition of Minesweepers is organized by the Institute for Systems and Robotics at University of Coimbra in September 1-3, 2014 under the auspices of IEEE RAS Special Interest Group on Humanitarian Technology (RAS-SIGHT), and in collaboration with IEEE RAS Egypt Chapter and Hadath for Innovation and Entrepreneurship. The competition is technically co-sponsored by IEEE Robotics and Automation Society (RAS) and supported by Executive Secretariat for the Demining & Development of the North West Coast, Mines Action & Human Rights Foundation and Protection against Armaments & Consequences and African Robotics Network (AFRON).
Teams submitting to the eligibility round are requested to submit a technical report and a short video about their robot by July 1, 2014.
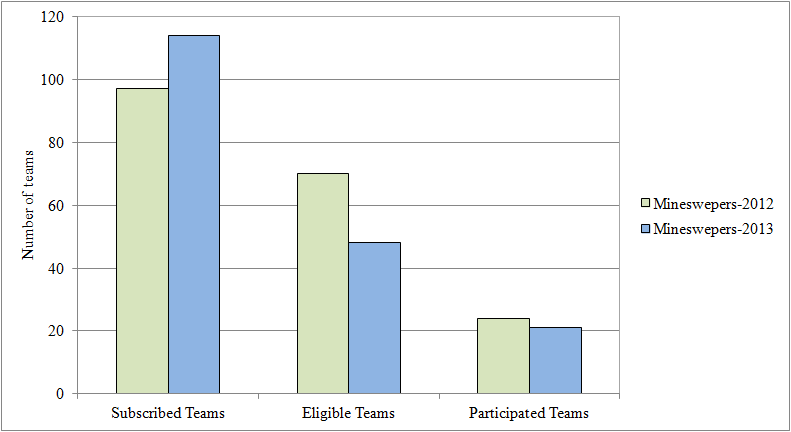
More info
landminefree.org
Frequently-Asked Questions (FAQ)
Facts about Landmines
Resources
Contact
world@landminefree.org
Facebook
Facebook Group
@LandmineFree
If you liked this article, you may also be interested in:
- Introducing the Cybathlon
- Flying Donkey Challenge announces 33 entrants for first subchallenge
- € 7M EuRoC competition opens call to ignite EU manufacturing industry
- Robot Launch 2014 – Robohub People’s Choice Round One
- Show us your AI – AAAI Video Competition
See all the latest robotics news on Robohub, or sign up for our weekly newsletter.
tags: events, exploration & mining, robohub focus on diversity
AUAI is supported by:









