
Robohub.org
SpaceX unveils its next generation Dragon V2
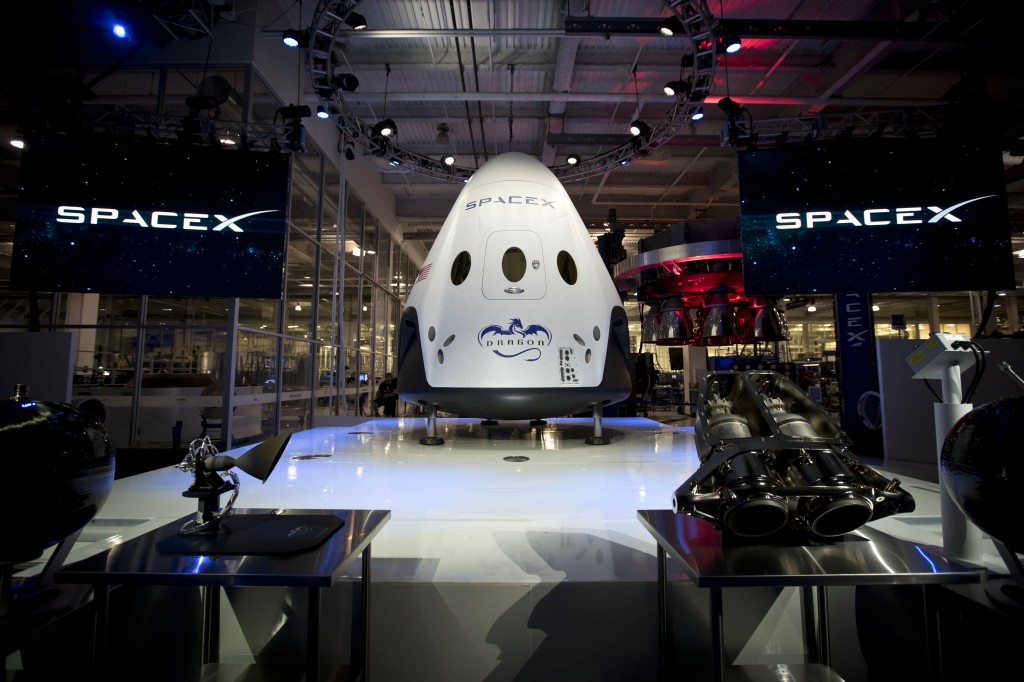
Tonight at 7PM PT SpaceX will reveal Dragon V2 -their next generation spacecraft designed to carry astronauts to space.
UPDATE: read our de-briefing of the presentation below
A brief but as always interesting press conference by Elon Musk presented the new version of the Dragon capsule, with substantial improvements over Dragon v1. You can read our overview below but here are the key points from the presentation:
Even though it had some revolutionary elements, the first Dragon space capsule was relatively conventional. It landed on water and used parachutes for deceleration after re-entry. It had also a basic life support system (although it was never manned).As mentioned, the Dragon v2 will be able to land anywhere in the world upon re-entry, with the accuracy of a helicopter. Its propulsive deceleration and landing will allow its navigation system and/or pilot to pin-point a landing site and touch down on a specific platform. The new Dragon will retain the parachutes of v1 as a backup measure despite its ability to land safely even with 2 superdraco engines off line.Dragon v2 will be able to accommodate seven astronauts for several days, and it has an enhanced life-support system. It will also be able to automatically (and autonomously) dock with the ISS. Currently Dragon capsules require the assistance of the Canadarm robotic arm to dock, although they have some level of autonomy.
Key elements of the updated capsule were unveiled at the event. The advanced pressurized tanks for helium and propellant, CFRP-wrapped titanium spheres, and of course what makes all these possible, the new superDraco engines. 3D printed in Inconel alloy, they are used in pairs (each nested on its own protective nacelle). Also, a new more robust thermal shield will allow the capsule to be re-used many times (~10 times before major refurbishment as mentioned). Elon Musk also entered the spacecraft and gave us a glimpse of the interior and controls. Apart from the very critical controls that are conventional tactile buttons and switches, all systems and monitors are combined in two huge touch screens. Boarding and exiting the capsule looked slightly inconvenient, but it’s probably easier than doing so from a Lotus Elise, and far easier than the gymnastics necessary for a Soyuz capsule.
Take a look at the presentation video and the animation of all Dragon v2 features below:
Below our original post before the press conference:
Dragon V2 will be only the third spacecraft in service capable of carrying humans, along with the Russian Soyuz and the largely experimental Chinese Shenzou. It’ll also be the first American manned orbital spacecraft after the Space Shuttle, and of course the first ever designed and developed under a private initiative.
Even though speculative at this point, the V2 of the Dragon capsule will focus on the following key aspects: re-usability, increased performance, and being rated for human use.
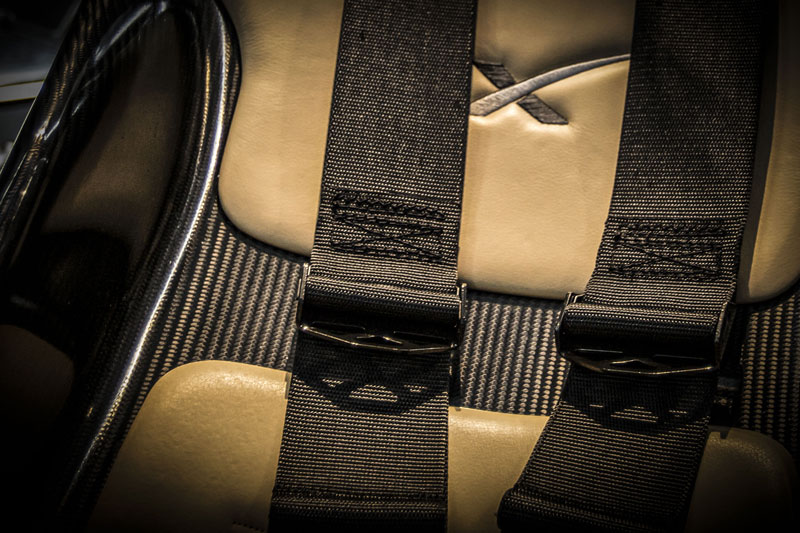
From the start it’s been no secret that SpaceX launch systems had human transportation as a core goal. For a launch system to be rated for human use means that there must be a significant increase in safety margins apart from (but including) all life support systems. As mentioned by Elon Musk himself, a system rated for humans must have a safety factor of 1.4 instead of 1.25, which is the norm for unmanned space systems. Given that SpaceX started from scratch and that the clean sheet approach is essential to their modus operandi, safety margins can be designed from the start to be high enough and turn this inconvenience into an advantage.
The other factor is re-usability. Even though a new Dragon has been used in every launch up until now, the capsule with most of its systems can be refurbished and used again. However the water-landing is a very costly, time consuming and in some cases a risky and dangerous process, especially if it is carrying humans instead of cargo. SpaceX is working towards propulsive landing both for the capsule and the rocket. A prototype landing system was tested recently on Falcon 9R that sent the latest Dragon to the ISS with encouraging results, even if it was over water, while several prototypes have successfully launched, hovered and landed from small altitudes. This would allow the Dragon capsule to land anywhere with accuracy and safety, without mobilizing a small fleet for recovery.
A few days ago SpaceX completed qualification tests for the SuperDraco thrusters, a more advanced and powerful throttle-capable rocket engine that acts both as a launch abort system and as RCS for orbital re-entry and positioning. Additionally, the new more powerful SuperDraco engines on board the new Dragon will allow it not only to land safely with enough power margin for all the necessary manoeuvres but it also could be powerful enough to decelerate the spacecraft from out-of-earth trajectories, to enable visiting an asteroid or even (as the futuristic ‘red’ Dragon) traveling to Mars and back.
tags: Falcon 9, space
AUAI is supported by:










