Robohub.org
 

Automated mining inspection against the odds

by
23 February 2022


share this:

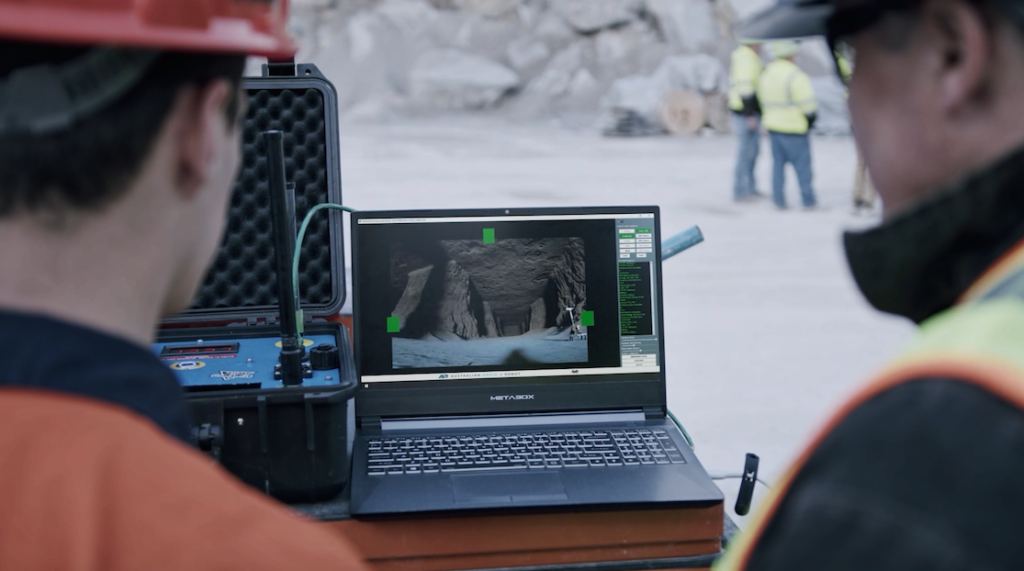
Image from Rajant.

Learn how Rajant Corporation, PBE Group, and Australian Droid + Robot – as part of a #MSHA (U.S. Department of Labor)-backed mine safety mission – achieved a historic unmanned underground mine inspection at one of the US’ largest underground room and pillar limestone operations in this comprehensive IM report.

Using ten ADR Explora XL unmanned robots, a Rajant wireless Kinetic Mesh below-ground communication network, and PBE hardware and technology, a horizontal mobile infrastructure distance of 1.7 km was achieved. This allowed the unmanned robots to record high-definition video and LiDAR to create a virtual 3D mine model to assess the condition of the mine, for the deepest remote underground mine inspection in history.

The inspection made it possible for MSHA to conclude within a very short time that it was safe to re-enter the operation and begin remediation efforts, which included allowing mine personnel back into the mine to re-establish power and communications, after which mining was able to recommence quickly at the site.

The project, in many ways, is the ultimate example of necessity breeding innovation. It also showcased the capability of Rajant wireless mesh networks underground to facilitate autonomous mining operations where underground Wi-Fi would not be up to the task.


tags:


Silicon Valley Robotics is an industry association supporting innovation and commercialization of robotics technologies.

            AUAI is supported by:


Subscribe to Robohub newsletter on substack


Related posts :

Robot Talk Episode 171 – Programming robot behaviour, with Sebastian Castro

  20 Nov 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Sebastian Castro about developing open-source software for robot task planning and behaviour.

Soft exosuit makes it easier to stand up

Robotic system helps users stand up and walk more efficiently.

Robot swarms trained by trial and error in simulation keep working on real robots

  17 Nov 2026
Researchers have developed a new approach to reinforcement learning that helps robot swarms, allowing behaviours learned in simulation to transfer reliably to real-world robots.

Watch the IROS 2026 plenary and keynote talks

  16 Nov 2026
Catch up on the invited presentations from the International Conference on Intelligent Robots and Systems.

Robot Talk Episode 170 – Robots in the real world, with Daniela Shchegelskaya

  13 Nov 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Daniela Shchegelskaya from the University of Twente about getting robots to operate reliably in safety-critical environments.

AI100 report released: embodied AI highlighted as grand challenge

  11 Nov 2026
Embodied AI is listed as one of the most inspiring open grand challenges.

AIhub coffee corner: Are humanoids the future of embodied AI?

  09 Nov 2026
The AIhub coffee corner captures the musings of AI experts over a short conversation.

Robot Talk Episode 169 – Robot sensing inspired by nature, with Dexter Shepherd

  06 Nov 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Dexter Shepherd from the University of Sussex about using artificial intelligence to help robots understand and adapt to their environment.


↑


AUAI is supported by:


Subscribe to Robohub newsletter on substack


©2026.05 - Association for the Understanding of Artificial Intelligence