
Robohub.org
‘Brainless’ robot can navigate complex obstacles
By Matt Shipman
Researchers who created a soft robot that could navigate simple mazes without human or computer direction have now built on that work, creating a “brainless” soft robot that can navigate more complex and dynamic environments.
“In our earlier work, we demonstrated that our soft robot was able to twist and turn its way through a very simple obstacle course,” says Jie Yin, co-corresponding author of a paper on the work and an associate professor of mechanical and aerospace engineering at North Carolina State University. “However, it was unable to turn unless it encountered an obstacle. In practical terms this meant that the robot could sometimes get stuck, bouncing back and forth between parallel obstacles.
“We’ve developed a new soft robot that is capable of turning on its own, allowing it to make its way through twisty mazes, even negotiating its way around moving obstacles. And it’s all done using physical intelligence, rather than being guided by a computer.”
Physical intelligence refers to dynamic objects – like soft robots – whose behavior is governed by their structural design and the materials they are made of, rather than being directed by a computer or human intervention.
As with the earlier version, the new soft robots are made of ribbon-like liquid crystal elastomers. When the robots are placed on a surface that is at least 55 degrees Celsius (131 degrees Fahrenheit), which is hotter than the ambient air, the portion of the ribbon touching the surface contracts, while the portion of the ribbon exposed to the air does not. This induces a rolling motion; the warmer the surface, the faster the robot rolls.
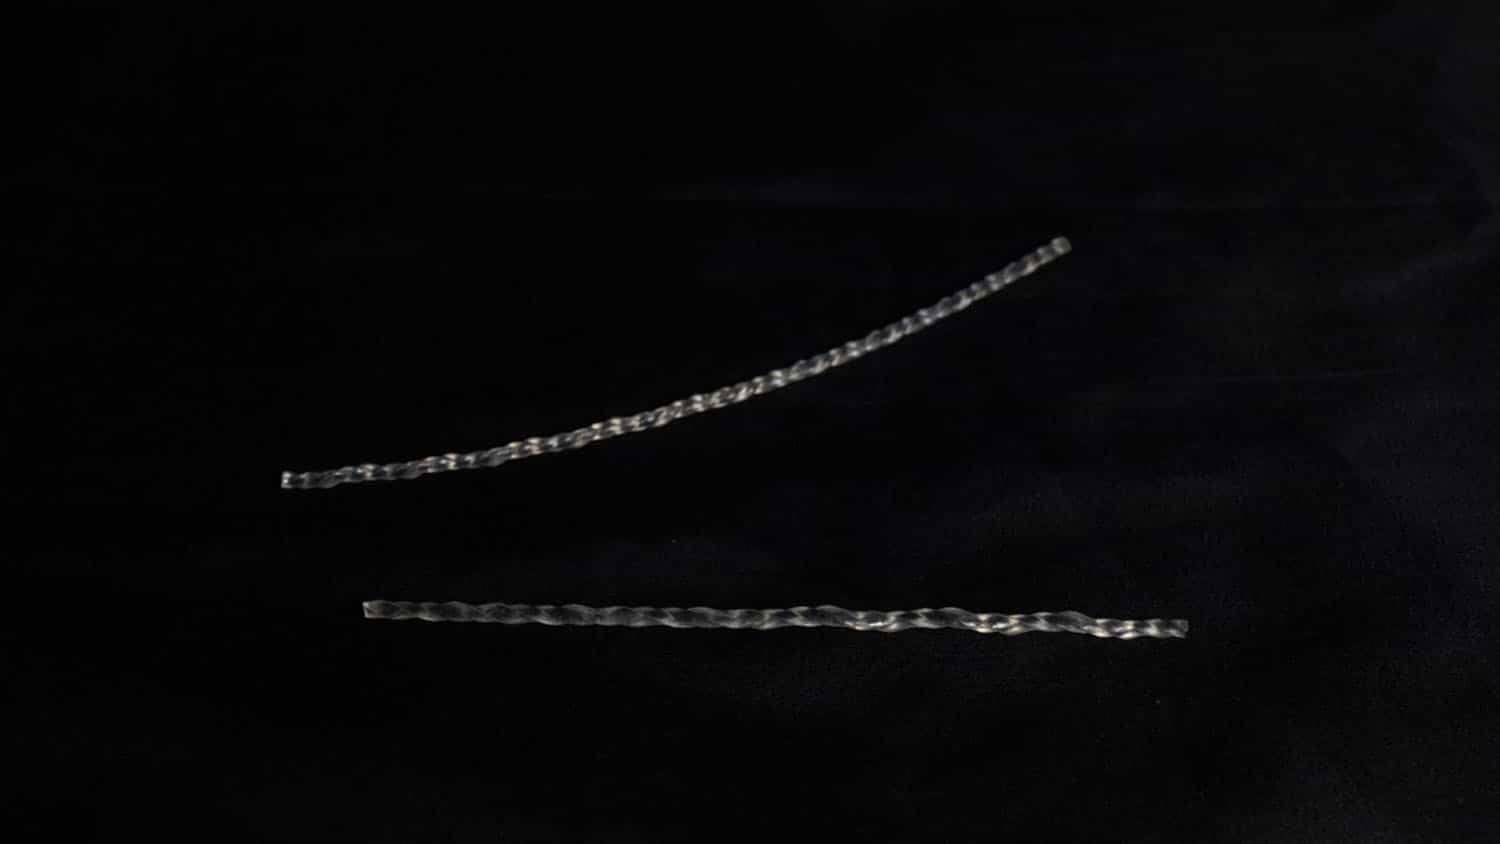
However, while the previous version of the soft robot had a symmetrical design, the new robot has two distinct halves. One half of the robot is shaped like a twisted ribbon that extends in a straight line, while the other half is shaped like a more tightly twisted ribbon that also twists around itself like a spiral staircase.
This asymmetrical design means that one end of the robot exerts more force on the ground than the other end. Think of a plastic cup that has a mouth wider than its base. If you roll it across the table, it doesn’t roll in a straight line – it makes an arc as it travels across the table. That’s due to its asymmetrical shape.
“The concept behind our new robot is fairly simple: because of its asymmetrical design, it turns without having to come into contact with an object,” says Yao Zhao, first author of the paper and a postdoctoral researcher at NC State. “So, while it still changes directions when it does come into contact with an object – allowing it to navigate mazes – it cannot get stuck between parallel objects. Instead, its ability to move in arcs allows it to essentially wiggle its way free.”
The researchers demonstrated the ability of the asymmetrical soft robot design to navigate more complex mazes – including mazes with moving walls – and fit through spaces narrower than its body size. The researchers tested the new robot design on both a metal surface and in sand.
“This work is another step forward in helping us develop innovative approaches to soft robot design – particularly for applications where soft robots would be able to harvest heat energy from their environment,” Yin says.
The paper, “Physically Intelligent Autonomous Soft Robotic Maze Escaper,” appears in the journal Science Advances. First author of the paper is Yao Zhao, a postdoctoral researcher at NC State. Hao Su, an associate professor of mechanical and aerospace engineering at NC State, is co-corresponding author. Additional co-authors include Yaoye Hong, a recent Ph.D. graduate of NC State; Yanbin Li, a postdoctoral researcher at NC State; and Fangjie Qi and Haitao Qing, both Ph.D. students at NC State.
The work was done with support from the National Science Foundation under grants 2005374, 2126072, 1944655 and 2026622.
AUAI is supported by:










