Robohub.org
 

#ERF2017 workshop: Developing the next level Model Driven Robotic Software Ecosystem

by
20 April 2017


share this:

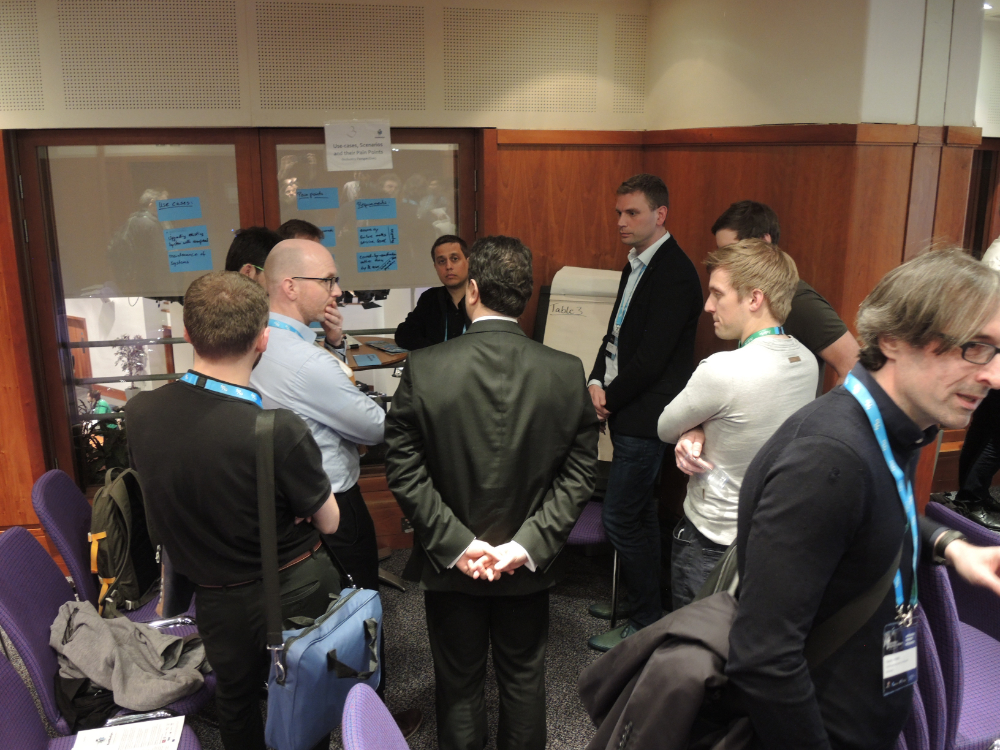
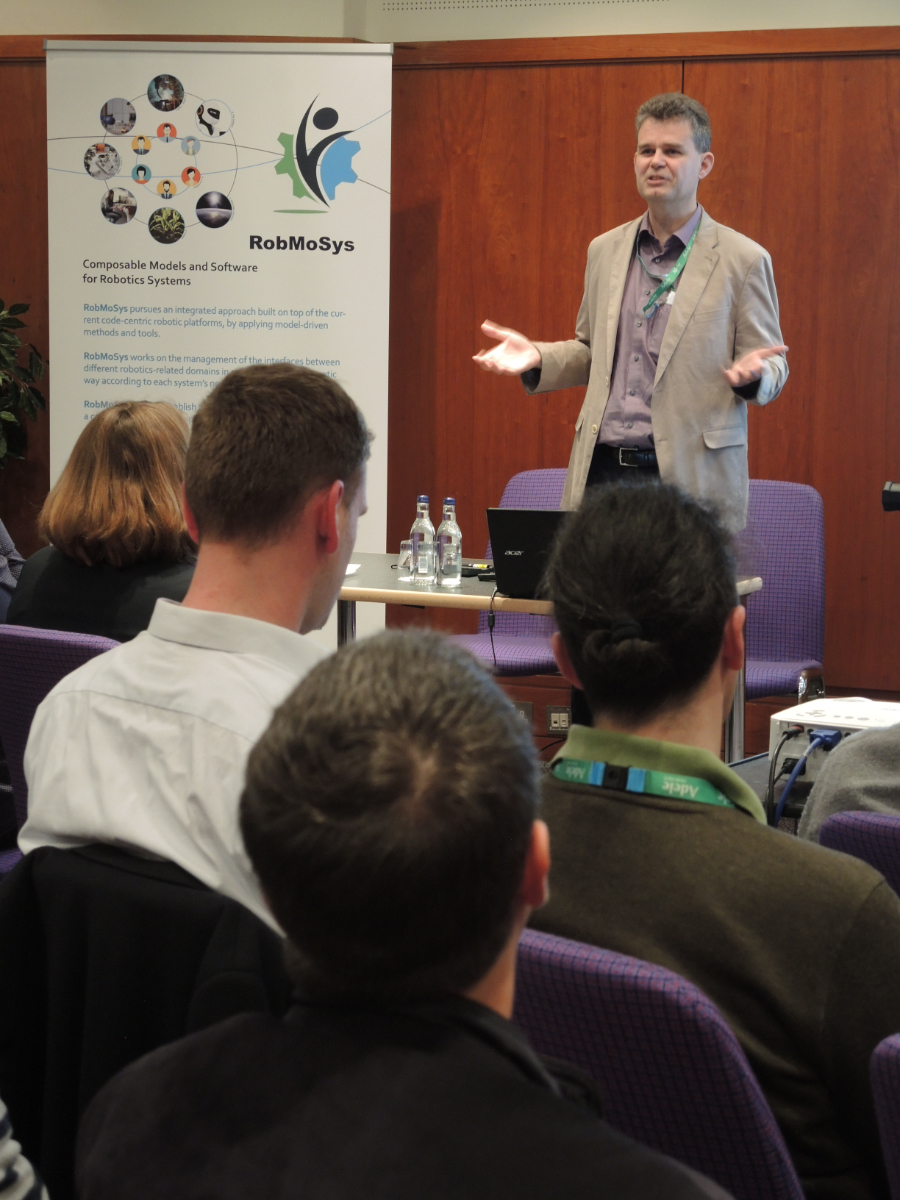
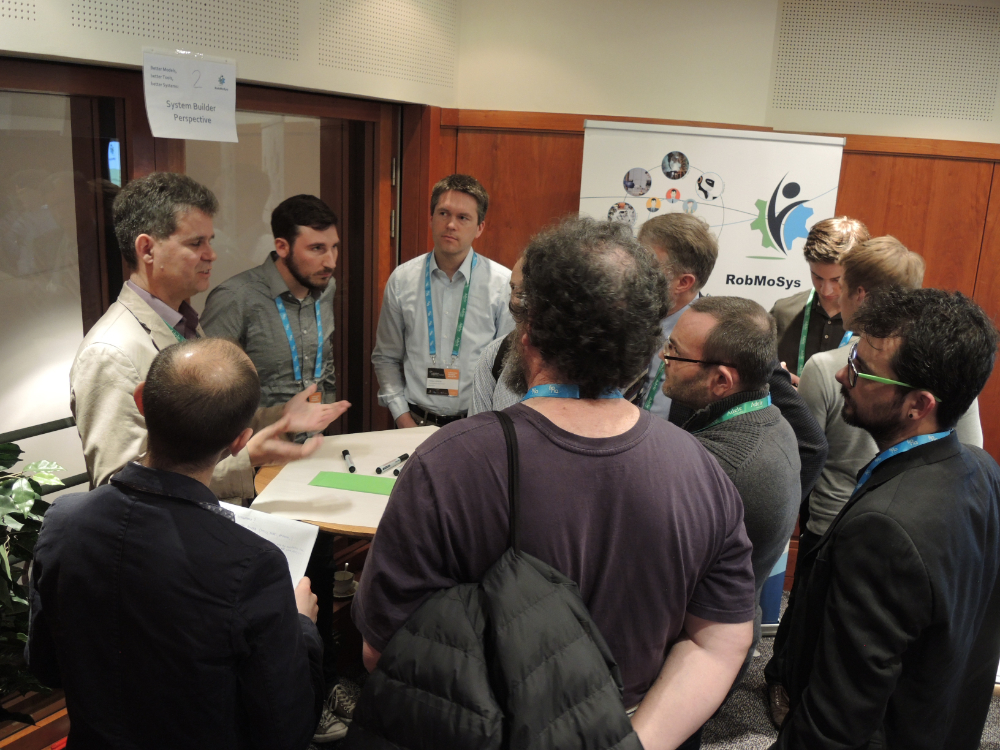
The first public RobMoSys Workshop took place on at the ERF in Edinburgh with more than 50 participants. The room was packed. When the interaction discussions began, the crowd split into small groups to discuss different topics of interest to share experiences and expectations in this workshop.

After a warm welcome and introduction of the two new EU Horizon 2020 ICT26c projects, RobMoSys and ROSIN by Anne Bajart from the European Commission, the open call peculiarities of the individual projects were outlined by Christian Schlegel from HS Ulm (RobMoSys) and by Mirko Bordignon from Fraunhofer IPA (ROSIN). When the interactive part began, the community was asked to share expectations in small groups, focussing on these topics:

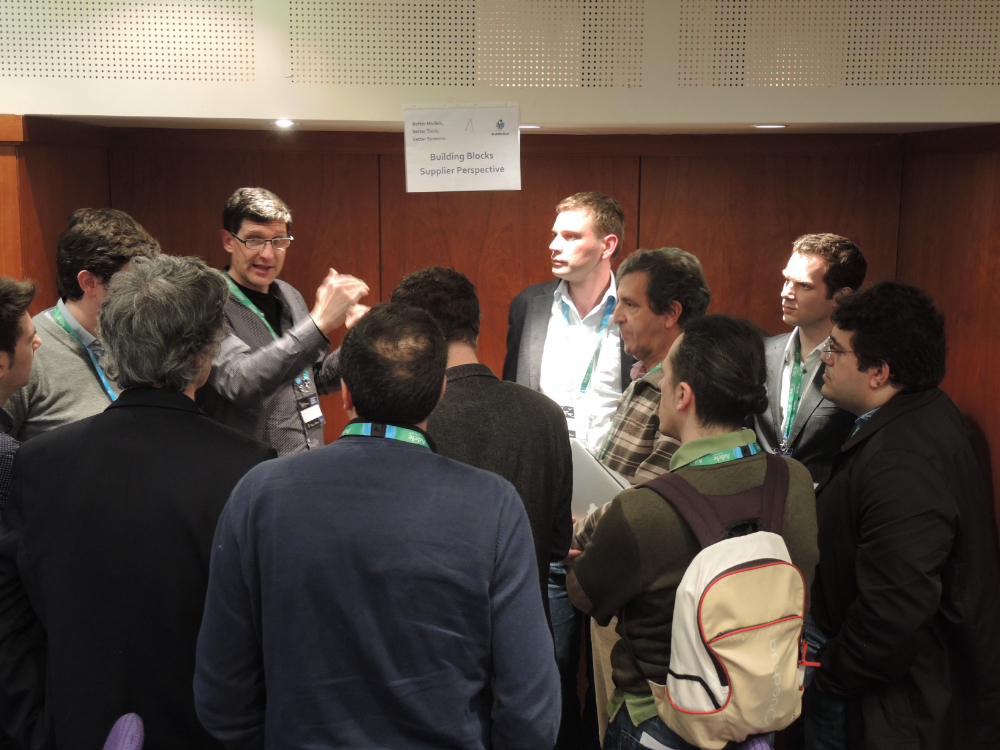
Table 1: Better Models, better Tools, better Systems: Building Blocks Supplier Perspective
From the perspective of a building block supplier: how to make his building block composable and how to explicate and assure properties?

Host: Herman Bruyninckx (KU Leuven)

 Table 2: Better Models, better Tools, better Systems: System Builder Perspective
From the perspective of a system builder who composes systems out of building blocks: How to express and assure relevant system-level properties?
Host: Christian Schlegel (HS Ulm)

Table 3: Use-Cases, Scenarios and their Pain Points (Industry Perspective)

What are Use-Cases/Examples that have an impact?
Host: Francesco Ferro (PAL Robotics)

Table 4: Link between ROSIN and RobMoSys

Q&A towards both projects and their relationship
Host: Mirko Bordignon (Rosin, Fraunhofer IPA), Sara Tucci (CEA)

Further information on the outcome of the ideas and the open calls of RobMoSys will be continuously updated on the RobMoSys website.

ROSIN website can be found here.

Photos from event


tags: ,


Sara Tucci-Piergiovanni is the project coordinator of the RobMoSys project.

            AUAI is supported by:


Subscribe to Robohub newsletter on substack


Related posts :

Soft exosuit makes it easier to stand up

Robotic system helps users stand up and walk more efficiently.

Robot swarms trained by trial and error in simulation keep working on real robots

  17 Nov 2026
Researchers have developed a new approach to reinforcement learning that helps robot swarms, allowing behaviours learned in simulation to transfer reliably to real-world robots.

Watch the IROS 2026 plenary and keynote talks

  16 Nov 2026
Catch up on the invited presentations from the International Conference on Intelligent Robots and Systems.

Robot Talk Episode 170 – Robots in the real world, with Daniela Shchegelskaya

  13 Nov 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Daniela Shchegelskaya from the University of Twente about getting robots to operate reliably in safety-critical environments.

AI100 report released: embodied AI highlighted as grand challenge

  11 Nov 2026
Embodied AI is listed as one of the most inspiring open grand challenges.

AIhub coffee corner: Are humanoids the future of embodied AI?

  09 Nov 2026
The AIhub coffee corner captures the musings of AI experts over a short conversation.

Robot Talk Episode 169 – Robot sensing inspired by nature, with Dexter Shepherd

  06 Nov 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Dexter Shepherd from the University of Sussex about using artificial intelligence to help robots understand and adapt to their environment.

Robots in society, business and culture: October 2026

We showcase a selection of robotics stories from society, business, research and culture.


↑


AUAI is supported by:


Subscribe to Robohub newsletter on substack


©2026.05 - Association for the Understanding of Artificial Intelligence