
Robohub.org
New understanding of insect flight points way to stable flapping-wing robots
By David Nutt
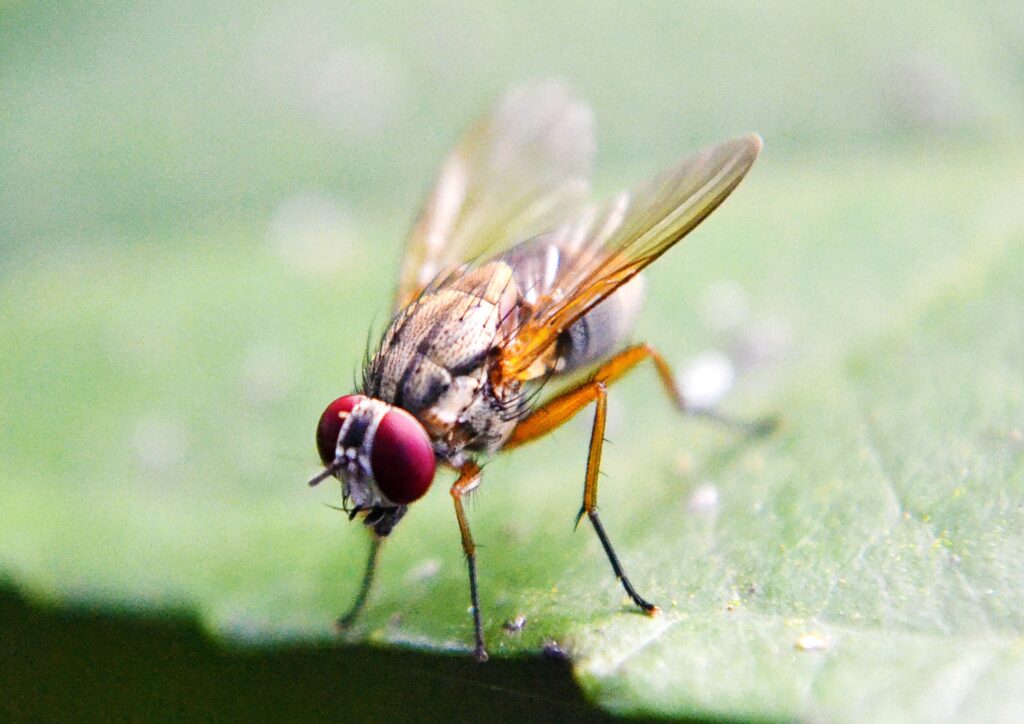
The way bugs and birds flap their wings may look effortless, but the dynamics that keep them aloft are dizzyingly complex and difficult to quantify.
Cornell researchers created a computational model that shows the effect of insects’ morphology on stabilizing their flight. The findings could lead to a new way to understand the evolution of animal flight while also providing a blueprint for designing flapping-wing robots.
The study published May 1 in Proceedings of the National Academy of Sciences. The research was led by Z. Jane Wang, professor of physics and mechanical and aerospace engineering in the College of Arts and Sciences and Cornell Duffield College of Engineering, respectively.
The effort began more than a decade ago, when Wang set out to understand how the neural circuitry in fruit flies evolved to control flight stability. By creating a 3D computational simulation, Wang’s team showed that fruit flies sense the orientation of their bodies every time they beat their wings, about one beat every 4 milliseconds, in order to stabilize themselves.
However, in order to study flight stability in all insects, the researchers would need to build an efficient computational tool to simulate a huge number of species.
“Previous studies, including ours, have always started with models of real insects, so we’re limited by the things we observe,” Wang said. “We miss all the other configurations that are also possible for flight.”
Wang and Owen Wetherbee, the new paper’s first author, distilled the 3D model into a new version that retained the key physics of the body-wing coupling and unsteady aerodynamics. The resulting equations revealed the critical physical parameters: wing to body mass ratio, wing loading, wing hinge position, wing beat frequency and wing motion amplitude. Taken together, they form what Wang calls a “five-dimensional morphological and kinematic space.”
“The power of this model is to give us something much more explicit than what we had before,” she said. “We knew the fundamental physics. By capturing the essential physics in the new model, we can understand each piece conceptually as well as facilitate computation to explore a large parameter space.”
The analyses of the computational results in 5D resulted in two explicit formula that provide a succinct metric for stability. These criteria capture the subtle and often ignored coupling between wing inertia and the body, which depends on the interplay among wing flap frequency, hinge placement, and wing and body mass ratios in order to achieve a kind of anti-resonance state. This sweet spot allows the flapping winged animal to control its body oscillations and remain aloft – a state known as passively stable flight – despite air perturbations that would normally cause it to tumble.
“All of a sudden, we found that many forms of flapping flight have passive stability, which surprised us initially, because works so far showed that most insects, except one or two, are passively unstable, hence the necessity for neural circuitry to control them,” Wang said. “But when we expanded the morphological space, we realized that what we studied before are but a few dots in this new view.”
Now that the researchers can characterize the stability boundary, they can offer a concrete design principle for realizing stable flapping flight in robots – something that has stumped roboticists for decades.
“In principle, this offers a completely new route for designing a robotic flapping-winged machine,” Wang said. “Instead of relying on extensive feedback control, which is only partially successful, our results suggest that we can tune the shape and the frequency of the flapping devices such that, according to these two rules, we may find the flyers are passively stable already. This would greatly simplify flight control.”
The new model allows this design work to be done with faster and simpler computation, and the ability to model stability traits also points to a new way for classifying winged animals and charting their evolution.
“During evolution, various traits are selected, but we don’t have much idea about what they are, let alone understand why they are being selected and how they evolve, apart from a very few examples, such as an eye,” Wang said. “This project brings new quantitative methods to study these very big questions in both biology and robotics. Mathematical modeling allows us to go beyond our own ideas and preconceptions to tackle these large questions.”
The research was supported by the National Science Foundation.
AUAI is supported by:










