
Robohub.org
RoboHouse Interview Trilogy, part I: Christian Geckeler and the origami gripper
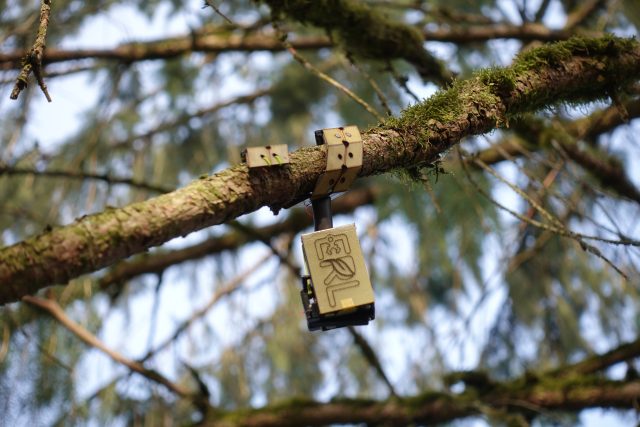
Part one of our RoboHouse Interview Trilogy: The Working Life of Robotics Engineers seeks out Christian Geckeler. Christian is a PhD student at the Environmental Robotics Lab of ETH Zürich. He speaks with Rens van Poppel about the experience of getting high into the wild.
What if drones could help place sensors in forests more easily? What if a sensor device could automatically grab and hold a tree branch? Which flexible material is also strong and biodegradable? These leaps of imagination lead Christian to a new kind of gripper, inspired by the Japanese art of folding.
His origami design wraps itself around tree branches close enough to trigger an unfolding movement. This invention may in the future improve our insight into hard-to-access forest canopies, in a way that is environmentally friendly and pleasant for human operators.
What is it like to work in the forest as a researcher with this technology?
“Robotic solutions deployed in forests are currently scarce,” says Christian. “So developing solutions for such an environment is challenging, but also rewarding. Personally I also enjoy being outdoors. Compared to a lab, the forest is wilder and more unpredictable. Which I find wonderful, except when it’s cold.”
Are there limits as to where the gripper can be deployed?
“The gripper is quite versatile. Rather than the type of trees, it is the diameter and angle of the branch that dictate whether the gripper can attach. Even so, dense foliage could hinder the drone, and there should be sufficient space for the gripper to attach.”
Are the used materials environmentally friendly?
“Currently not all components are biodegradable, and the gripper must be recollected after sampling is finished. However, we are currently working on a fully biodegradable gripper, which releases itself and falls on the ground after being exposed to sufficient amounts of water, which makes collection much easier.”
How good at outdoor living do aspiring tree-canopy researchers need to be?
“Everything is a learning process,” says Christian philosophically. “Rather than existing expertise, a willingness to learn and passion for the subject is much more important.”
What happens when the drone gets stuck in a tree?
“As a safety measure, the drone has a protective net on top which prevents leaves and branches from coming in contact with the propeller. And we avoid interaction between the drone and foliage, so this has never happened.”
What struck you when took the gripper into the wild?
“Perhaps the most surprising thing was the great variance that is found in nature; no two trees are alike and every branch is different. The only way of finding out if your solution works is by testing outside as soon and as often as possible.”
Christian ends with a note on the importance of social and technical interplay in robotics: “You may think you develop a robot perfectly, but you must make sure society actually wants it and that it is easy to use for not technically-minded people too.”
The post RoboHouse Interview Trilogy, Part I: Christian Geckeler and The Origami Gripper appeared first on RoboHouse.

AUAI is supported by:









