
Robohub.org
Robot swarm coordination simplified by use of overhead drones | i-programmer.info
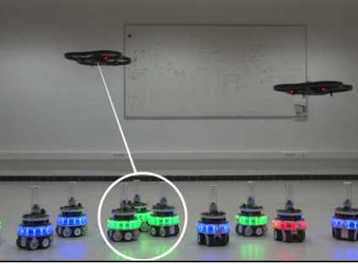
“Swarms of robots don’t all have to be of the same type and one of the best known attempts to build a heterogeneous swarm was the swarmanoid project. Originally the swarmanoid consisted of three types of robot – eyebots, footbots and handbots. Now we have to add a flying drone to provide an aerial overview to the swarm.”
See on www.i-programmer.info
tags: swarm

John Payne
AUAI is supported by:









Related posts :
Robot Talk Episode 171 – Programming robot behaviour, with Sebastian Castro
Robot Talk
20 Nov 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Sebastian Castro about developing open-source software for robot task planning and behaviour.
Soft exosuit makes it easier to stand up
Technical University of Munich
19 Nov 2026
Robotic system helps users stand up and walk more efficiently.
Robot swarms trained by trial and error in simulation keep working on real robots
IRIDIA
17 Nov 2026
Researchers have developed a new approach to reinforcement learning that helps robot swarms, allowing behaviours learned in simulation to transfer reliably to real-world robots.
Watch the IROS 2026 plenary and keynote talks
Lucy Smith
16 Nov 2026
Catch up on the invited presentations from the International Conference on Intelligent Robots and Systems.
Robot Talk Episode 170 – Robots in the real world, with Daniela Shchegelskaya
Robot Talk
13 Nov 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Daniela Shchegelskaya from the University of Twente about getting robots to operate reliably in safety-critical environments.
AI100 report released: embodied AI highlighted as grand challenge
Lucy Smith
11 Nov 2026
Embodied AI is listed as one of the most inspiring open grand challenges.
AIhub coffee corner: Are humanoids the future of embodied AI?
AIhub
09 Nov 2026
The AIhub coffee corner captures the musings of AI experts over a short conversation.
Robot Talk Episode 169 – Robot sensing inspired by nature, with Dexter Shepherd
Robot Talk
06 Nov 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Dexter Shepherd from the University of Sussex about using artificial intelligence to help robots understand and adapt to their environment.

