
Robohub.org
Table tennis robot defeats some of world’s best players – why this has major implications for robotics
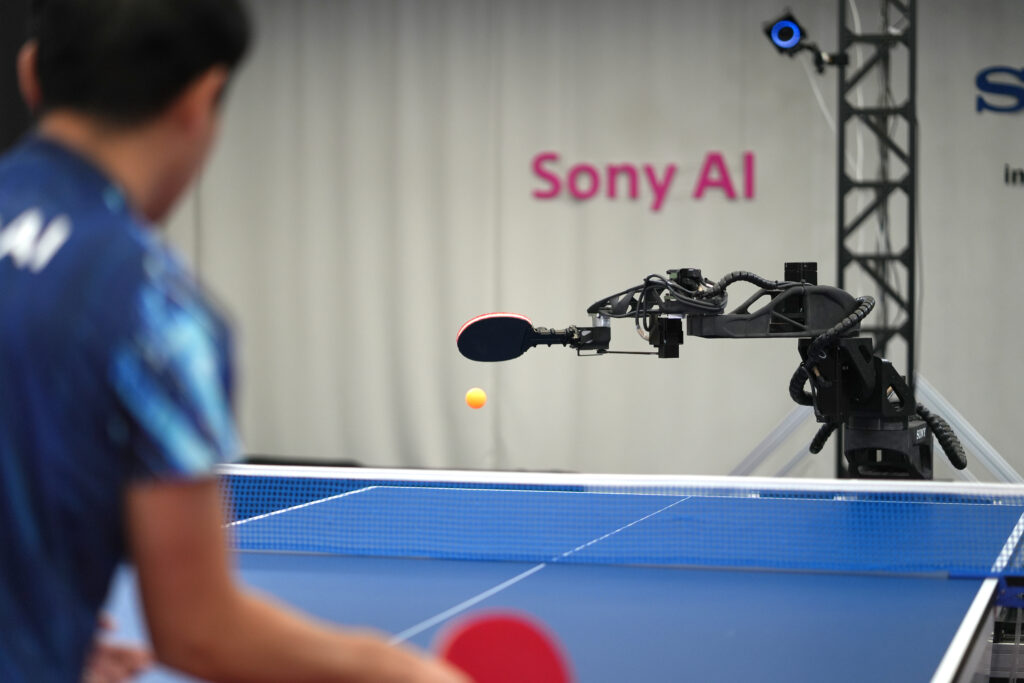 Ace rotates its paddle as it prepares to return the ball back to its human opponent, Yamato Kawamata, during a match in December 2025. Credit: Sony AI.
By Kartikeya Walia, Nottingham Trent University
A table tennis robot has outperformed elite players in recent evaluations. The robot, called Ace, marks a significant step toward artificial intelligence (AI) systems that can operate in fast, uncertain, real-world environments.
In the tests, the autonomous robot won three out of five matches against elite players – competitive athletes with over ten years’ experience and an average of 20 hours weekly training. The robot, developed by Sony AI, lost both matches against players in professional Japanese leagues, but did win a game against one of them. The system is described in detail in a recent paper published in Nature.
AI has spent decades mastering games. It has repeatedly outperformed the best humans in everything from complex video games like StarCraft II to chess – where modern programs now far exceed human ratings.
Landmark systems such as Deep Blue and AlphaGo have confirmed that, given clear rules and enough data, AI can achieve superhuman performance. But these victories all shared one key feature: they happened in controlled, digital environments.
At first glance, table tennis might seem like an unusual benchmark for artificial intelligence. In reality, it is one of the most demanding imaginable. The ball can travel faster than 20 metres per second, giving players less than half a second to react.
On top of that, spin introduces enormous complexity. A ball rotating at extreme speeds can curve mid-air and rebound unpredictably off the table. For humans, interpreting spin is largely intuitive. For robots, it has been a longstanding obstacle.
This robot can beat you at table tennis (Nature).
Earlier table tennis robotic systems such as Forpheus, developed by Japanese company Omron, addressed this by simplifying the game – using controlled ball launchers, limiting movement, or ignoring spin altogether. More recent iterations have aimed for interaction, but still operate under constrained conditions.
Ace does none of this. It plays with standard equipment, on a regulation table,
against human opponents who are free to use the full range of shots.
How Ace works
Ace’s performance relies on three key innovations: how it sees the world, how it
decides what to do, and how it carries out those actions. First, let’s deal with how Ace sees the world. Traditional cameras struggle with fast motion, often producing a blur or missing critical details.
Ace instead uses three “event-based” vision sensors, which detect changes in light rather than capturing full images at fixed intervals. These are complemented by nine high-speed cameras that track the environment, including the opponent and their racket.
Together, these systems enable high-speed gaze control (the technology that enables a robot to direct its sensors to focus on specific things) and allow the robot to follow the ball with exceptional real-time precision.
By tracking markings on the ball, where professional players can generate spin approaching 9,000 revolutions per minute (rpm), the system can estimate spin in real time, something that has long challenged robotic systems.
How Ace’s gaze control system works (Sony AI and Nature).
The second important innovation is how Ace decides what to do. Knowing where the ball is going is only half the problem; the robot must also respond instantly. Ace uses deep reinforcement learning, trained in simulation over millions of virtual rallies, including self-play.
It continuously generates movement commands for its multi-jointed robotic arm, recalculating trajectories every few tens of milliseconds while avoiding collisions with the table or itself.
The third innovation is how Ace carries out its actions. To match the speed of human elite players, the robot is built around a high-performance arm combining two prismatic (sliding) and six revolute (rotational) joints. This enables rapid sideways motion and precise striking. There is both a table tennis racket and a mechanism for ball handling, allowing one-armed serves.
Crucially, the system is engineered for high-speed interaction: lightweight structures and optimised actuation (the mechanisms in a robot that convert energy into mechanical force) allow Ace to return balls at speeds approaching 20 metres per second. This enables sustained, competitive rallies with skilled human players.
Ace makes a split section change when the ball hits the net (Sony AI and Nature).
What makes this particularly notable is the transition from simulation to reality. Many AI systems perform well in virtual environments but fail when exposed to real-world noise and uncertainty. Ace demonstrates that this “sim-to-real” gap can be meaningfully reduced.
One moment during a rally with an elite player illustrates the way that Ace has leapt over this gap. When a predicted ball trajectory suddenly changed after clipping the net, Ace reacted almost instantly, returning the shot and winning the point. What makes Ace particularly significant is therefore not just its performance, but its ability to operate reliably under real-world uncertainty.
Why this matters beyond sport
A robot returning high-speed topspin shots may be entertaining, but the implications go far beyond table tennis. In manufacturing, for example, robots are typically confined to highly structured tasks.
The real challenge is adaptability, handling irregular objects, responding to variation. This is particularly relevant for next-generation robots operating in unstructured environments.
To function effectively in homes, hospitals or construction sites, robots must be able to predict, adapt and respond to constantly changing conditions. The same predictive and control capabilities that allow Ace to respond to unpredictable shots could enable more flexible, responsive automation.
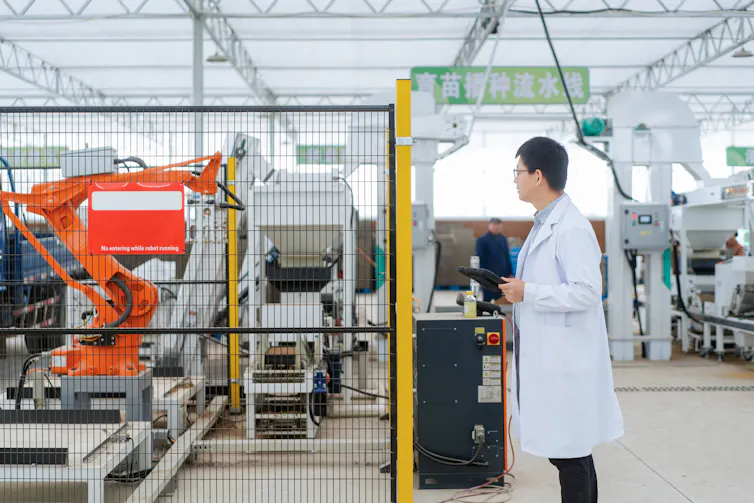 Most industrial robots are kept behind safety barriers because they cannot respond to unexpected human behaviour. Zhu Difeng
There are also implications for human–robot interaction. Most industrial robots are kept behind safety barriers because they cannot react quickly or reliably enough to unexpected human behaviour. Ace operates at the edge of human reaction time, suggesting a future where robots can safely collaborate with people in shared spaces.
More broadly, this work represents a shift in what AI is expected to do. The next frontier is not just intelligence in abstract problem-solving, but intelligence embedded in the physical world. The gap between simulations and reality needs filling, and this is a big step forward.
What humans still do better
Professional players were still able to exploit Ace’s limitations – particularly in reach, speed, and the ability to handle extreme or highly deceptive shots. This highlights that intelligence is not just about prediction and control, but also about physical embodiment. Humans combine perception, movement and strategy in ways that remain difficult to replicate.
Interestingly, systems like Ace may end up enhancing human performance rather
than replacing it. As one former Olympic player observed after facing the robot,
seeing it return seemingly impossible shots suggests humans might be capable of more than previously thought.
Kartikeya Walia, Senior Lecturer, Department of Engineering, Nottingham Trent University
This article is republished from The Conversation under a Creative Commons license. Read the original article.
AUAI is supported by:










