Robohub.org
 

Video: Watch flying robots cooperate, throw and catch balls


by
27 September 2012


share this:

 
My colleagues at the ETH Zurich’s Flying Machine Arena have just released a new video. Here is what Robin Ritz, Lead Researcher on the project, has to say about it:
 

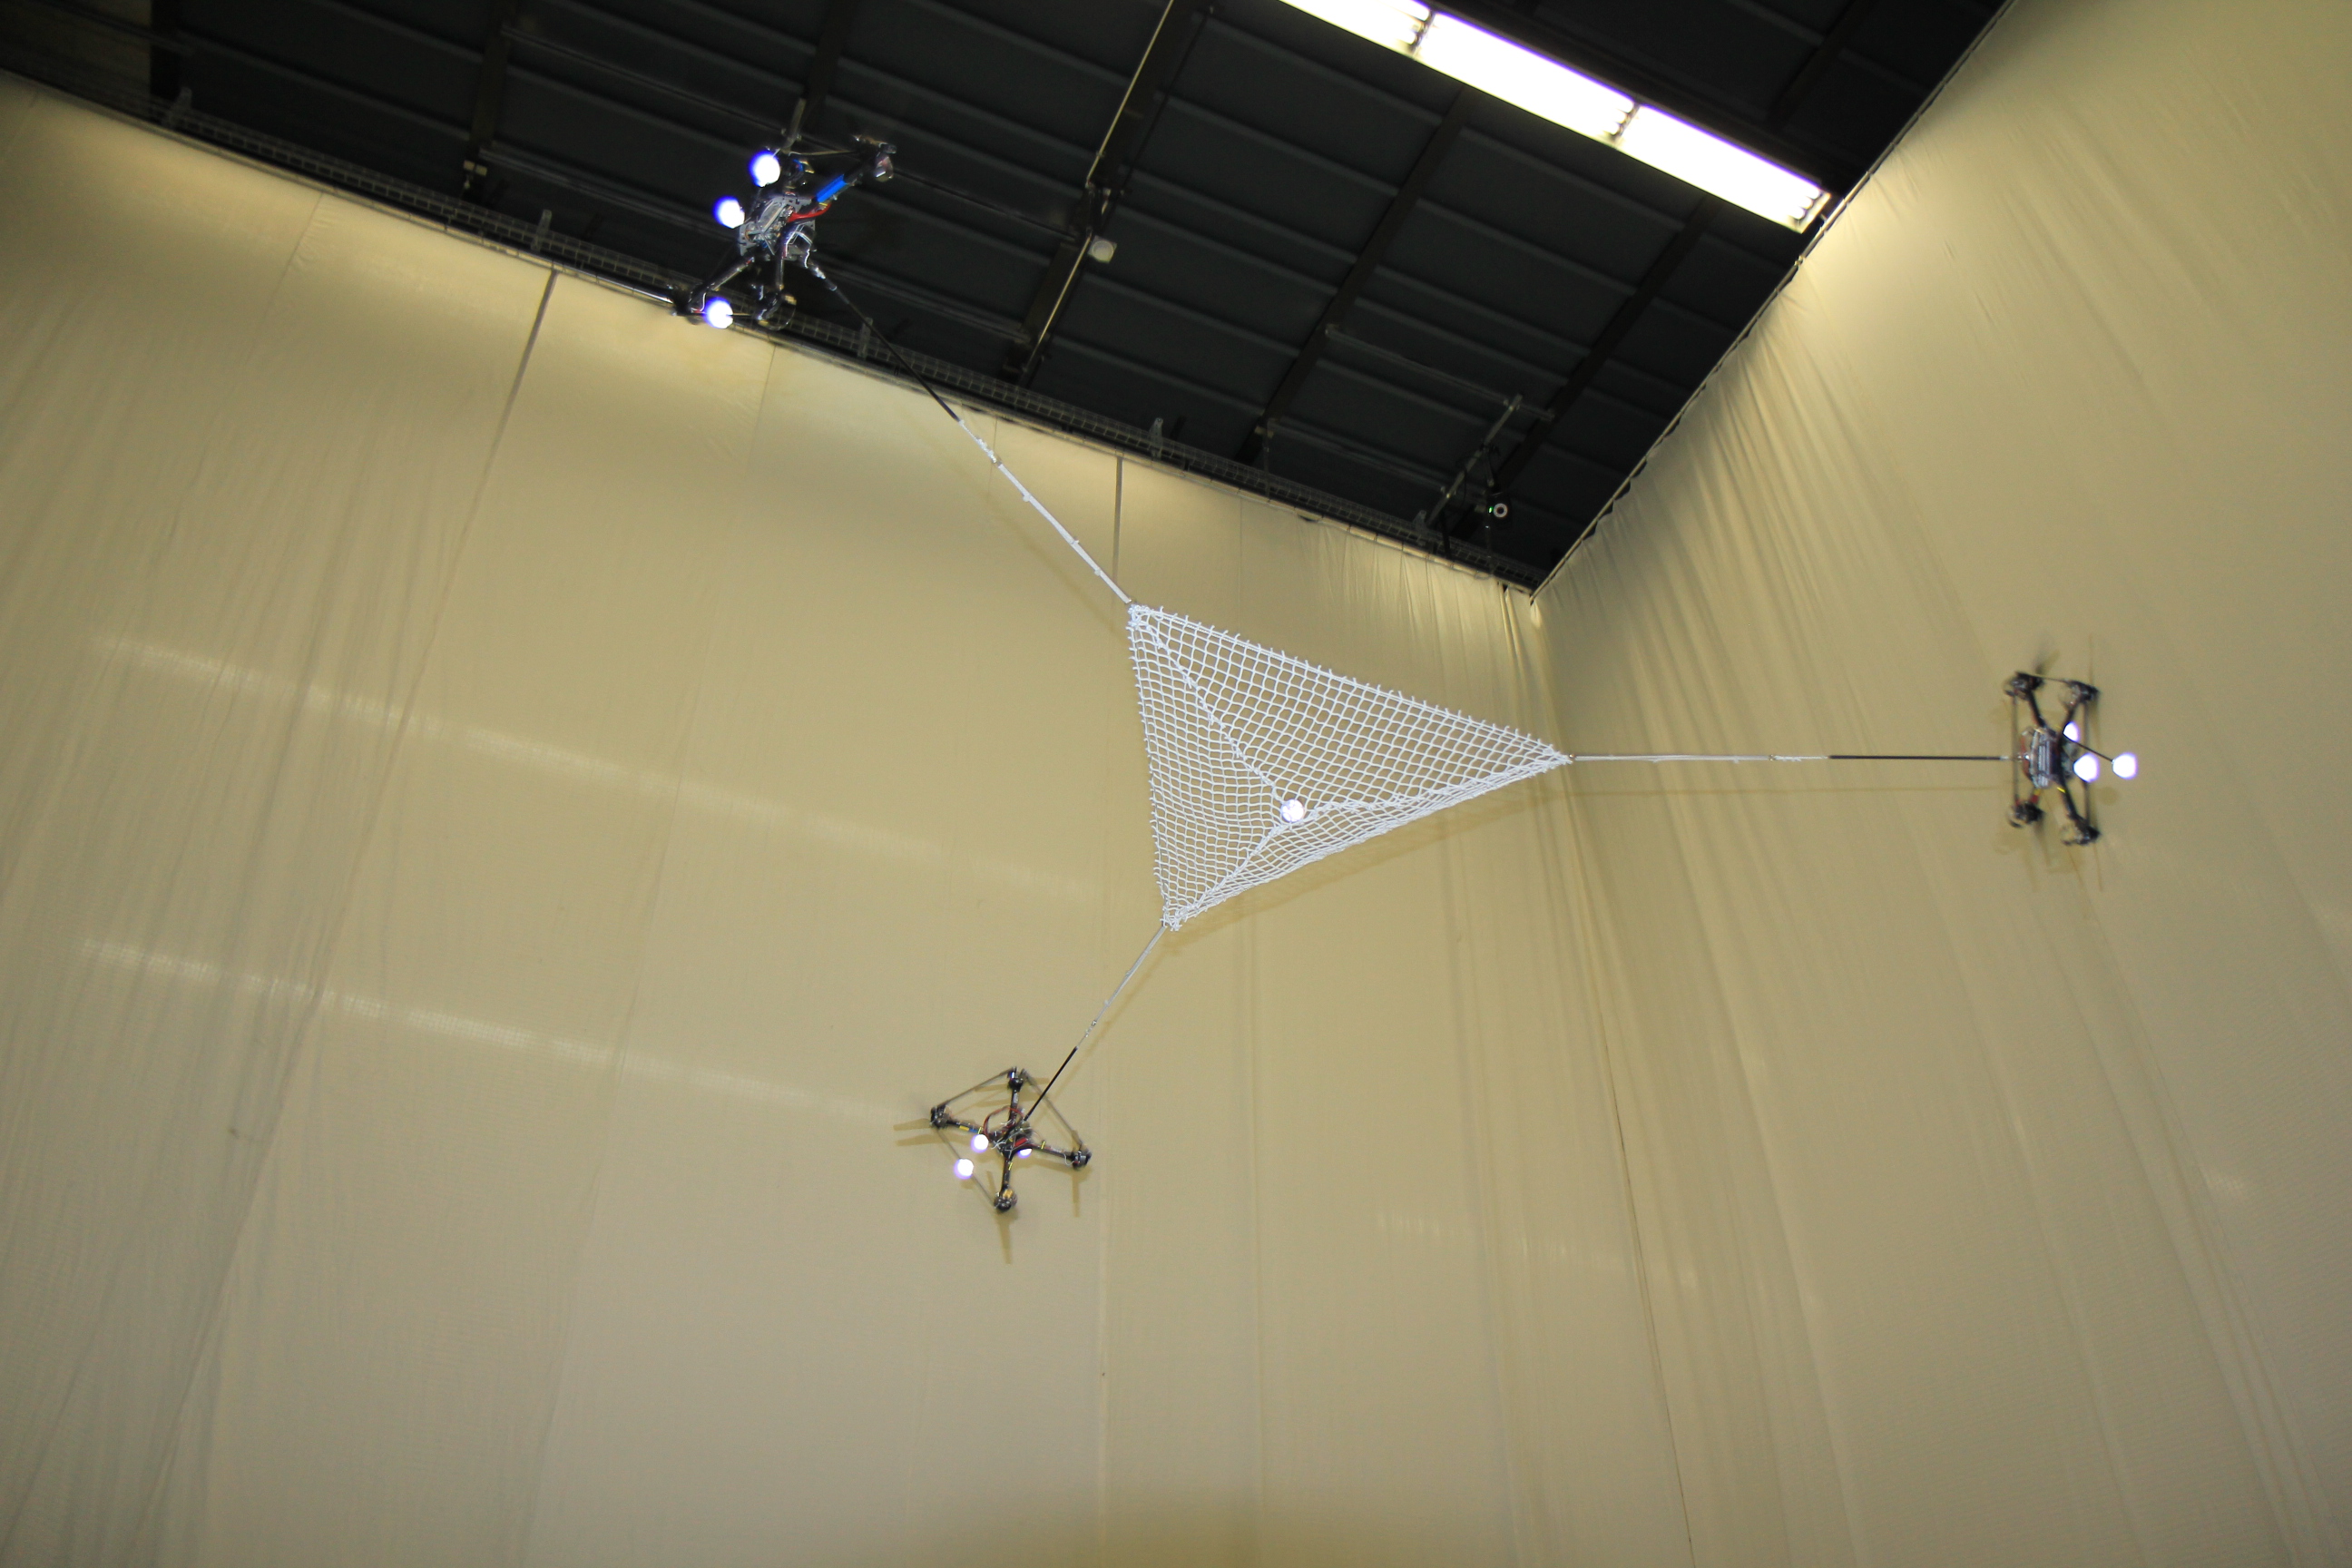
This video shows three quadrocopters cooperatively tossing and catching a ball with the aid of an elastic net.
 
To toss the ball, the quadrocopters accelerate rapidly outward to stretch the net tight between them and launch the ball up. Notice in the video that the quadrocopters are then pulled forcefully inward by the tension in the elastic net, and must rapidly stabilize in order to avoid a collision. Once recovered, the quadrotors cooperatively position the net below the ball in order to catch it.
 
Because they are coupled to each other by the net, the quadrocopters experience complex forces that push the vehicles to the limits of their dynamic capabilities. To exploit the full potential of the vehicles under these circumstances requires several novel algorithms, including:
 

    1. an optimality-based real-time trajectory generation algorithm for the catching maneuver;
     
    2. a time-varying trajectory following control strategy to manage the forces on the individual vehicles that are induced by the net; and
     
    3. learning algorithms that compensate for model inaccuracies when aiming the ball.

 
For more information on this and related work, have a look at the Flying Machine Arena’s website or tune in to Prof. Raffaello D’Andrea’s ROBOTS Podcast interview.
 
Some photos of the robots in action:


tags: , , , , ,


Markus Waibel is a Co-Founder and COO of Verity Studios AG, Co-Founder of Robohub and the ROBOTS Podcast.

            AUAI is supported by:


Subscribe to Robohub newsletter on substack


Related posts :

Robot Talk Episode 167 – Automating construction, with Jan Petrš

  23 Oct 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Jan Petrš from École Polytechnique Fédérale de Lausanne about novel robot designs for construction and architecture.

ACM SIGAI Autonomous Agents Award 2027 open for nominations

  20 Oct 2026
Nominations are solicited for the 2027 ACM SIGAI Autonomous Agents Research Award.

Powered by muscle cells, a paper-thin robot swims through watery maze

  19 Oct 2026
MIT engineers’ new aquabot offers a way to design small, efficient “biohybrid” robots.

Robot Talk Episode 166 – Evolving robot bodies and brains, with Rika Antonova

  16 Oct 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Rika Antonova from the University of Cambridge about using artificial intelligence to develop complimentary robot hardware and algorithms.

Humanoid robots can sprint and box – but the real test is doing the laundry

  12 Oct 2026
No robot system can yet reliably handle the whole laundry process. Even folding remains a challenge.

Robot Talk Episode 165 – Robots behind the research, with Kushant Patel

  09 Oct 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Kushant Patel from Brookhaven National Laboratory about robots that work in scientific facilities, such as particle accelerators.

What three days building a robot taught me

and   07 Oct 2026
The brief sounded simple: build a small autonomous robot, then make it survive increasingly difficult mazes. Simple... right? Until you actually have to build one.


↑


AUAI is supported by:


Subscribe to Robohub newsletter on substack


©2026.05 - Association for the Understanding of Artificial Intelligence