Robohub.org
 

Wall-climbing robots create a carbon fiber hammock (with video, images)

by
04 August 2016


share this:
carbon-fiber-hammock-2

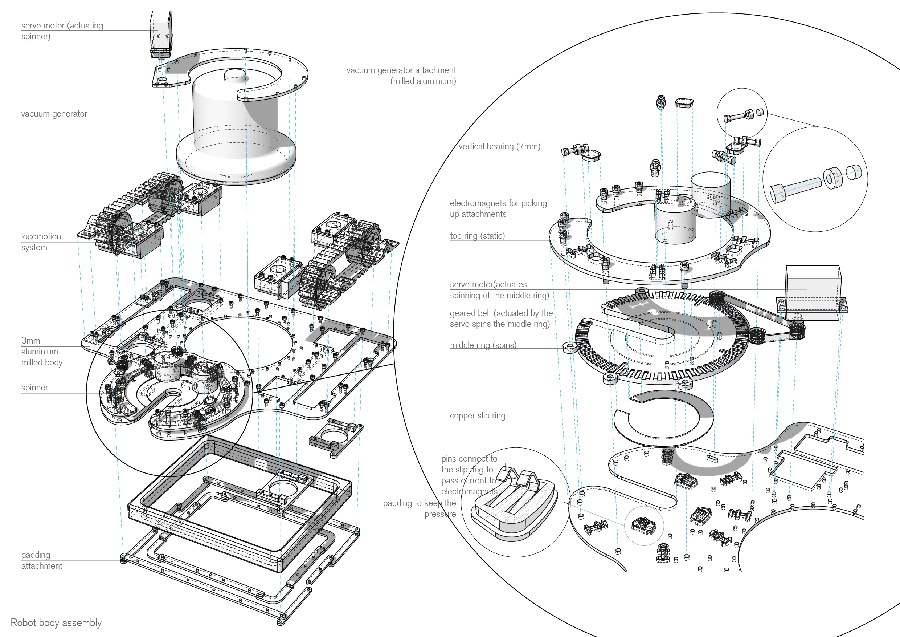
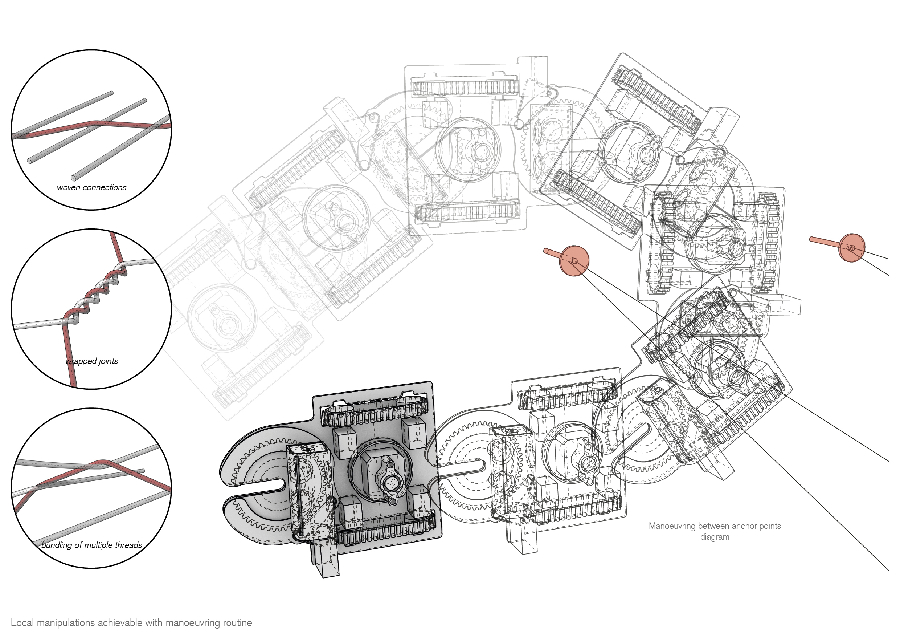
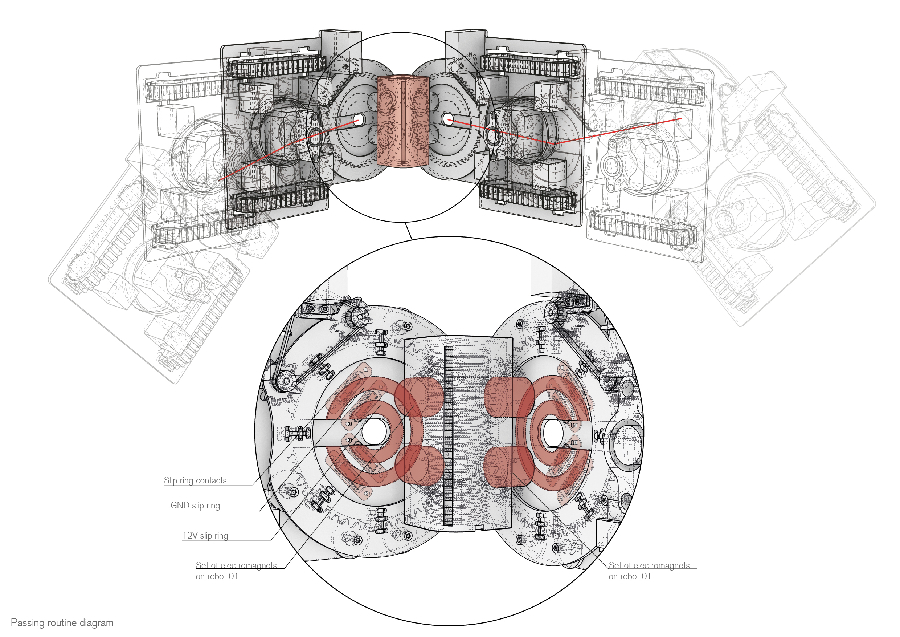
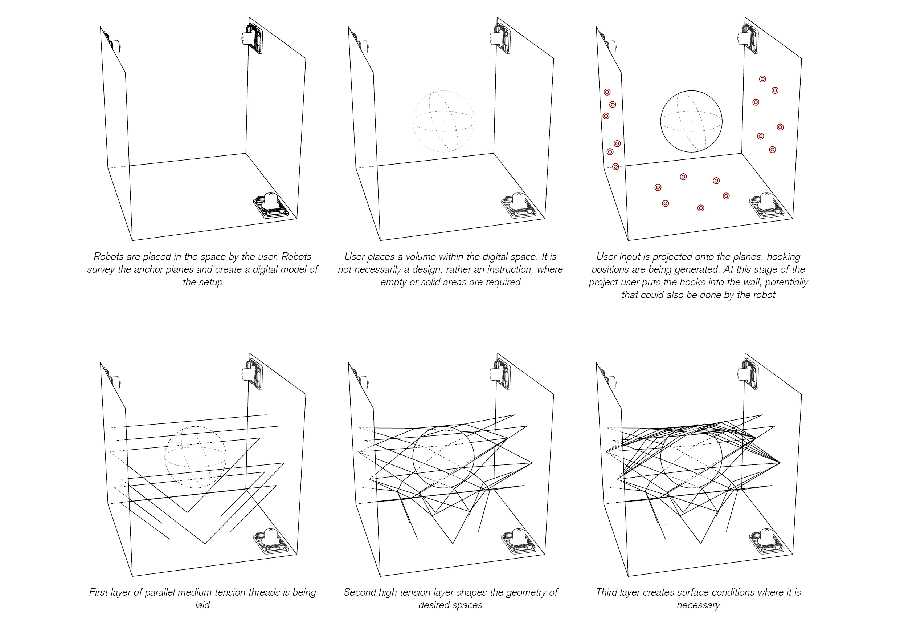
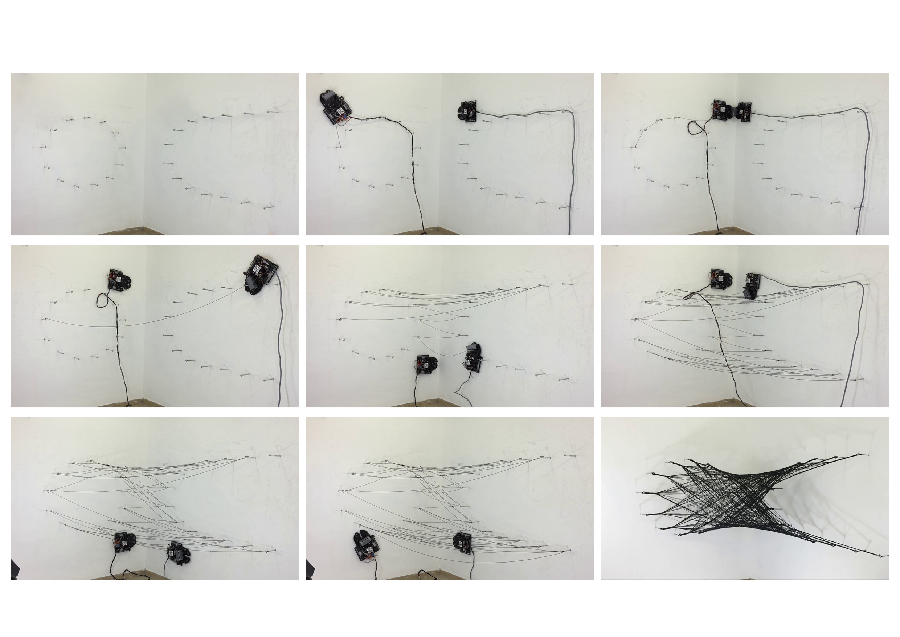
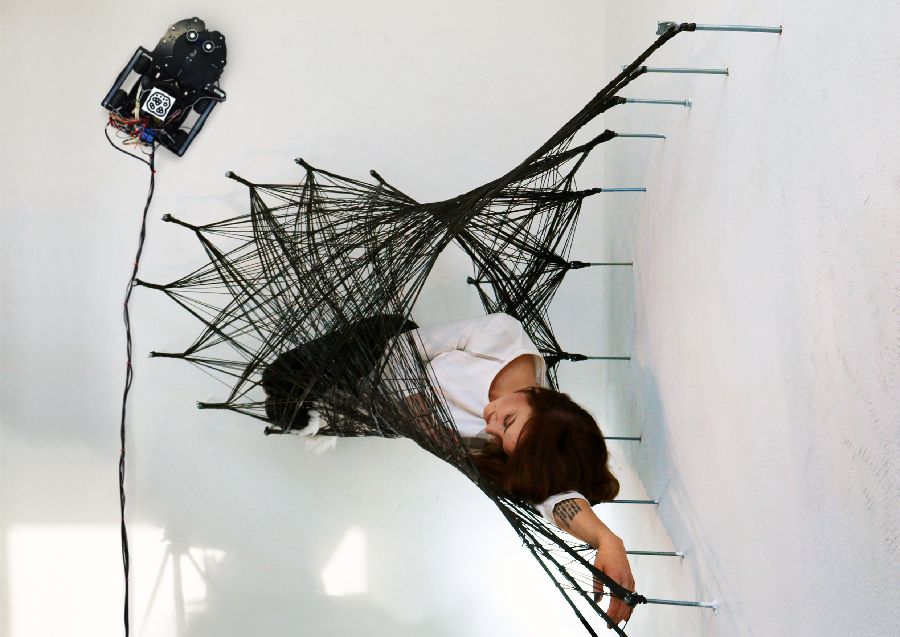
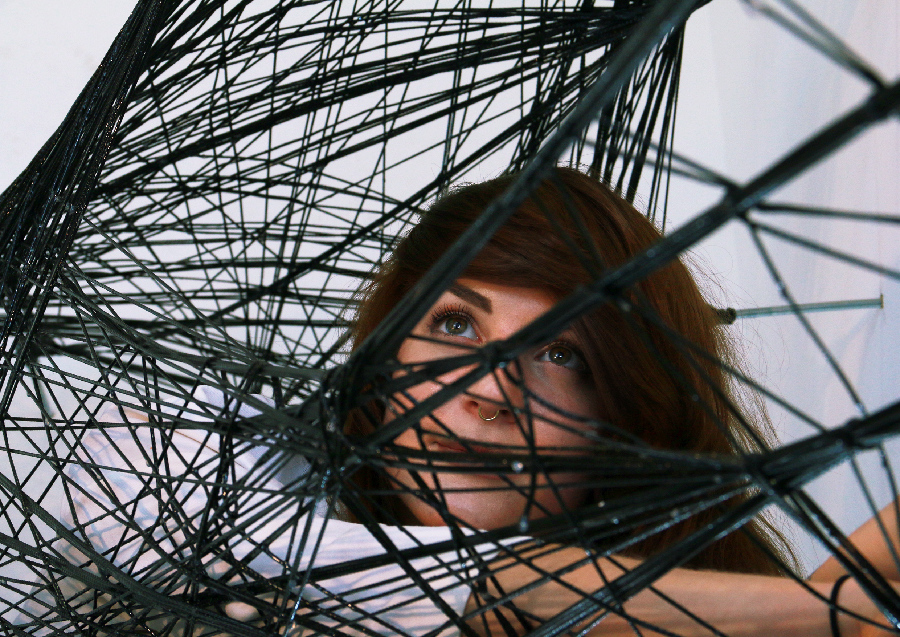
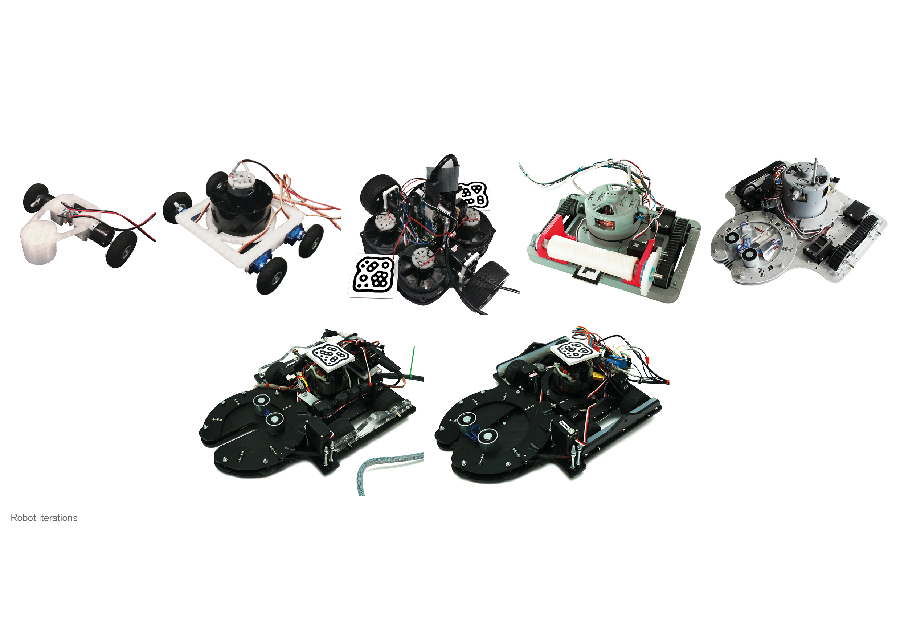
Maria Yablonina’s project, called Mobile Robotic Fabrication System for Filament Structures, demonstrates a new production process for filament structures, like carbon fiber, by crawling up the wall and spinning structures. The robots look remarkably similar to spiders spinning silk.

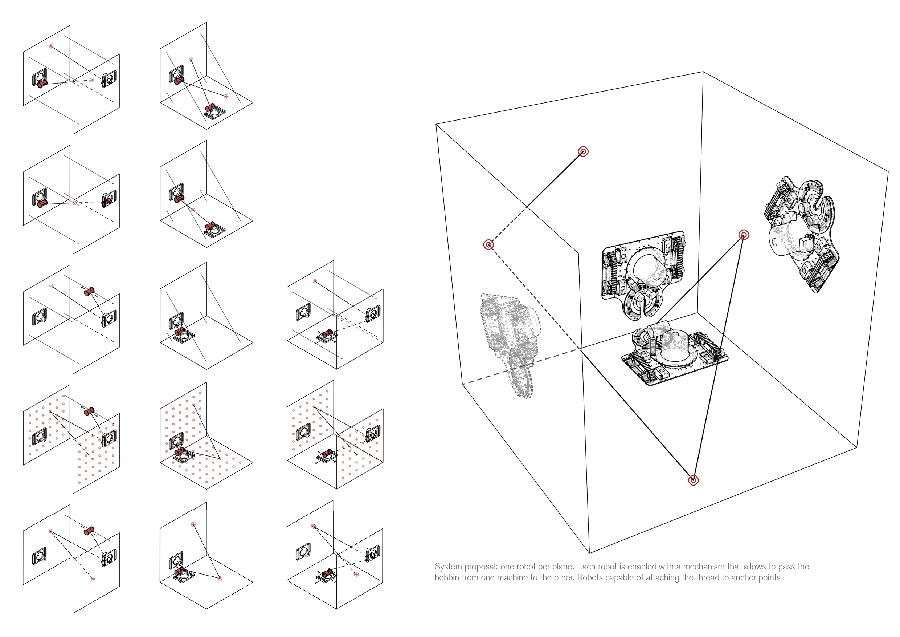
From the project website: “It proposes multiple semi-autonomous wall climbing robots to distribute fiber filament, using any horizontal or vertical surface, or even existing architecture, to support the new structures. Compared to larger scale industrial robots that are limited by position and reach, these robots are enabled with movement systems and a collection of sensors that allow them to travel and interact accurately along typical ground, walls, roofs, and ceilings.

One can imagine a fabrication process where an operator arrives at the scene with a suitcase housing all the necessary robots and materials to create a large structure. These agile mobile robotic systems move robotic fabrication processes beyond the constraints of the production hall, exposing vast urban and interior environments as potential fabrication sites.”

All images credit Maria Yablonina, University of Stuttgart

Project by: Maria Yablonina, MSc.

Thesis Advisers: E. Baharlou, M. Prado, T. Schwinn
Thesis Supervisor: Prof. Achim Menges
Second Supervisor: Prof. Jan Knippers
carbon-fiber-hammock-eyes robots-hammock4 robot-hammock3 robot-hammock5 robot-hammock-6 robot-hammock8 robot-hammock9 robot-hammock12


Robohub Editors

            AUAI is supported by:



Subscribe to Robohub newsletter on substack


Related posts :

Robot swarms trained by trial and error in simulation keep working on real robots

  17 Nov 2026
Researchers have developed a new approach to reinforcement learning that helps robot swarms, allowing behaviours learned in simulation to transfer reliably to real-world robots.

Watch the IROS 2026 plenary and keynote talks

  16 Nov 2026
Catch up on the invited presentations from the International Conference on Intelligent Robots and Systems.

Robot Talk Episode 170 – Robots in the real world, with Daniela Shchegelskaya

  13 Nov 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Daniela Shchegelskaya from the University of Twente about getting robots to operate reliably in safety-critical environments.

AI100 report released: embodied AI highlighted as grand challenge

  11 Nov 2026
Embodied AI is listed as one of the most inspiring open grand challenges.

AIhub coffee corner: Are humanoids the future of embodied AI?

  09 Nov 2026
The AIhub coffee corner captures the musings of AI experts over a short conversation.

Robot Talk Episode 169 – Robot sensing inspired by nature, with Dexter Shepherd

  06 Nov 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Dexter Shepherd from the University of Sussex about using artificial intelligence to help robots understand and adapt to their environment.

Robots in society, business and culture: October 2026

We showcase a selection of robotics stories from society, business, research and culture.

Muscle coordination can be mimicked by electric motors – it could lead to improved robots

  02 Nov 2026
Researchers built a physical model using ordinary electric motors to try and simulate how muscles may perform tasks.


↑


AUAI is supported by:



Subscribe to Robohub newsletter on substack


©2026.05 - Association for the Understanding of Artificial Intelligence