Robohub.org
 

David Robert on “Do robots need heads?”

by
15 August 2013


share this:

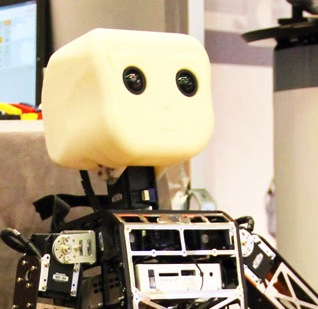
robohub.org-robots_on_tourAs a robot animator I can attest to the fact that robots don’t “need” heads to be treated as social entities. Research has shown that people will befriend a stick as long as it moves properly [1].

We have a long-standing habit of anthropomorphizing things that aren’t human by attributing to them human-level personality traits or internal motivations based on cognitive-affective architectures that just aren’t there. Animators have relied on the audience’s willingness to suspend disbelief and, in essence, co-animate things into existence: from a sack of flour to a magic broom. It’s possible to incorporate the user’s willingness to bring a robot to life by appropriately setting expectations and being acutely aware of how the context of interaction affects possible outcomes.

In human lifeforms, a head usually circumscribes a face, whereas in a robot a face can be placed anywhere. Although wonderfully complex, in high degree of freedom (DOF) robot heads, the facial muscles can be challenging to orchestrate with sufficient timing precision. If your robot design facilitates expression through the careful control of the quality of motion rendered, a head isn’t necessary in order to communicate essential non-verbal cues. As long as you consider a means for revealing the robot’s internal state, a head simply isn’t needed. A robot’s intentions can be conveyed through expressive motion and sound regardless of its form or body configuration.

[1] Harris, J., & Sharlin, E. (2011, July). Exploring the affect of abstract motion in social human-robot interaction. In RO-MAN, 2011 IEEE (pp. 441-448). IEEE.


tags: , , , , ,


David Robert

            AUAI is supported by:


Subscribe to Robohub newsletter on substack


Related posts :

Robot Talk Episode 171 – Programming robot behaviour, with Sebastian Castro

  20 Nov 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Sebastian Castro about developing open-source software for robot task planning and behaviour.

Soft exosuit makes it easier to stand up

Robotic system helps users stand up and walk more efficiently.

Robot swarms trained by trial and error in simulation keep working on real robots

  17 Nov 2026
Researchers have developed a new approach to reinforcement learning that helps robot swarms, allowing behaviours learned in simulation to transfer reliably to real-world robots.

Watch the IROS 2026 plenary and keynote talks

  16 Nov 2026
Catch up on the invited presentations from the International Conference on Intelligent Robots and Systems.

Robot Talk Episode 170 – Robots in the real world, with Daniela Shchegelskaya

  13 Nov 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Daniela Shchegelskaya from the University of Twente about getting robots to operate reliably in safety-critical environments.

AI100 report released: embodied AI highlighted as grand challenge

  11 Nov 2026
Embodied AI is listed as one of the most inspiring open grand challenges.

AIhub coffee corner: Are humanoids the future of embodied AI?

  09 Nov 2026
The AIhub coffee corner captures the musings of AI experts over a short conversation.

Robot Talk Episode 169 – Robot sensing inspired by nature, with Dexter Shepherd

  06 Nov 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Dexter Shepherd from the University of Sussex about using artificial intelligence to help robots understand and adapt to their environment.


↑


AUAI is supported by:


Subscribe to Robohub newsletter on substack


©2026.05 - Association for the Understanding of Artificial Intelligence