
Robohub.org
Researchers are teaching robots to walk on Mars from the sand of New Mexico
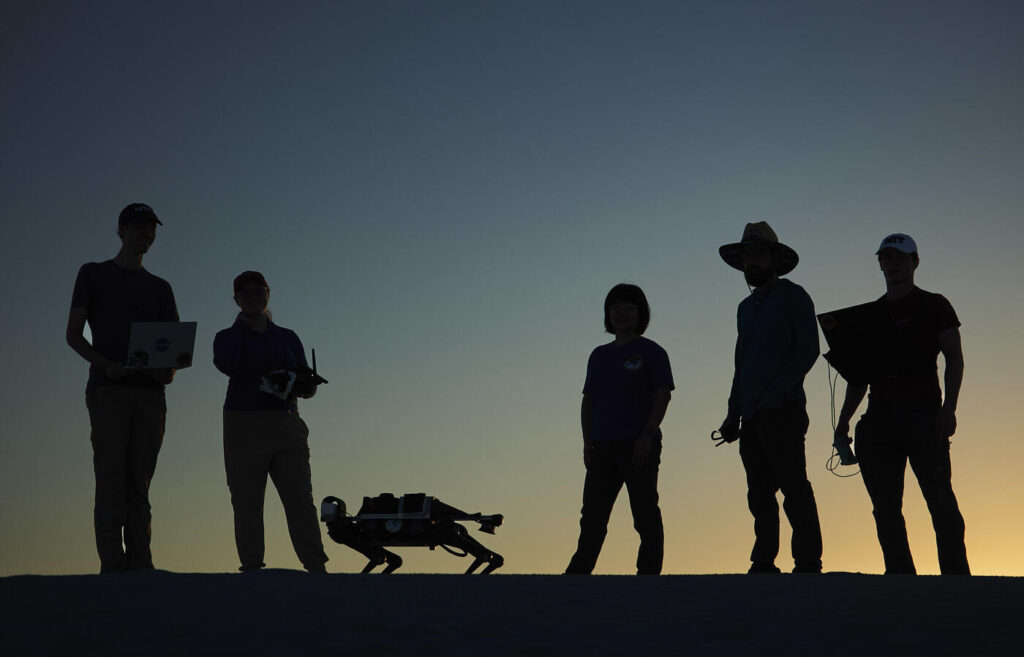 Scientists and robot at White Sands National Park.
By Sean Nealon
Researchers are closer to equipping a dog-like robot to conduct science on the surface of Mars after five days of experiments this month at White Sands National Park in New Mexico.
The national park is serving as a Mars analog environment and the scientists are conducting field test scenarios to inform future Mars operations with astronauts, dog-like robots known as quadruped robots, rovers and scientists at Mission Control on Earth. The work builds on similar experiments by the team with the same robot on the slopes of Mount Hood in Oregon, which simulated the landscape on the Moon.
“Our group is very committed to putting quadrupeds on the Moon and on Mars,” said Cristina Wilson, a robotics researcher in the College of Engineering at Oregon State University. “It’s the next frontier and takes advantage of the unique capabilities of legged robots.”
The NASA-funded project supports the agency’s Moon to Mars program, which is developing the tools for long-term lunar exploration and future crewed missions to Mars. It builds on research that has enabled NASA to send rovers and a helicopter to Mars.
The LASSIE Project: Legged Autonomous Surface Science in Analog Environments includes engineers, cognitive scientists, geoscientists and planetary scientists from Oregon State, the University of Southern California, Texas A&M University, the Georgia Institute of Technology, the University of Pennsylvania, Temple University and NASA Johnson Space Center.
The field work this month at White Sands was the second time the research team visited the national park. They made the initial trip in 2023 and also made trips in 2023 and 2024 to Mount Hood. During these field sessions, the scientists gather data from the feet of the quadruped robots, which can measure mechanical responses to foot-surface interactions.
“In the same way that the human foot standing on ground can sense the stability of the surface as things shift, legged robots are capable of potentially feeling the exact same thing,” Wilson said. “So each step the robot takes provides us information that will help its future performance in places like the Moon or Mars.”
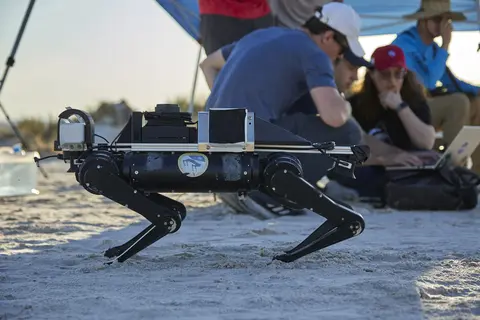 Quadruped robot.
The conditions at White Sands this month were challenging. Triple-digit high temperatures meant the team started field work at sunrise and wrapped by late morning because of the rising heat index and its impact on the researchers and the power supply to the robots.
But the team made important progress. Improvements to the algorithms they have refined in recent years led for the first time to the robot acting autonomously and making its own decisions.
This is important, Wilson noted, because in a scenario where the quadruped would be on the surface of Mars with an astronaut, it would allow both the robot and the astronaut to act independently, increasing the amount of scientific work that could be accomplished.
They also tested advances they have made in developing different ways for the robot to move depending on surface conditions, which could lead to increased energy efficiency, Wilson said.
“There is certainly a lot more research to do, but these are important steps in realizing the goal of sending quadrupeds to the Moon and Mars,” Wilson said.
Other leaders of the project include Feifei Qian, USC; Ryan Ewing and Kenton Fisher, NASA Johnson Space Center; Marion Nachon, Texas A&M; Frances Rivera-Hernández, Georgia Tech; Douglas Jerolmack and Daniel Koditschek, University of Pennsylvania; and Thomas Shipley, Temple University.
The research is funded by the NASA Planetary Science and Technology through Analog Research (PSTAR) program, and Mars Exploration Program.
AUAI is supported by:










