
Robohub.org
These tiny drones are powered by sound
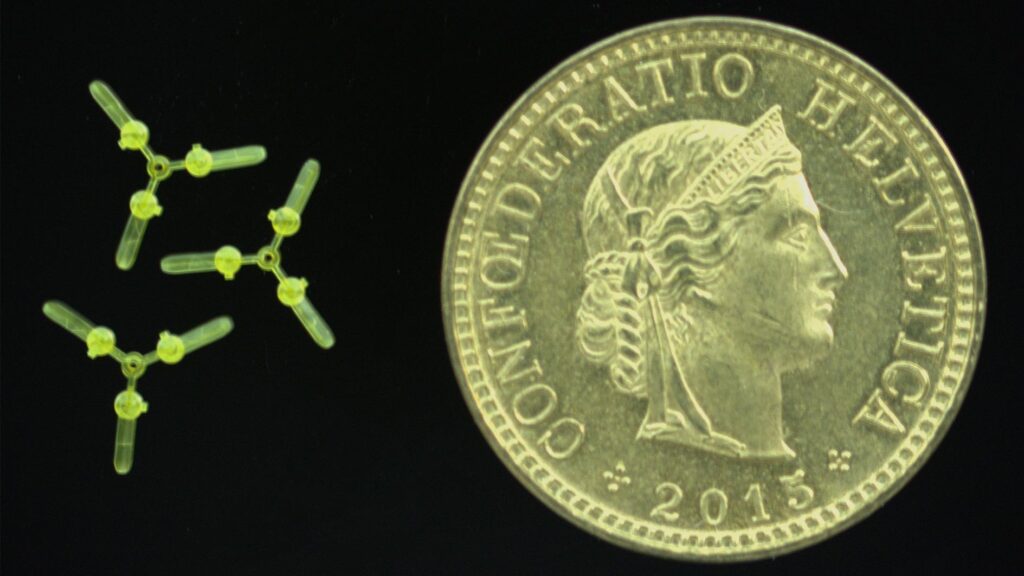 The MICROBS Lab’s microfliers. 2026 EPFL/MICROBS – CC-BY-SA 4.0.
By Celia Luterbacher
When you blow air across the neck of a bottle, you’re not just producing a pleasant tone: you’re also demonstrating a phenomenon called Helmholtz resonance. This occurs when airflow passing across an opening causes air trapped inside a cavity (like a glass bottle) to oscillate back and forth. At certain frequencies, these oscillations become much stronger, producing the familiar humming sound.
Now, researchers in the MicroBioRobotic Systems (MICROBS) Lab in EPFL’s School of Engineering have harnessed the physics behind this phenomenon to build hollow structures that act as miniature, sound-powered machines. The innovation has been published in Science Advances.
“Instead of pushing devices around with sound waves, we have created acoustic resonators that are tuned to harness sound at specific frequencies to generate directional thrust and controlled motion,” says lab head Selman Sakar. “Our work shows the feasibility of transforming a simple, cleverly designed mechanical piece into robotic matter.”
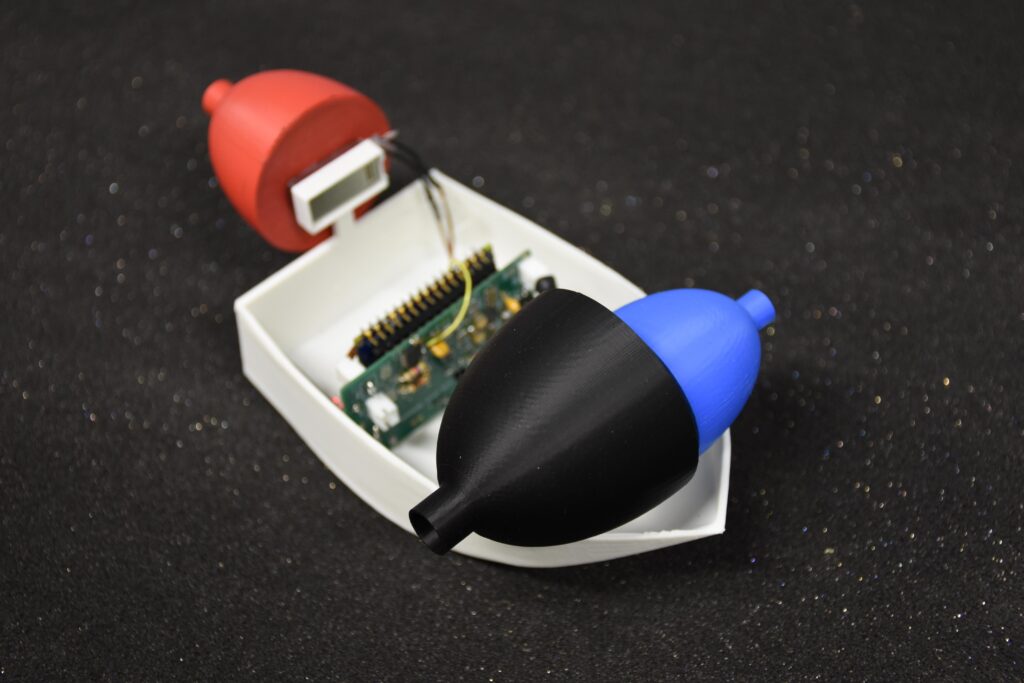 The MICROBS Lab’s sound-powered boat. 2026 EPFL/MICROBS – CC-BY-SA 4.0.
Miniature boats and microfliers
While previous approaches have used sound waves to levitate passive objects mid-air, the EPFL team designed devices that convert sound into their own propulsive force. Their innovation lies in the fabrication of hollow round or bell-shaped structures called cavities.
When sound waves excite the air inside these cavities, the oscillating air is forced out as a concentrated jet, while the incoming airflow is more diffuse. This imbalance generates thrust that can propel small vehicles. These sound-powered cavities can be made from a variety of materials, including common 3D-printing plastics, rubber-like polymers, and glass.
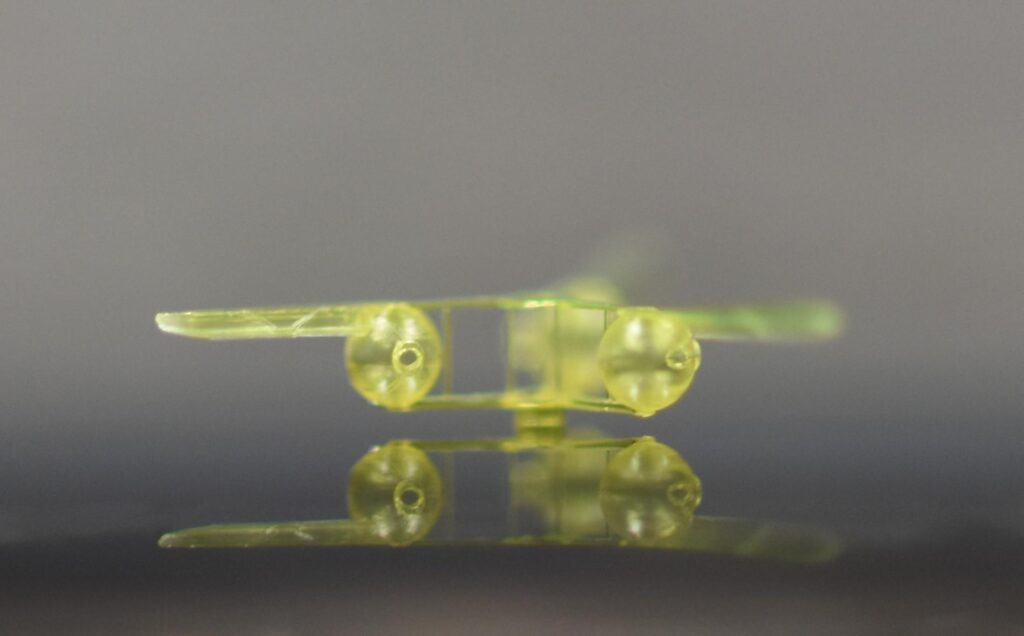 The MICROBS Lab’s microflier. 2026 EPFL/MICROBS – CC-BY-SA 4.0.
At the centimeter scale, the team built miniature boats equipped with up to three cavities, each tuned to a different audible frequency and positioned to push the boat in a particular direction. By changing the frequency of sound waves from a speaker, the researchers could selectively activate different cavities to move the boats, steer them around obstacles, and even program them for autonomous navigation.
Using a 3D nanoprinting technique, the team built ‘microfliers’: ultralight flying vehicles with three microscopic cavities integrated directly into their polymer structures. In contrast to the boats, the microfliers were powered at ultrasonic frequencies inaudible to the human ear. One design weighing just 150 micrograms used its cavities to generate direct upward thrust like a rocket. Another microflier combined the cavities with tiny blades, which spun at speeds of up to 13,000 revolutions per minute, to generate stable, helicopter-like aerodynamic lift.
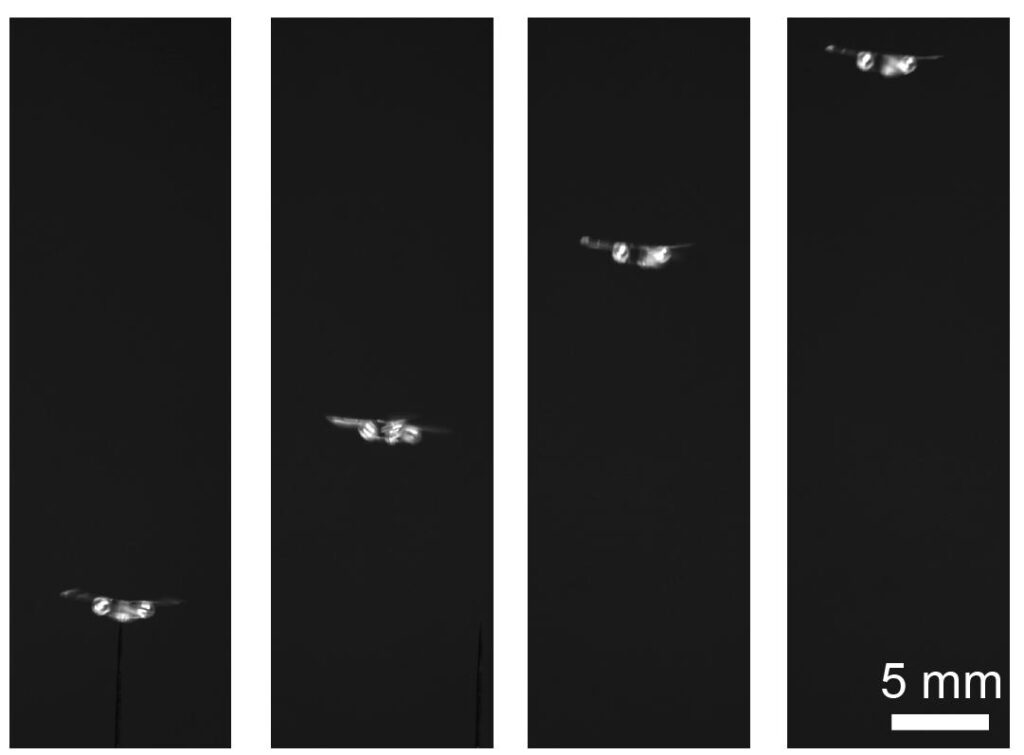 A microflier in flight. 2026 EPFL/MICROBS – CC-BY-SA 4.0.
Toward sound-responsive robotics
Because the devices rely on hollow cavities rather than motors, gears, or magnetic components, they can be made extremely small and lightweight using a variety of 3D-printing methods.
“Our concept is compatible with even further miniaturization, enabling advanced designs that push the boundaries of robotics and aeronautics,” says first author and MICROBS Lab PhD student Junsun Hwang.
Sakar adds that in the future, several sound-responsive structures could be built into a single flexible device, with each one reacting to a different sound frequency. “This would allow specific parts of the device to move, bend or vibrate, potentially leading to aerodynamic robotic devices that can change shape in response to sound,” he says.
Reference
Acoustic resonators as wireless actuators in air for small-scale robots, Junsun Hwang et al., Science Advances (2026).
AUAI is supported by:









