Robohub.org
 

Grasping with robots – which object is in reach?


by
17 August 2014


share this:

This post is part of our ongoing efforts to make the latest papers in robotics accessible to a general audience.

Imagine a robot reaching for a mug on the table, only to realize that it is too far, or that it would need to bend its arm joint backwards to get there. Understanding which objects are within reach and how to grasp them is an essential requirement if robots are to operate in our everyday environments. To solve this problem, a recent Autonomous Robots paper by Vahrenkamp et al. proposes a new approach to build a comprehensive representation of the capabilities of a robot related to reaching and grasping.

The “manipulability” representation shown below allows the robot to know where it can reach in 6D with its right arm. That means it knows which x,y,z positions it can reach, as well as the orientation of the robot hand that is best for manipulation. The representation takes into account constraints due to joints in the arm. The manipulability is encoded by color (blue: low, red: high).
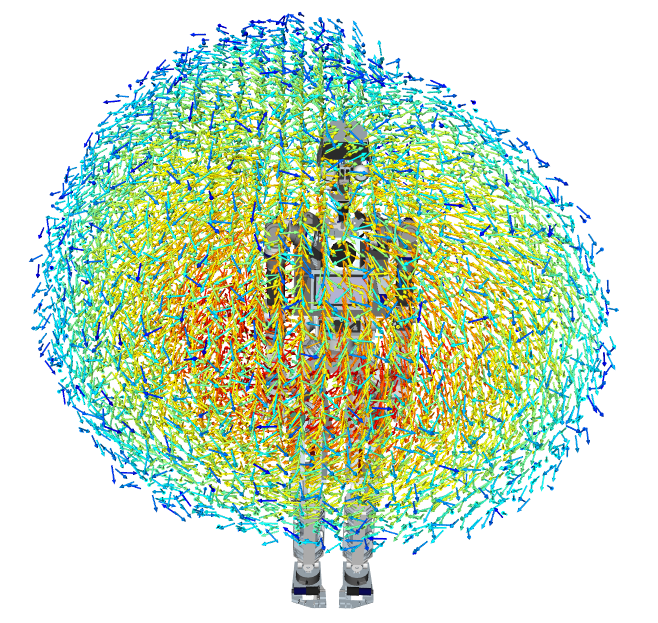
armar4_rightarm6

A cut through one of these vector clouds looks like this.
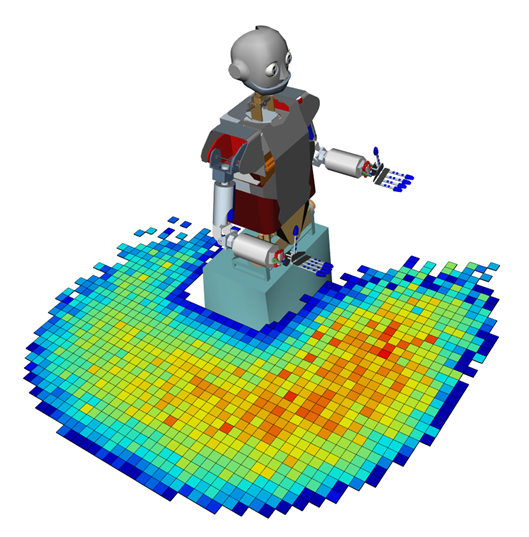
manip_armar2

In addition to single handed grasping, the authors discuss how the approach can be extended to grasping with two arms. Experiments were run in simulation on the humanoid robots ARMAR-III and ARMAR-IV.

And in case you want to try this at home, there is an open source version of this work here.

For more information, you can read the paper Representing the robot’s workspace through constrained manipulability analysis (Nikolaus Vahrenkamp and Tamim Asfour, Autonomous Robots – Springer US, July 2014) or ask questions below!


tags:


Autonomous Robots Blog Latest publications in the journal Autonomous Robots (Springer).

            AUAI is supported by:


Subscribe to Robohub newsletter on substack


Related posts :

Reimagining robotics for sustainability

  18 Sep 2026
"Our ambition is not to simply make robots more sustainable; they must actively contribute to solving sustainability challenges."

Watch the ICRA keynote and plenary talks

  16 Sep 2026
If you missed the conference you can catch up on IEEE TV.

Building and programming autonomous robots at the York Micromaze Hackathon

and   11 Sep 2026
From 25–27 August, UK RAS STEPS members came together for a three-day Micromaze Robot Hackathon.

Robotics roadmaps from around the world spotlight of the month: United States of America

US robotics researchers and industry are looking for a cohesive national robotics strategy.

Could robots help tackle loneliness? BBC’s Ann Droid raises questions about the future of care

  07 Sep 2026
While the series exaggerates what robots can currently do, some of the technology it depicts is already being tested.

Exploring the Moon will require rovers that can think for themselves – an upcoming NASA mission will test whether they can

  04 Sep 2026
NASA is planning to send three small rovers to the Moon to autonomously compute how to best explore a patch of ground.

Surviving the paper deluge: Notes from an ICRA panel on publishing, LLMs, and the future of peer review

Experts discuss peer-review challenges and possibilities for reshaping the process.


AUAI is supported by:


Subscribe to Robohub newsletter on substack


©2026.05 - Association for the Understanding of Artificial Intelligence