Robohub.org
 

The Year of CoCoRo Video #38/52: BEECLUST

by
22 September 2015


share this:

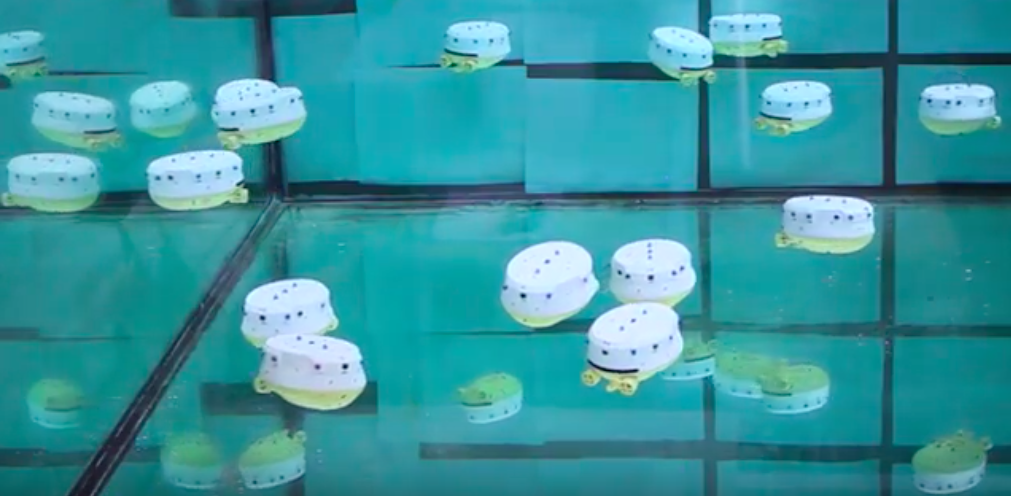
cocoro38b The EU-funded Collective Cognitive Robotics (CoCoRo) project has built a swarm of 41 autonomous underwater vehicles (AVs) that show collective cognition. Throughout 2015 – The Year of CooRo – we’ll be uploading a new weekly video detailing the latest stage in its development. This week we show an early laboratory experiment using the BEECLUST algorithm on a swarm of Lily robots.

The BEECLUST is a simple swarm algorithm derived from the walking and resting behavior of young honeybees, who can compare several temperature spots in their environment and collectively choose the optimal (warmest) spot. In our video, the algorithm was translated to underwater robots.

The robots move randomly in their habitat. When they meet another robot, they measure how deep the water below is. The more shallow the water, the longer they stay in place.

By running this algorithm, the swarm is able to identify shallow places and collectively choose the shallowest. The same algorithm can be used to find the deepest point, the darkest or the brightest, simply by correlating the resting time of the robots with other local environmental properties.

The BEECLUST is one of the simplest swarm algorithms possible, possibly even THE simplest. However, an algorithm like this does not suit every application: in our experiments we found that, in contrast to crawling honeybees in the hive or driving wheeled robots on the ground, it is very tricky for an AUV to stay in place in water because of drift and turbulence. Even in an aquarium this is an issue, with a number of robots moving around, so we concluded that, for a more turbulent underwater habitat, we needed a better algorithm than the classical BEECLUST.


tags: , , , , ,


Thomas Schmickl is an Associate Professor at Karl-Franzens University, Graz, Austria, and a lecturer at the University for Applied Sciences in St. Pölten, Austria.

            AUAI is supported by:


Subscribe to Robohub newsletter on substack


Related posts :

Humanoid robots can sprint and box – but the real test is doing the laundry

  12 Oct 2026
No robot system can yet reliably handle the whole laundry process. Even folding remains a challenge.

Robot Talk Episode 165 – Robots behind the research, with Kushant Patel

  09 Oct 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Kushant Patel from Brookhaven National Laboratory about robots that work in scientific facilities, such as particle accelerators.

What three days building a robot taught me

and   07 Oct 2026
The brief sounded simple: build a small autonomous robot, then make it survive increasingly difficult mazes. Simple... right? Until you actually have to build one.

Research could guide the future design of social robots

  05 Oct 2026
Giving robot companions animal-like or anime-style faces and voices could maximise their emotional appeal to users, according to new research which could help guide the growing field of social robotics.

Robot Talk Episode 164 – Accelerating robot learning, with Michelle Lu

  02 Oct 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Michelle Lu from Vsim Technology about using simulation and artificial intelligence to teach robots new skills.

Robotics and automation? Informal reflections on familiar terms

IEEE experts reflect on what is meant by the term "robotics and automation".

Small, medium or large, a robotic fish maintains its swimming ability

  28 Sep 2026
Researchers at EPFL and New York University have developed a robotic fish that can be made in various sizes for studying shallow creeks to open water.

Robot Talk Episode 163 – Robots helping people, with Aaron Edsinger

  25 Sep 2026
In the first episode of Robot Talk season 7, Claire chatted to Aaron Edsinger from Hello Robot about their Stretch robots that can help people with mobility issues live more independently.


↑


AUAI is supported by:


Subscribe to Robohub newsletter on substack


©2026.05 - Association for the Understanding of Artificial Intelligence