
Robohub.org
Autonomous underwater system for monitoring health of Venice Lagoon demos at #EXPO2015
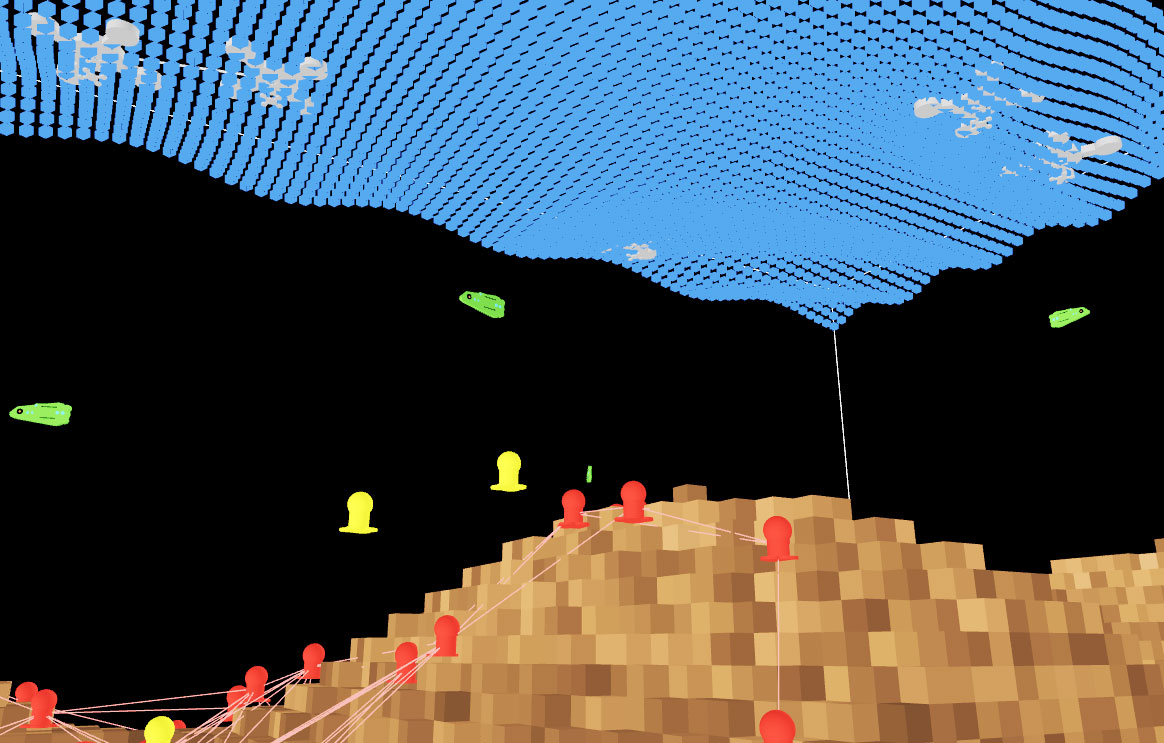 Monitoring the ocean for pollution, ecology and climate change effects is a costly and elaborate task, especially in a complex area like Venice, with its lagoon, its many channels, cable and pipe infrastructure, industrial areas, harbor, marshland, and mussel farms. An interdisciplinary team of European scientists is breaking new ground in underwater environmental monitoring with the EU-funded subCULTron project. With a budget of 4M Euros, they are developing the world’s largest intelligent underwater monitoring system that coordinates, communicates and collects data autonomously. The first presentation of subCULTron prototypes takes place at EXPO 2015 in Venice on October 15 and 16.
subCULTron is coordinated by the Artificial Life Lab of the University of Graz, working together with scientists from Italy, Belgium, France, Germany and Croatia. The group is developing a swarm of 120 autonomous underwater robots that will collect environmental data to help provide insight on how the Venice waters are influenced by the complex interplay of industry, tourism, transport, and local inhabitants. One of the long term goals of the project is to find ways to prevent future damage in the region.
A smart monitoring-system based on bio-inspired autonomous robots
Scientists have chosen an autonomous swarm approach for this challenging task because such systems are known to be very robust, flexible and scalable, especially in unpredictable, changing environments. Bio-inspired algorithms derived from derived from social insects, fish or slime molds are used for the swarm communication, as these systems can work without any central unit of control, and the loss of individual robots doesn’t lead to the failure of the whole system.
Another advantage of developing a self-organizing robot society is that the single robots are inexpensive and small compared to most conventional underwater robots, which makes it possible to build a larger fleet (in this case 120 robots) to maximize the sampling area and to collect large amounts of very diverse data in parallel.
How does the subCULTron swarm work?
The subCULTron swarm will consist of three different robot types that are designed and developed especially for the project and which represent cutting edge technology and software:
- artificialMussels (aMussels) are novel autonomous robots that sit on the ground after being deployed in the water to collect various data over a long period of time, establishing a dedicated sensory network. When necessary, they will also be able to move as a group, exploiting given energy sources, e.g., turbulences or water currents.
- artificialFish (aFish) are fast and agile underwater robots that are used to monitor the ground and to search for given targets. They also bridge communication from aMussels to artificialPads (aPads).
- aPads are robots that float on the water surface, inspired by lily pads on a pond. They complete the communication chain from aMussels on the seabed via aFish to aPads and finally to the scientists in the lab.
The goal is to have these three different robot types running efficiently by exploiting advanced energy harvesting techniques developed by the project team.
What novel knowledge is expected from the subCULTron swarm?
Thanks to the large number of swarm-robots, the autonomous communication system and the novel robot types, an enormous amount of environmental data about the Venetian underwater world will be collected in parallel. The hope is that this data will yield new insights into the effects of human intervention on the natural water habitat in and around Venice, helping to preserve this world heritage site from the effects of climate change.
Biologists and ecologists should also benefit from insight gained into ecological systems, and it is hoped that the tech industry will be able to build on subCULTron to innovate technology for underwater applications.
subCULTron goes to EXPO 2015
From October 15-16, subCULTron 2015 scientists will demonstrate their first robot prototypes live in small pool experiments at the Venice EXPO 2015.
- WHEN: 15th-16th of Oct. 2015
- WHERE: AQUAE VENICE 2015 Pavillion
- ADRESS: Via Galileo Ferraris, 5 , Venezia Marghera
- LINK: (http://www.aquae2015.org/where/?lang=en)
tags: environment & agriculture, EU, exploration & mining, Italy, mapping & surveillance, research, underwater
AUAI is supported by:









