Robohub.org
 

Tree cavity inspection using drones

by and
13 October 2016


share this:
aerial-image-drone

The importance of conserving biodiversity in forest ecosystems is widely recognized. Tree cavities are home to many animal species, such as birds, mammals and beetles, for shelter, nesting or larval development. However trees with low economic interest, often those with cavities or prone to cavity formation, are routinely removed. Consequently, these cavity-dependent species are now endangered. We need better conservation methods to prevent endangering even more cavity-dependent species.

Effective conservation requires better understanding of tree cavities. However, large-scale studies are rare, and detailed data is costly to collect.

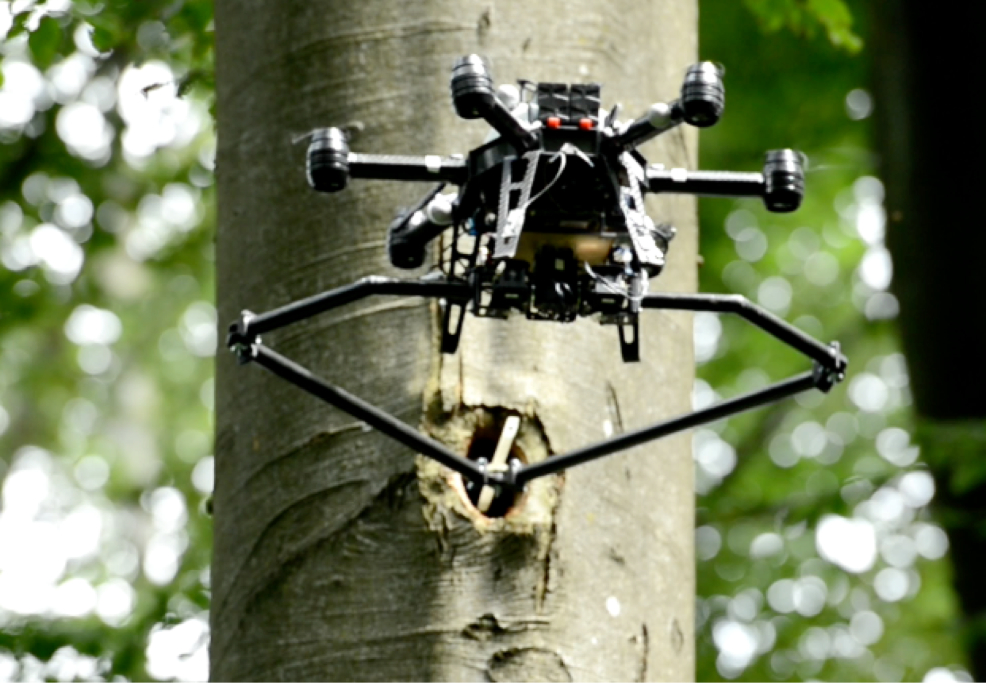
In this work, we focus on woodpeckers’ cavities which are the most common type of cavities. These cavities have an opening of 3-12 cm and a deep hollow inside the tree. We present a system based on Micro Aerial Vehicle (MAV) equipped with a manipulator to perform inspection and 3D reconstruction of tree cavities. The MAV is equipped with a visual-inertial sensor, a depth camera, and a parallel manipulator with an actuated micro-stereo camera at the end-effector, as shown in Figure 1.
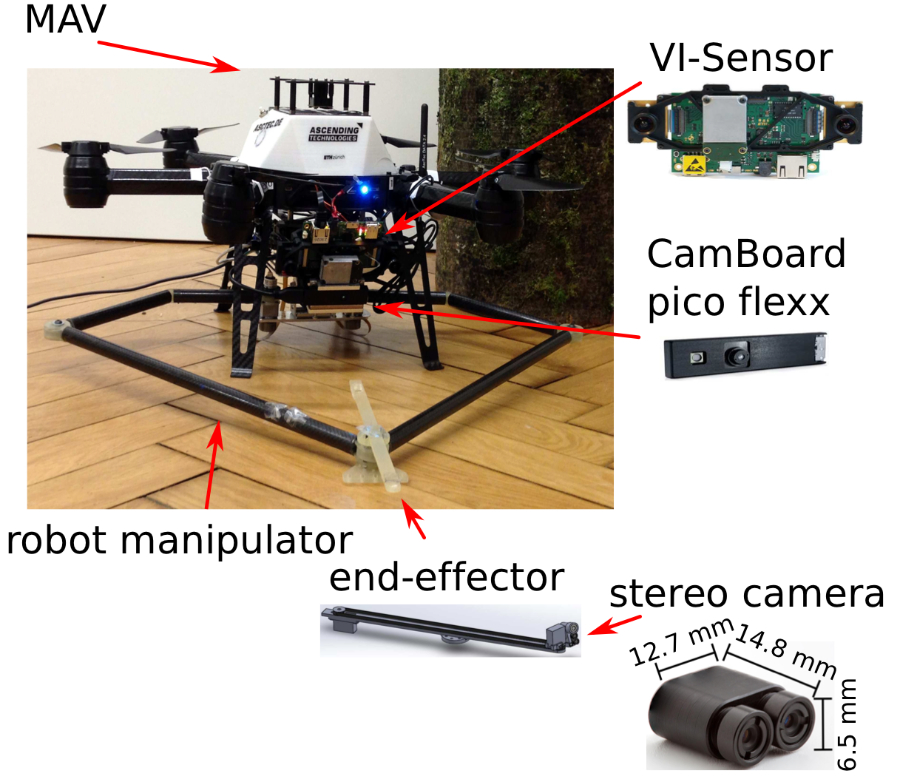
Figure 1: System hardware

Figure 1: System hardware

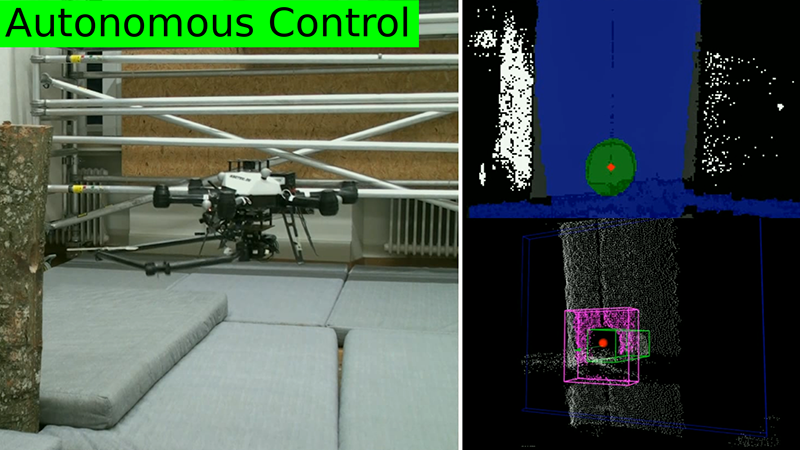
With limited intervention from the user, the system can detect and track a tree cavity. Upon confirmation by the user through a Graphical User Interface (GUI), the inspection process starts.

The proposed approach has been tested in a lab environment as well as outdoors in real tree cavities.
autonomous-control-drone

More details for this approach can be found in our paper: K. Steich, M. Kamel, P. Beardsley,  M. K. Obrist, R. Siegwart  and T. Lachat, “Tree Cavity Inspection Using Aerial Robots.” (The 2016 IEEE/RSJ International Conference on Intelligent Robots and Systems)

Researchers:

Kelly Steich, Mina Kamel, Paul Beardsley, Martin Obrist, Roland Siegwart and Thibault Lachat.


tags:


Mina Kamel is currently a PhD candidate at the Autonomous Systems Lab at ETH Zurich.

Kelly Steich worked for Disney Research and the Autonomous Systems Lab at ETH Zurich

            AUAI is supported by:


Subscribe to Robohub newsletter on substack


Related posts :

Robot Talk Episode 163 – Robots helping people, with Aaron Edsinger

  25 Sep 2026
In the first episode of Robot Talk season 7, Claire chatted to Aaron Edsinger from Hello Robot about their Stretch robots that can help people with mobility issues live more independently.

An open source approach to physical AI from Intrinsic

  25 Sep 2026
Find out more about the capabilities of Intrinsic Core.

What’s coming up at #IROS2026?

  24 Sep 2026
Find out what the International Conference on Intelligent Robots and Systems has in store.

Robotics roadmaps from around the world spotlight of the month: China

China is targeting the next industrial revolution by doubling down on embodied AI and humanoid robotics, building directly on its vast manufacturing infrastructure.

Mars rovers give scientists a ground-level view of the red planet – peek inside their NASA control room

  21 Sep 2026
NASA created Curiosity to search for evidence of ancient habitable environments.

Reimagining robotics for sustainability

  18 Sep 2026
"Our ambition is not to simply make robots more sustainable; they must actively contribute to solving sustainability challenges."

Watch the ICRA keynote and plenary talks

  16 Sep 2026
If you missed the conference you can catch up on IEEE TV.


↑


AUAI is supported by:


Subscribe to Robohub newsletter on substack


©2026.05 - Association for the Understanding of Artificial Intelligence