
Robohub.org
A new bioinspired earthworm robot for future underground explorations
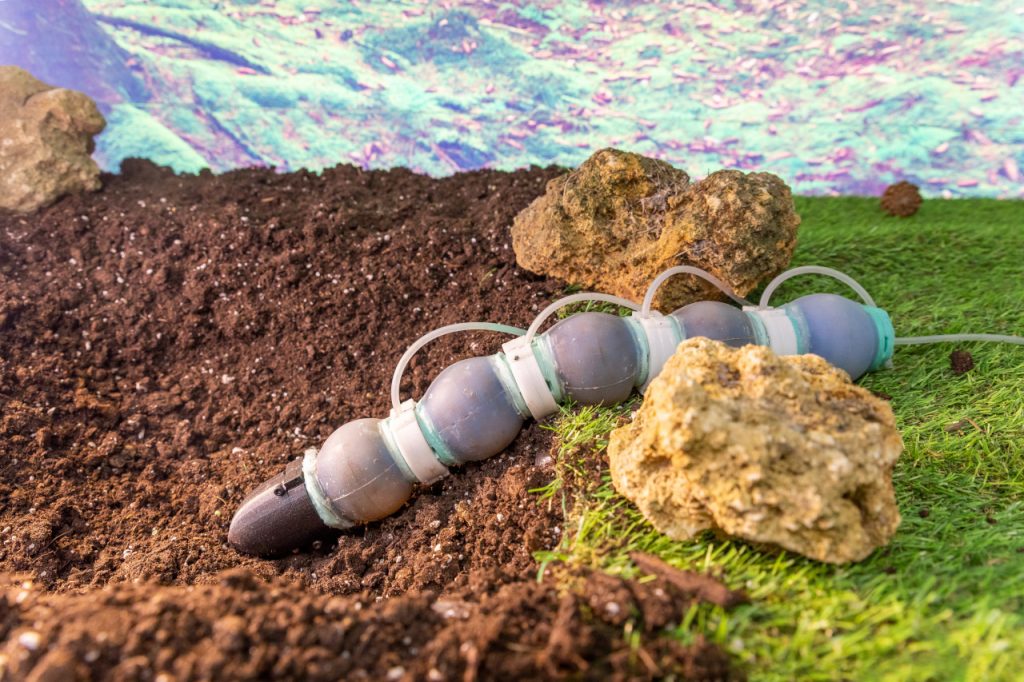
Author: D.Farina. Credits: Istituto Italiano di Tecnologia – © IIT, all rights reserved
Researchers at Istituto Italiano di Tecnologia (IIT-Italian Institute of Technology) in Genova has realized a new soft robot inspired by the biology of earthworms,which is able to crawl thanks to soft actuators that elongate or squeeze, when air passes through them or is drawn out. The prototype has been described in the international journal Scientific Reports of the Nature Portfolio, and it is the starting point for developing devices for underground exploration, but also search and rescue operations in confined spaces and the exploration of other planets.
Nature offers many examples of animals, such as snakes, earthworms, snails, and caterpillars, which use both the flexibility of their bodies and the ability to generate physical travelling waves along the length of their body to move and explore different environments. Some of their movements are also similar to plant roots.
Taking inspiration from nature and, at the same time, revealing new biological phenomena while developing new technologies is the main goal of the BioInspired Soft robotics lab coordinated by Barbara Mazzolai, and this earthworm-like robot is the latest invention coming from her group.
The creation of earthworm-like robot was made possible through a thorough understanding and application of earthworm locomotion mechanics. They use alternating contractions of muscle layers to propel themselves both below and above the soil surface by generating retrograde peristaltic waves. The individual segments of their body (metameres) have a specific quantity of fluid that controls the internal pressure to exert forces, and perform independent, localized and variable movement patterns.
IIT researchers have studied the morphology of earthworms and have found a way to mimic their muscle movements, their constant volume coelomic chambers and the function of their bristle-like hairs (setae) by creating soft robotic solutions.
The team developed a peristaltic soft actuator (PSA) that implements the antagonistic muscle movements of earthworms; from a neutral position it elongates when air is pumped into it and compresses when air is extracted from it. The entire body of the robotic earthworm is made of five PSA modules in series, connected with interlinks. The current prototype is 45 cm long and weighs 605 grams.
Each actuator has an elastomeric skin that encapsulates a known amount of fluid, thus mimicking the constant volume of internal coelomic fluid in earthworms. The earthworm segment becomes shorter longitudinally and wider circumferentially and exerts radial forces as the longitudinal muscles of an individual constant volume chamber contract. Antagonistically, the segment becomes longer along the anterior–posterior axis and thinner circumferentially with the contraction of circumferential muscles, resulting in penetration forces along the axis.
Every single actuator demonstrates a maximum elongation of 10.97mm at 1 bar of positive pressure and a maximum compression of 11.13mm at 0.5 bar of negative pressure, unique in its ability to generate both longitudinal and radial forces in a single actuator module.
In order to propel the robot on a planar surface, small passive friction pads inspired by earthworms’ setae were attached to the ventral surface of the robot. The robot demonstrated improved locomotion with a speed of 1.35mm/s.
This study not only proposes a new method for developing a peristaltic earthworm-like soft robot but also provides a deeper understanding of locomotion from a bioinspired perspective in different environments. The potential applications for this technology are vast, including underground exploration, excavation, search and rescue operations in subterranean environments and the exploration of other planets. This bioinspired burrowing soft robot is a significant step forward in the field of soft robotics and opens the door for further advancements in the future.
AUAI is supported by:









