
Robohub.org
 

Calligraphy robot uses a Motion Copy System to reproduce detailed brushwork

by
11 October 2012


share this:
12-0181-r

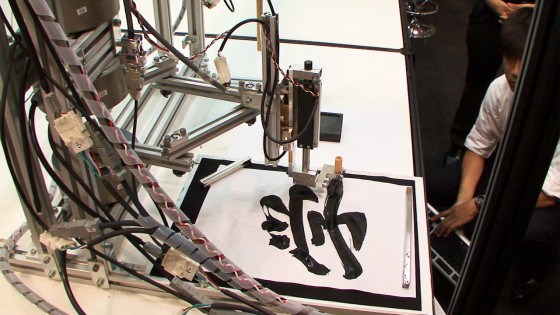
A research group at Keio University, led by Seiichiro Katsura, has developed the Motion Copy System. This system can identify and store detailed brush strokes, based on information about movement in calligraphy. This enables a robot to faithfully reproduce the detailed brush strokes.

This system stores calligraphy movements by using a brush where the handle and tip are separate. The two parts are connected, with the head as the master system and the tip as the slave system. Characters can be written by handling the device in the same way as an ordinary brush.

Unlike conventional motion capture systems, a feature of this one is, it can record and reproduce the force applied to the brush as well as the sensation when you touch something. Until now, passing on traditional skills has depended on intuition and experience. It’s hoped that this new system will enable skills to be learned more efficiently.

“What’s new is, there’s a motor attached to the brush, so while the person’s moving, the motion and force are recorded as digital data using the motor. What’s more, with this technology, the recorded motion and force can be reproduced anytime, anywhere using the motor.”

“We’ve succeeded in using the motor to record the movements of a veteran calligrapher, and to actually reproduce them. So, I think we’ve demonstrated that, to record and reproduce human skills, it’s necessary to record not just motions, but also how strongly those motions are made.”

Looking at the graph of position and brush pressure, the position of the master system and the motion of the slave system are consistent, and also, the pressure shows the opposite waveform. This shows that the law of action and reaction is being artificially implemented between the master and slave systems.

“Currently, multimedia only uses audiovisual information. But we’d like to bring force, action, and motion into IT, by reproducing this kind of physical force via a network, or storing skills on a hard disk for downloading. So, with this new form of IT, you’d be able to access skill content.”


DigInfo TV is a Tokyo-based online video news platform dedicated to producing original coverage of cutting edge technology, research and products from Japan.

            AUAI is supported by:


Subscribe to Robohub newsletter on substack


Related posts :

Robot Talk Episode 171 – Programming robot behaviour, with Sebastian Castro

  20 Nov 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Sebastian Castro about developing open-source software for robot task planning and behaviour.

Soft exosuit makes it easier to stand up

Robotic system helps users stand up and walk more efficiently.

Robot swarms trained by trial and error in simulation keep working on real robots

  17 Nov 2026
Researchers have developed a new approach to reinforcement learning that helps robot swarms, allowing behaviours learned in simulation to transfer reliably to real-world robots.

Watch the IROS 2026 plenary and keynote talks

  16 Nov 2026
Catch up on the invited presentations from the International Conference on Intelligent Robots and Systems.

Robot Talk Episode 170 – Robots in the real world, with Daniela Shchegelskaya

  13 Nov 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Daniela Shchegelskaya from the University of Twente about getting robots to operate reliably in safety-critical environments.

AI100 report released: embodied AI highlighted as grand challenge

  11 Nov 2026
Embodied AI is listed as one of the most inspiring open grand challenges.

AIhub coffee corner: Are humanoids the future of embodied AI?

  09 Nov 2026
The AIhub coffee corner captures the musings of AI experts over a short conversation.

Robot Talk Episode 169 – Robot sensing inspired by nature, with Dexter Shepherd

  06 Nov 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Dexter Shepherd from the University of Sussex about using artificial intelligence to help robots understand and adapt to their environment.


↑


AUAI is supported by:


Subscribe to Robohub newsletter on substack


©2026.05 - Association for the Understanding of Artificial Intelligence










