
Robohub.org
Delphi completes trans-continental drive, and Hyundai goes big
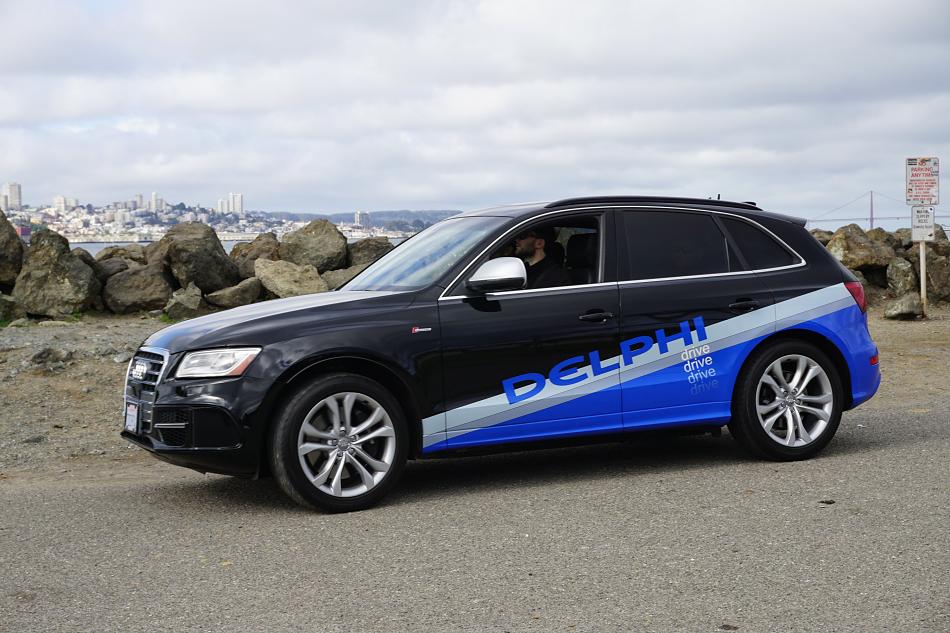 Most recent robocar press has been about the Delphi drive from San Francisco to New York, which is now completed. Congratulations to the team. Few teams have tried to do such a long course that involved so many different roads. (While Google has over a million miles logged in their testing by now, it’s not been reported that they have done 3,500 distinct roads; most testing is done around Google HQ.)
The team reported that the vehicle drove 99% of the time. This is both an impressive and unimpressive number, and understanding that is key to understanding the difficulty of the robocar problem.
One of the earliest pioneers, Ernst Dickmanns did a long highway drive 20 years ago, in 1995. He reported the system drove 95% of the time, kicking out every 10km or so. This system simply found the edge of the road, and kept in the lane by tracking that. Delphi’s car is much more sophisticated, with a very impressive array of sensors — 10 radars, 6 lidars and more, and it has much more sophisticated software.
99% is not 4% better than 95%, it’s 5 times better, because the real number is the fraction of road it could not drive. And from 99%, we need to get something like 10,000 times better — to 99.9999% of the time, to even start talking about a real full-auto robocar. In the US we drive 3 trillion miles per year, and are on the road about 60 billion hours, a little over half of that time on the highway. 99.9999% for all cars would mean still too many accidents if 1 time in 10 million you encountered something and could not handle it.
However, this depends on what we mean by “being unable to handle it.”
- If not handling means “has a fatal accident” that could map to 3,600,000 of those, which would be 100x the human rate and not acceptable.
- If not handling it means “has any sort of accident” then we’re pretty good, about 1/4th of the rate of human accidents.
- If not handling it means that the vehicle knows certain roads are a problem, and diverts around them or requests human assistance, it’s no big problem at all.
- Likewise if not handling it means identifying a trouble situation, and slowing down and pulling off the road, or even just plain stopping in the middle of the road — which is not perfectly safe but not ultra-dangerous either — it’s also not a problem.
At the same time, our technology is an exponential one, so it’s wrong to think that the statement that it needs to be 10,000 times better means the system is only 1/10,000th of the way there. In fact, getting to the goal may not be that far away, and Google is much further along. They reported a distance of over 80,000 miles between necessary interventions. Humans have accidents about ever 250,000 miles.
It should also be noted that Delphi’s result is almost entirely on highways, which are the simplest roads to drive for a robot. Google’s result is also heavily highway biased, though they have reported a lot more surface street work. None of the teams have testing records in complex and chaotic streets such as those found in the developing world, or harsh weather.
It is these facts that lead some people to conclude this technology is decades away. That would be the right conclusion if you were unaware of the exponential curve the technologies and the software development are on.
Huge Hyundai investment
For some time, I’ve been asking where the Koreans are on self-driving cars. Major projects arose in many major car companies, with the Germans in the lead, and then the US and Japan. Korea was not to be seen.
Hyundai announced they would produce highway cruise cars shortly (like other makers) but they also announced they would produce a much more autonomous car by 2020 — a similar number to most car makers as well. Remarkable though was the statement that they would invest over $70 billion in the next 4 years on what they are calling “smart cars,” including hiring over 7,000 people to work on them. While this number includes the factories they plan to build, and refers to many technologies beyond robocars, it’s still an immense number. The Koreans have arrived.
This post originally appeared on robocars.com.
tags: automotive, Delphi

AUAI is supported by:










