
Robohub.org
Drive kinematics: Skid steer and mecanum (ROS twist included)
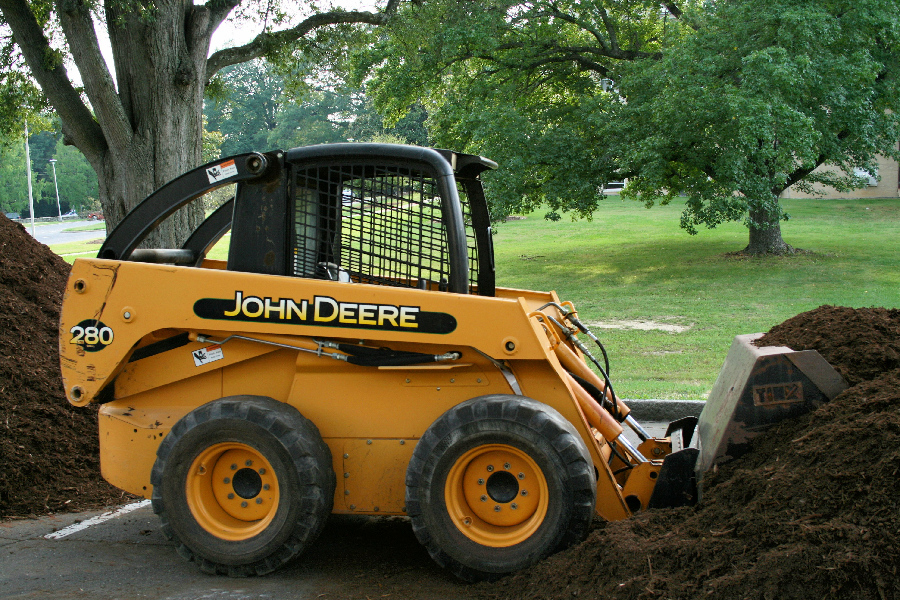
Photo: Wikipedia
I am often in need of the basic kinematic motion equations for skid steer vehicles. I have also recently been working with mecanum wheeled vehicles. The skid steer equations are fairly simple and easy to find, however, I will include it in different versions and include a ROS approach. The mecanum wheel equations are harder to find and there are different versions floating around. The first version I found had a lot of trig and mostly worked. The version I present here is easier to intuitively understand and seems to work better (I don’t need a random scale factor for this version), I also include a ROS approach for them.
Skid Steer / Differential Drive
Here is some math for 2 and 4 wheel differential drive vehicles, 2 wheels and a castor, or skid steer tracked vehicles.
Arc based commands
The basic skid steer equations are:
velocity_right = w(RADIUS_OF_ARC_TO_DRIVE + WHEEL_BASE/2)
velocity_left = w(RADIUS_OF_ARC_TO_DRIVE – WHEEL_BASE/2)
Where w is the angular rotation, RADIUS_OF_ARC_TO_DRIVE is the arc radius that the robot should drive, and the WHEEL_BASE is the distance from the center of the left wheel to the center of the right wheel (See image above).
This can also be written as:
w = (velocity_right-velocity_left)/WHEEL_BASE
There are two special cases:
IF velocity_right == velocity_left :
THEN the radius of the arc is infinite so the robot will drive straight.
IF velocity_right == -velocity_left :
THEN the radius of the arc is 0, and the robot rotates in place (ie. point turn)
Linear & Angular Velocity Commands for ROS
In ROS if using the Twist topic (which is the default for drive messages) (message name is often cmd_vel) you will often set linear_velocity in the linear.x field and angular_velocity in the angular.zfield.
velocity_left_cmd = (linear_velocity – angular_velocity * WHEEL_BASE / 2.0)/WHEEL_RADIUS;
velocity_right_cmd = (linear_velocity + angular_velocity * WHEEL_BASE / 2.0)/WHEEL_RADIUS;
Mecanum Wheel Math
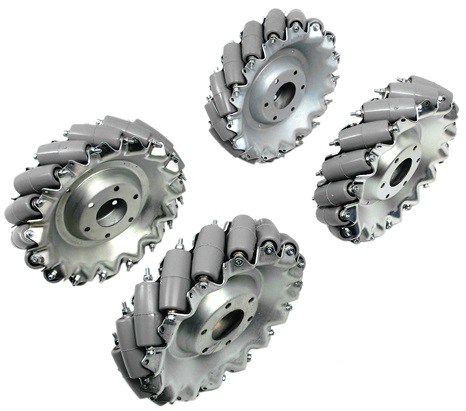
Mecanum wheels from Andymark
In ROS if using the Twist message you will often set the linear.x, linear.y and angular.z fields. One unrelated note is that if you are operating on uneven terrain then doing mecanum type motions will fail and have a lot of slip. Skid steer type motions will often work better (using the mecanum wheels).
WHEEL_SEPARATION_WIDTH = DISTANCE_LEFT_TO_RIGHT_WHEEL / 2
WHEEL_SEPARATION_LENGTH = DISTANCE_FRONT_TO_REAR_WHEEL / 2
Forward kinematics
Wheel commands units are in rad/s
wheel_front_left = (1/WHEEL_RADIUS) * (linear.x – linear.y – (WHEEL_SEPARATION_WIDTH + WHEEL_SEPARATION_LENGTH)*angular.z);
wheel_front_right = (1/WHEEL_RADIUS) * (linear.x + linear.y + (WHEEL_SEPARATION_WIDTH + WHEEL_SEPARATION_LENGTH)*angular.z);
wheel_rear_left = (1/WHEEL_RADIUS) * (linear.x + linear.y – (WHEEL_SEPARATION_WIDTH + WHEEL_SEPARATION_LENGTH)*angular.z);
wheel_rear_right = (1/WHEEL_RADIUS) * (linear.x – linear.y + (WHEEL_SEPARATION_WIDTH + WHEEL_SEPARATION_LENGTH)*angular.z);
To drive a robot you will probably need to also invert one side since the motors are mounted opposite the other side. For example:
wheel_front_right = -1 * wheel_front_right
wheel_rear_right = -1 * wheel_rear_right
Also this gives an output in rad/s. If your motor controller is operating with encoder counts as the unit you will need to convert the units.
Inverse Kinematics
linear.x = (wheel_front_left + wheel_front_right + wheel_rear_left + wheel_rear_right) * (WHEEL_RADIUS/4)
linear.y = ( -wheel_front_left + wheel_front_right + wheel_rear_left – wheel_rear_right) * (WHEEL_RADIUS/4)
angular.z = ( -wheel_front_left + wheel_front_right – wheel_rear_left + wheel_rear_right) * (WHEEL_RADIUS/(4 * (WHEEL_SEPARATION_WIDTH + WHEEL_SEPARATION_LENGTH)))
Source for mecanum wheel math: here. There are other versions of how to compute the wheel velocities but this is the one I like best.
If you have any pressing questions, visit the Robots for Roboticists Forum.
The post “Drive Kinematics: Skid Steer & Mecanum (ROS Twist included)” appeared on Robots For Roboticists.
tags: c-Education-DIY
AUAI is supported by:









