
Robohub.org
Drones that patrol forests could monitor environmental and ecological changes
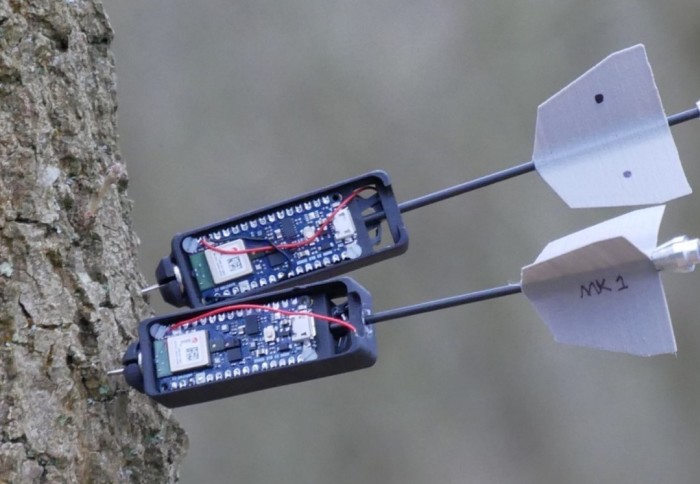
Credit: Imperial College London
By Caroline Brogan
Imperial researchers have created drones that can attach sensors to trees to monitor environmental and ecological changes in forests.
Sensors for forest monitoring are already used to track changes in temperature, humidity and light, as well as the movements of animals and insects through their habitat. They also help to detect and monitor forest fires and can provide valuable data on how climate change and other human activities are impacting the natural world.
However, placing these sensors can prove difficult in large, tall forests, and climbing trees to place them poses its own risks.
Now, researchers at Imperial College London’s Aerial Robotics Lab have developed drones that can shoot sensor-containing darts onto trees several metres away in cluttered environments like forests. The drones can also place sensors through contact or by perching on tree branches.
Via GIPHY. Credit: Imperial College London
I like to think of them as artificial forest inhabitants who will soon watch over the ecosystem and provide the data we need to protect the environment.
Professor Mirko Kovac, Department of Aeronautics
The researchers hope the drones will be used in future to create networks of sensors to boost data on forest ecosystems, and to track hard-to-navigate biomes like the Amazon rainforest.
Lead researcher Professor Mirko Kovac, Director of the Aerial Robotics Lab from the Department of Aeronautics at Imperial said: “Monitoring forest ecosystems can be difficult, but our drones could deploy whole networks of sensors to boost the amount and precision of environmental and ecological data.
“I like to think of them as artificial forest inhabitants who will soon watch over the ecosystem and provide the data we need to protect the environment.”
The drones are equipped with cameras to help identify suitable targets, and a smart material that changes shape when heated to launch the darts, which then stick to the trees. They can also perch on tree branches like birds to collect data themselves, acting as mobile sensors.
The researchers have tested their drones at the Swiss Federal Laboratories for Materials Science and Technology (EMPA) and on trees at Imperial’s Silwood Park Campus.
Via GIPHY. Credit: Imperial College London
We aim to introduce new design and control strategies to allow drones to effectively operate in forested environments.
Dr Salua Hamaza, Department of Aeronautics
The drones are currently controlled by people: using control units, the researchers watch through the camera lens to select target trees and shoot the darts. The next step is to make the drones autonomous, so that researchers can test how they fare in denser forest environments without human guidance.
Co-author André Farhina, of the Department of Aeronautics, said: “There are plenty of challenges to be addressed before the drones can be regularly used in forests, like achieving a careful balance between human input and automated tasks so that they can be used safely while remaining adaptable to unpredictable environments.”
Co-author Dr Salua Hamaza, also of the Department of Aeronautics, said: “We aim to introduce new design and control strategies to allow drones to effectively operate in forested environments. Exploiting smart mechanisms and new sensing techniques we can off-load the on-board computation, and create platforms that are energy-efficient and better performing.”
- Hamaza, S., Farinha, A., Nguyen, H.N. and Kovac, M., 2020, November. Sensor Delivery in Forests with Aerial Robots: A New Paradigm for Environmental Monitoring. In IEEE IROS Workshop on Perception, Planning and Mobility in Forestry Robotics.
- Nguyen, H.N., Siddall, R., Stephens, B., Navarro-Rubio, A. and Kova?, M., 2019, April. A Passively Adaptive Microspine Grapple for Robust, Controllable Perching. In 2019 2nd IEEE International Conference on Soft Robotics (RoboSoft) (pp. 80-87). IEEE. Video.
- Farinha, A., Zufferey, R., Zheng, P., Armanini, S.F. and Kovac, M., 2020. Unmanned Aerial Sensor Placement for Cluttered Environments. IEEE Robotics and Automation Letters, 5(4), pp.6623-6630. Video.
These works were funded by the EPSRC, ORCA Robotics Hub, EU Horizon 2020, NERC (QMEE CDT), UKAEA with RACE and the Royal Society.
tags: environment & agriculture, UAVs & drones
AUAI is supported by:










