
Robohub.org
Echoes of the DRC at Humanoids 2015
Last week, the Humanoids 2015 conference was held in Seoul, Korea. It’s the first event to focus on humanoid robots since the Darpa Robotics Challenge (DRC) earlier this year and, in fact, the location is home to the DRC winners, Team KAIST. Hence, it was no surprise that the event was very DRC orientated and even featured a mini-Darpa challenge.
Humanoids is a small conference compared to IROS or ICRA. And I really appreciate that because it gives you the chance to interact more closely with people that actually work in the humanoid field; less people, fewer concurrent sessions and more interaction.
The conference lasted three days, with the first dedicated to workshops and the others to the main conference itself.
I attended the Benchmarking bipedal functions of humanoids robots: towards a unified framework workshop and gave a talk about how to use cloud simulations for benchmarking in a general and unbiased way. Very interesting papers were presented at that workshop, especially about how to build a general framework to benchmark walking in humanoids (by partners in the Koroibot project)
The main conference was divided into plenary talks, paper presentations and interactive sessions. There were guided visits to the laboratories of KIST (the Korean Institute for Science and Technology) and a full demo of the Hubo robot doing all the DRC tests.
I loved the two plenary talks, especially the first one given by Aude Billard from EPFL. She presented a beautiful path of research towards the creation of robots that can do better than humans (super-human competences). She showed her results with the study of a robot that was able to grasp a racket when it was thrown, by making use of dynamical systems. It was impressive to see how her robot was able to grasp rackets and even balls, where a human is not able to do this.
The second plenary talk was given by Russ Tedrake, a DRC participant. He outlined several problems the teams faced when trying to control a robot during the challenge. He demonstrated his quest in trying to exploit the structure of the governing equations of model based control, in order to create more robust control for robot dynamics. I really enjoyed his talk, even if I did not understand it very much.
Paper presentations were limited to ten minutes per publication and I recommend you check the whole list of presented papers here.
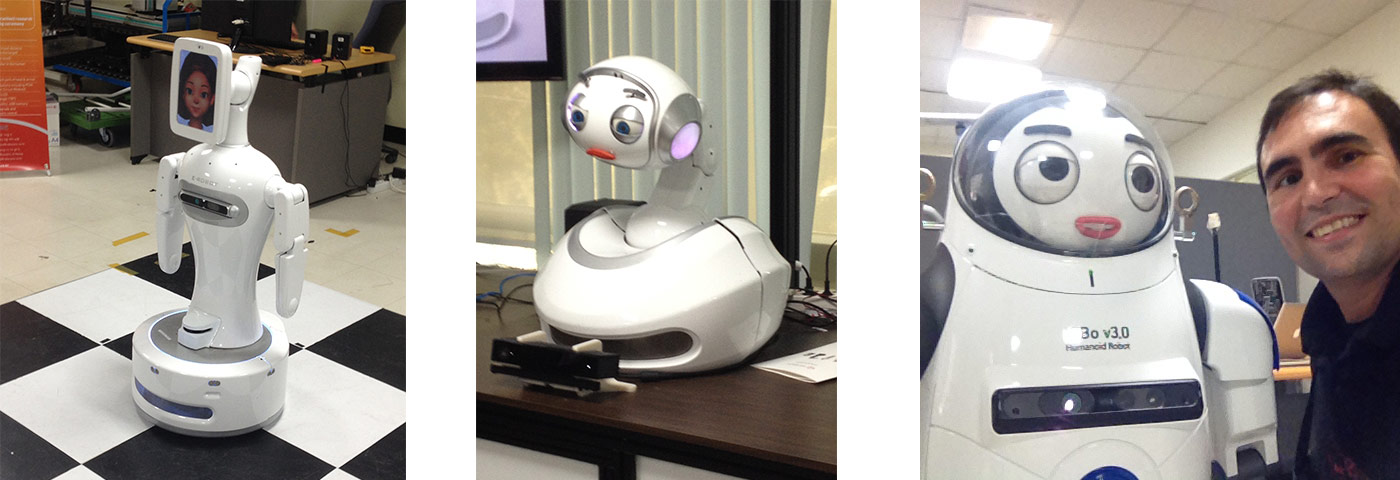
The Technical Tours were visits to some the KIST laboratories like the Center for Intelligent Robotics, and the Healthcare Robotics Research Group. The first lab is dedicated to the use of social robots to enhance the cognitive abilities of the elderly. It’s focused on small humanoids that engage the elderly to play games that stress their cognitive skills. The second lab is more concerned with robots for surgery.
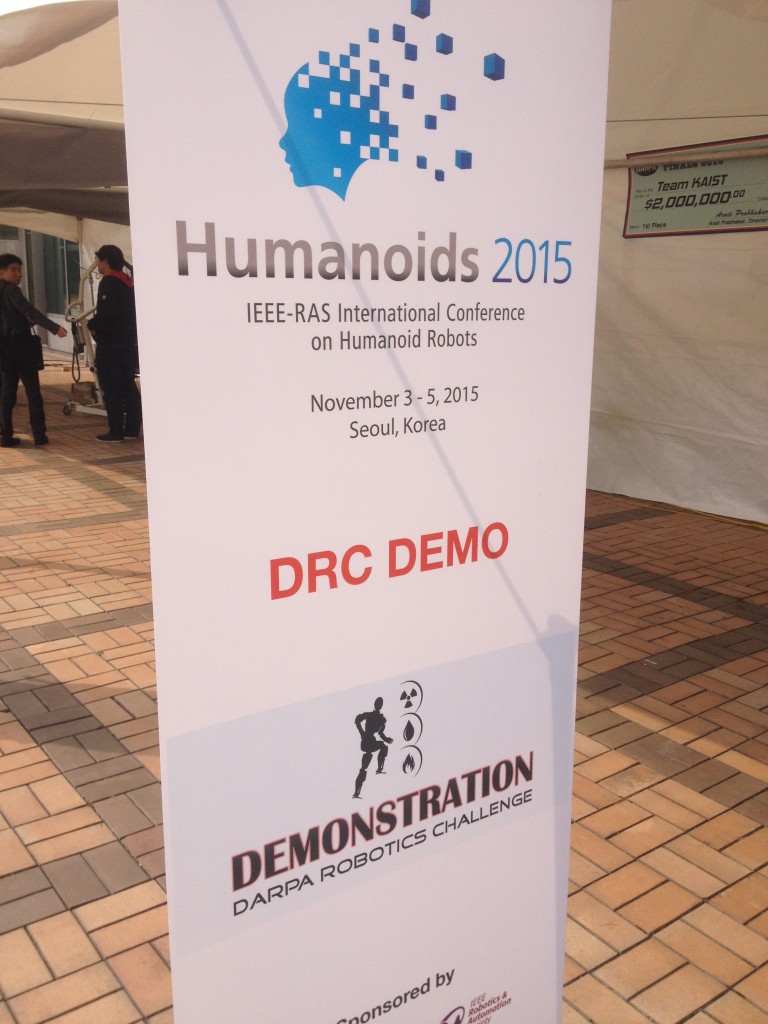
Now, the most impressive activity was the DRC demo. It was amazing to see how the KAIST team performed a complete demo from beginning to end without any trouble. The robot was able to get into the car, drive, get out, open a door, close the valve, perform a drill, walk and finally climb the stairs. And they did this on three consecutive days. Based on my experience at several Robocup competitions, I know how difficult it is to make all this work for a demo, so I cannot say anything but: bravo KAIST!
Evaluating the conference, from my point of view, I feel that it is very (too much) focused on control for humanoids. The vast majority of papers are dedicated to specific control problems that humanoids face and that make them so much more complex than wheeled robots. I, personally, noticed the lack of papers more concerned with cognitive issues, where the fact that the robot is a humanoid might be used to create more complex behaviours.
There could also have been a panel of experts of some sort to analyse the results of the DARPA Robotics Challenge and how a second round of the contest would improve humanoid technology (or not).
Perhaps next year!
tags: DARPA, DRC, events, healthcare, humanoids, research
AUAI is supported by:









