
Robohub.org
euRathlon 2013 land robotics competition – Day Four recap
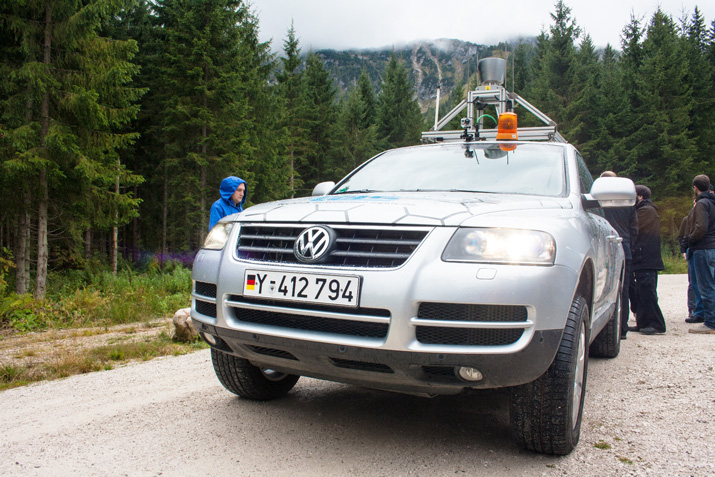
Clouds, mist and rain accompanied the fourth day of euRathlon 2013 civilian outdoor robotics competition. Thursday was the day when the “Autonomous Navigation” scenario took place in an area of the Kehlstein mountain (1.834 m), located in the Berchtesgaden Alps. Unfortunately teams and robots had to deal with heavy rain. Despite of the poor weather conditions, which are part of a real world scenario, many robots successfully finished two of the three levels of autonomous navigation.
Watch the Day Four recap video …
The 4th Scenario: Autonomous navigation
The “Autonomous navigation” scenario took place in the breathtaking landscape of the Berchtesgaden Alps. The robots had to autonomously navigate an Alpine trail on the Kehlstein mountain. The trail had three levels of difficulty. At the end of the first and second levels, there was a sign that the robot could detect and choose whether or not to continue to the next level. The first-level terrain was gravel and the path was slightly inclined, while the second level had the same type of gravel terrain, but the path was steeper and was scattered with medium-size tree branches. The third-level path was narrow and steep with rocky terrain.
The competing robots had 45 minutes to reach the end of the third level or, if they decided not to traverse that very difficult path, reach the first or second level and come back.
Spectators followed the slower-moving robots as they performed this task, and watched a recording of the faster-moving ones on a big screen once they returned to the starting point.
Despite the poor weather conditions, many robots successfully reached the end of level two. All the robots were fully autonomous and not tele-operated. However, each had a system that allowed the robot operator, who was following the robot next to the judge, to take control of the robot if needed, for example, if the robot was lost, got stuck, or could not navigate. Some robots required human intervention as they performed the task, and were consequently penalized. However, all teams did well bearing in mind the poor weather and the completely unknown terrain.
Of the seven teams initially signed up for this scenario, two withdrew before the competition and the rest qualified for the final. These five teams were: MuCar, ARTOR, RIS, FKIE and NAMT.
In tomorrow’s post, the winners of euRathlon 2013 will be unveiled. Don’t miss it!
See all the euRathlon 2013 coverage.
tags: euRathlon, euRathlon 2013, events, research
AUAI is supported by:










