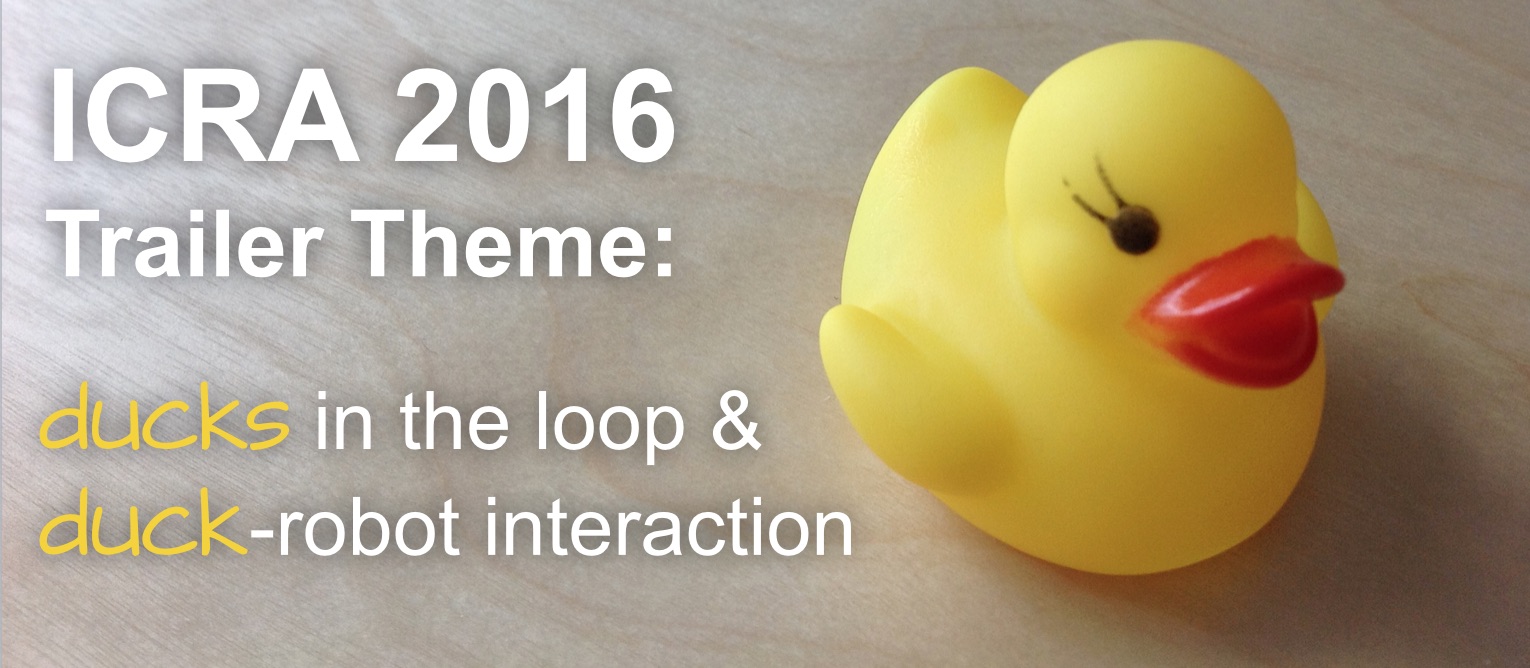
The robotics community have created a series of video tributes that showcase some of the contributions to ICRA, the largest conference in the field of robotics and automation. Episode one features flying robots that can fly, walk, and grasp, with rubber duckies!
Stay tuned for episode two: daily life activities.
Papers featured in this video:
“Dynamic Underactuated Flying-Walking (DUCK) Robot” Christopher J. Pratt and Kam K. Leang
Duckies can fly, walk, swim and dive. Likewise, this robot is able to fly and walk, by combining the body of a quadrotor, together with passive legs, which are not actively powered. The robot can walk down an inclined surface with its propeller motors turned off, and use the propellers to walk on flat surfaces and to fly.
“Saccade Mirror 3: High-speed gaze controller with ultra wide gaze control range using triple rotational mirrors” Kazuhisa Iida, Hiromasa Oku (Gunma University)
This robotic perception system can track fast objects with very high accuracy over a wide field of view, by using a 1000 frames-per-second camera and three mirrors that are actively controlled. In this clip, the system is tracking a flying duckie.
“Trajectory Generation for Quadrotor based Systems using Numerical Optimal Control”
Mathieu Geisert, Nicolas Mansard (LAAS-CNRS)
This work develops an algorithm to allow a drone to pick up an object while in flight. Optimizing the trajectory is especially challenging because of the interaction of the dynamics of flight and the dynamics of an articulated manipulator.
“The Flying Monkey: a Mesoscale Robot that can Run, Fly, and Grasp”
Yash Mulgaonkar, Brandon Araki, Je-sung Koh, Luis Guerrero-Bonilla, Daniel M. Aukes, Anurag Makineni, Michael T. Tolley, Daniela Rus, Robert J. Wood, Vijay Kumar (UPenn, Harvard, MIT, UCSD)
This is the “flying monkey”, a robot that can fly, walk, and grasp. This new robotic platform merges one of the world’s smallest quadrotor aircraft with a lightweight, simple walking mechanism and a gripper to enable all three functions in a 30g package.
Visit ICRA 2016 trailer to watch upcoming clips and read the ICRA 2016 duckies poems.
tags:
c-Events,
ICRA16
Robohub Editors










