
Robohub.org
Multi-directional gravity assist harness helps rehabilitation
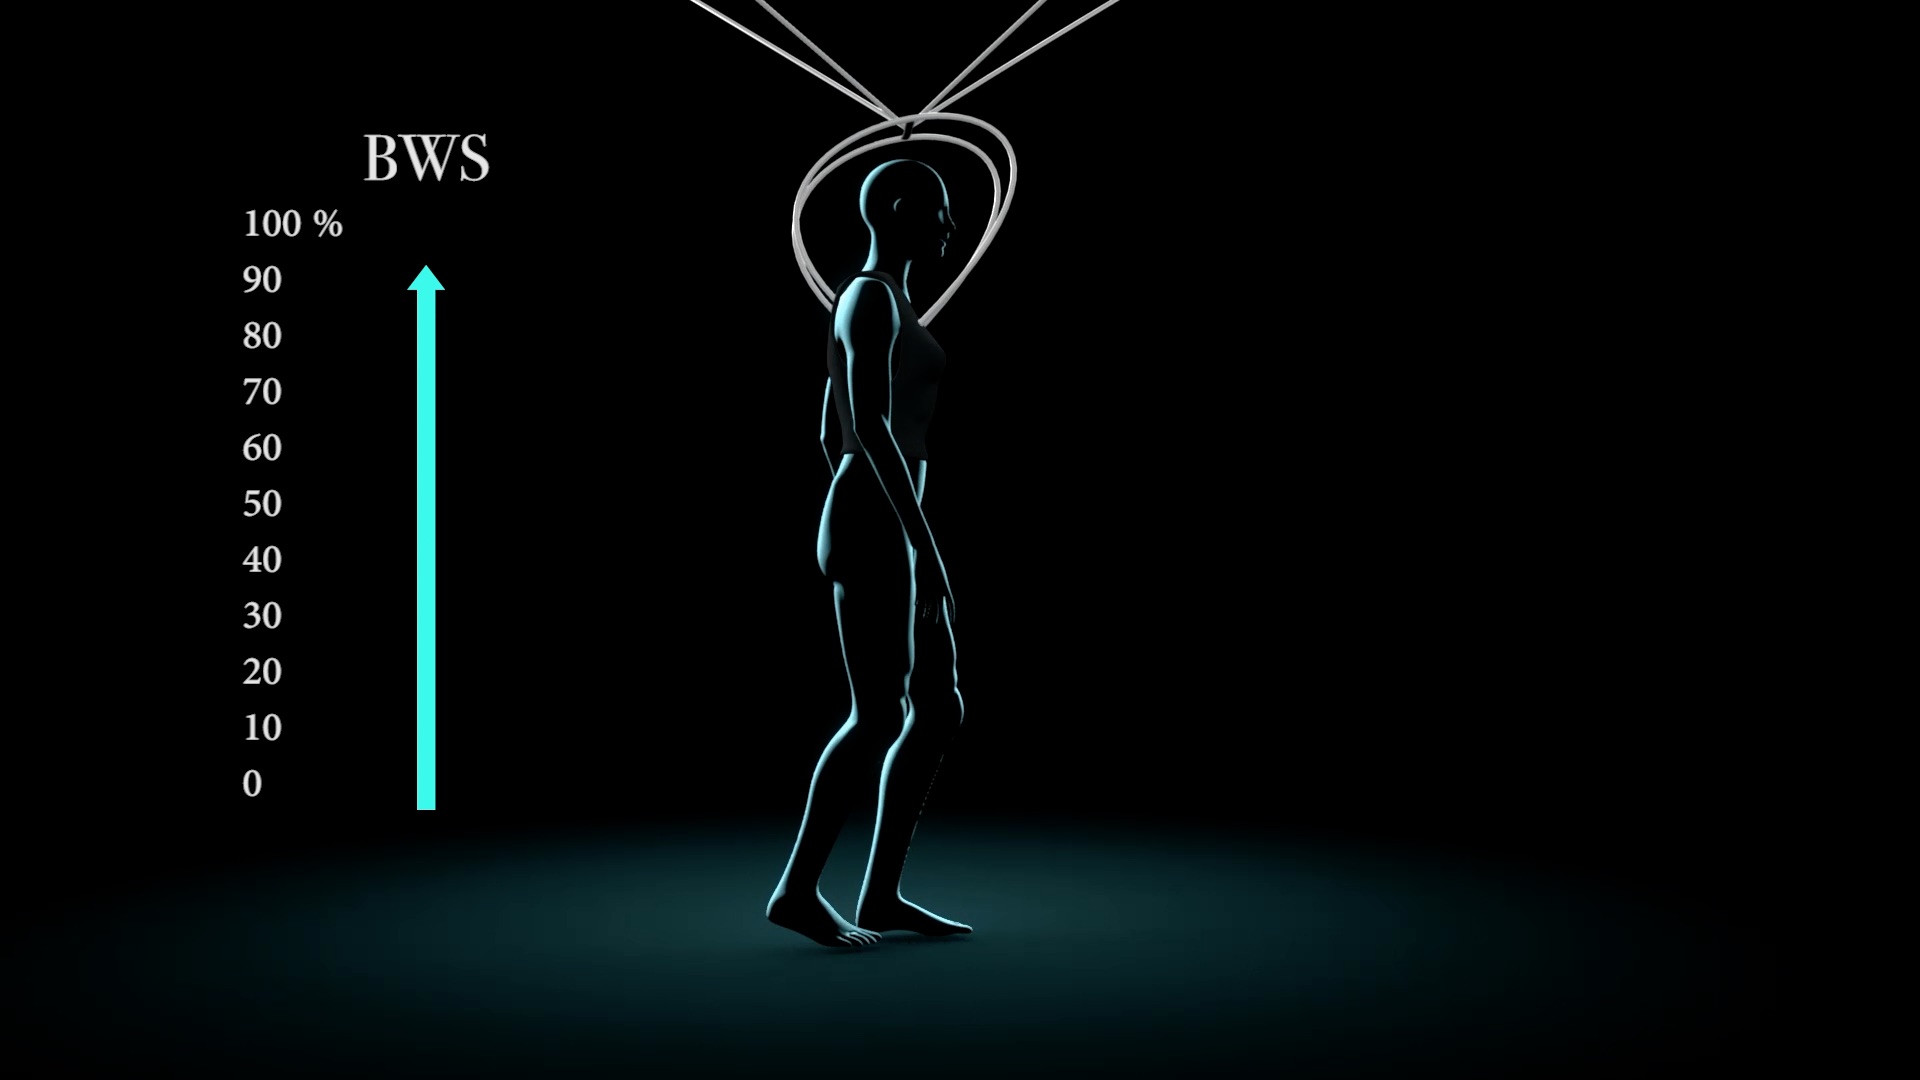
Credit: EPFL
When training to regain movement after stroke or spinal cord injury (SCI), patients must once again learn how to keep their balance during walking movements. Current clinical methods support the weight of the patient during movement, while setting the body off balance. This means that when patients are ready to walk without mechanical assistance, it can be hard to re-train the body to balance against gravity. This is the issue addressed in a recent paper published in Science Translational Medicine by a team lead by Courtine-Lab, and featuring Ijspeert Lab, NCCR Robotics and EPFL.
During walking, a combination of forces move the human body forward. In fact, the interaction of feet with the ground creates the majority of forward propulsion, but with every step, multiple muscles in the body are engaged to maintain movement and prevent falls. In order to fully regain the ability to walk, patients must develop both the muscles and the neural pathways required in these movements.
During partial body weight-supported gait therapy (whereby a patient trains on a treadmill while a robotic support system prevents them from falling), a patient is merely lifted upwards, with no support for forward or sideways movements, massively altering how the person within the support system moves. In fact, those within the training system use shorter steps, slower movements and less body rotation than the same people tested walking unaided.
In an effort to reduce these limitations of current therapy methods, the team developed a multi-directional gravity assist mechanism, meaning that the system supports patients not only in remaining upright, but also in moving forwards. This individually tailored support allows patients to walk in a natural and comfortable way, training the body to counterbalance against gravity and repositioning the torso in a natural position for walking.
The team developed a system, RYSEN, which allows patients to operate within a wide area, and in a range of activities, from standing and walking to walking along a slalom or horizontal ladder light projected onto the floor. They developed an algorithm to take measurements of how the patient is walking, and update the support given to them as they complete their training. The team found that all patients required the system to be tailored to them before use, but that by configuring the upward and forward forces applied during training, almost all subjects experienced significant improvements in movement with even small upward and forward forces on their torso. In fact, patients who experienced paralysis after SCI and stroke, found that by using the system, they were able to walk and thus begin to rebuild muscles and neurological pathways.
This work exists within a larger framework at NCCR Robotics, whereby researchers are using gravity-assisted technologies to play a key role in clinical trials on electrical spinal cord stimulation with the ultimate aim of creating technologies that will improve rehabilitation after spinal cord injury and stroke.
Reference:
Mignardot, J.-B., Le Goff, C. G., van den Brand, R., Capogrosso, M., Fumeaux, N., Vallery, H., Anil, S., Lanini, J., Fodor, I., Eberle, G., Ijspeert, A., Schurch, B., Curt, A., Carda, S., Bloch, J., von Zitzewitz, J. and Courtine, G., “A multidirectional gravity-assist algorithm that enhances locomotor control in patients with stroke or spinal cord injury“, Science Translational Medicine, 2017.
Image: EPFL
tags: healthcare, NCCR Robotics, rehabilitation
AUAI is supported by:










