
Robohub.org
Personalizing wearable devices
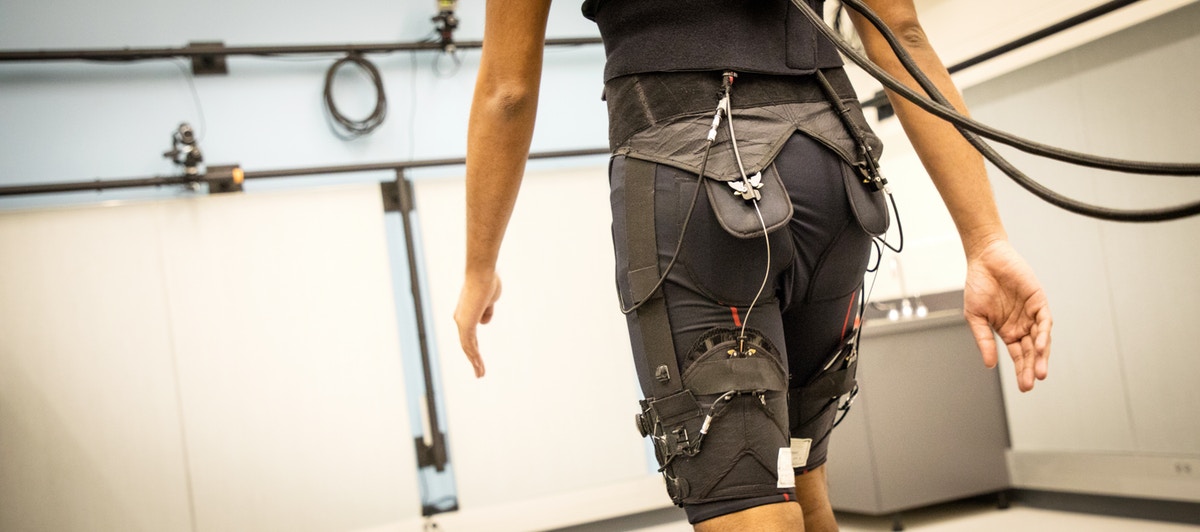
A Bayesian optimization method that integrates the metabolic costs in wearers of this hip-assisting exosuit enabled the individualized fine-tuning of assistive forces. Credit: Ye Ding/Harvard University
When it comes to soft, assistive devices — like the exosuit being designed by the Harvard Biodesign Lab — the wearer and the robot need to be in sync. But every human moves a bit differently and tailoring the robot’s parameters for an individual user is a time-consuming and inefficient process.
Now, researchers from the Wyss Institute for Biologically Inspired Engineering and the Harvard John A. Paulson School of Engineering and Applied and Sciences (SEAS) have developed an efficient machine learning algorithm that can quickly tailor personalized control strategies for soft, wearable exosuits.
The research is described in Science Robotics.
“This new method is an effective and fast way to optimize control parameter settings for assistive wearable devices,” said Ye Ding, a Postdoctoral Fellow at SEAS and co-first author of the research. “Using this method, we achieved a huge improvement in metabolic performance for the wearers of a hip extension assistive device.”
When humans walk, we constantly tweak how we move to save energy (also known as metabolic cost).
“Before, if you had three different users walking with assistive devices, you would need three different assistance strategies,” said Myunghee Kim, Ph.D., postdoctoral research fellow at SEAS and co-first author of the paper. “Finding the right control parameters for each wearer used to be a difficult, step-by-step process because not only do all humans walk a little differently but the experiments required to manually tune parameters are complicated and time consuming.”
The researchers, led by Conor Walsh, Ph.D., Core Faculty member at the Wyss Institute and the John L. Loeb Associate Professor of Engineering and Applied Sciences, and Scott Kuindersma, Ph.D., Assistant Professor of Engineering and Computer Science at SEAS, developed an algorithm that can cut through that variability and rapidly identify the best control parameters that work best for minimizing the energy used for walking.
The researchers used so-called human-in-the-loop optimization, which uses real-time measurements of human physiological signals, such as breathing rate, to adjust the control parameters of the device. As the algorithm honed in on the best parameters, it directed the exosuit on when and where to deliver its assistive force to improve hip extension. The Bayesian Optimization approach used by the team was first report in a paper last year in PLOS ONE.
The combination of the algorithm and suit reduced metabolic cost by 17.4 percent compared to walking without the device. This was a more than 60 percent improvement compared to the team’s previous work.
“Optimization and learning algorithms will have a big impact on future wearable robotic devices designed to assist a range of behaviors,” said Kuindersma. “These results show that optimizing even very simple controllers can provide a significant, individualized benefit to users while walking. Extending these ideas to consider more expressive control strategies and people with diverse needs and abilities will be an exciting next step.”
“With wearable robots like soft exosuits, it is critical that the right assistance is delivered at the right time so that they can work synergistically with the wearer,” said Walsh. “With these online optimization algorithms, systems can learn how do achieve this automatically in about twenty minutes, thus maximizing benefit to the wearer.”
Next, the team aims to apply the optimization to a more complex device that assists multiple joints, such as hip and ankle, at the same time.
“In this paper, we demonstrated a high reduction in metabolic cost by just optimizing hip extension,” said Ding. “This goes to show what you can do with a great brain and great hardware.”
This research was supported by the Defense Advanced Research Projects Agency, Warrior Web Program, Harvard’s Wyss Institute for Biologically Inspired Engineering, and the Harvard John A. Paulson School of Engineering and Applied Science.
tags: research
AUAI is supported by:










