
Robohub.org
ShanghAI Lectures 2013, Lecture 7 – Design principles of intelligent systems
This week we publish the seventh of the ShanghAI Lectures 2013 Edition on Robohub. You can learn more about the ShanghAI lectures here.
Lecture 7 – Design principles of intelligent systems
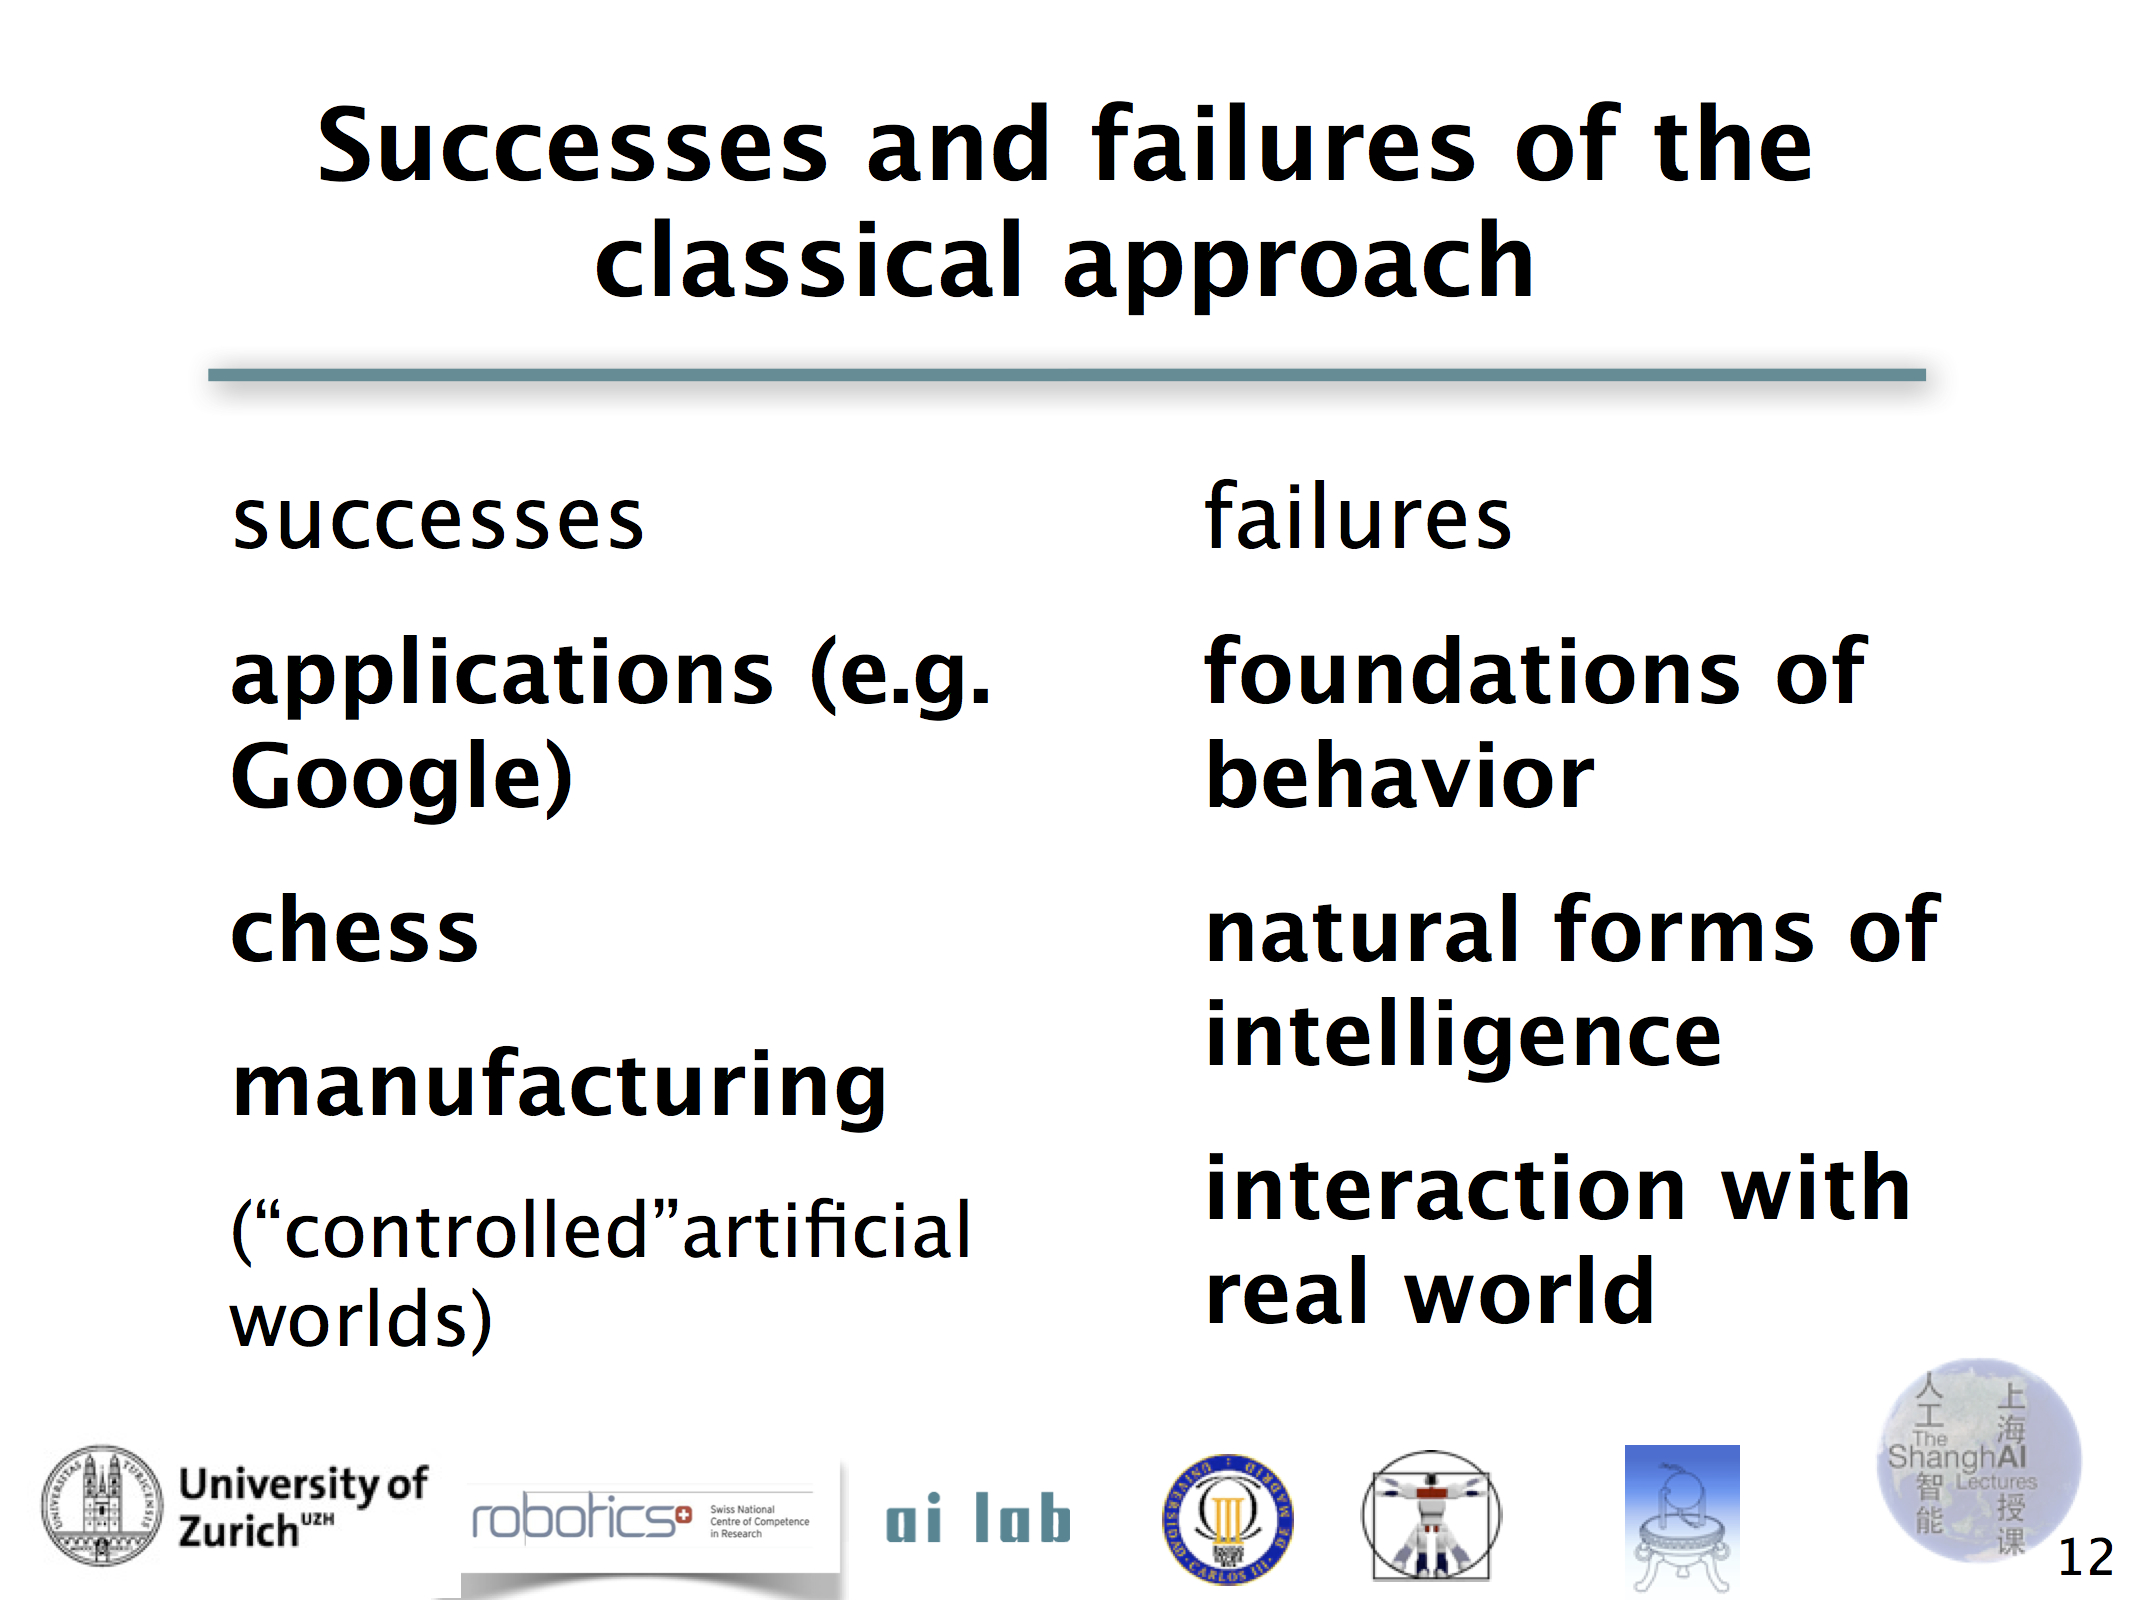 This lecture, which I hosted at the University Carlos III of Madrid, Spain, looks at the foundational issues and the successes and failures of AI from a critical perspective. It details the novel principles discussed in Rolf Pfeifer’s and Josh Bongard’s book ‘How the body shapes the way we think’ , the importance of considering the full embodied agent, the necessity of self-organization, and questions more recent AI successes, such as IBM Watson.
“Making robots that really feel” by Kevin O’Regan
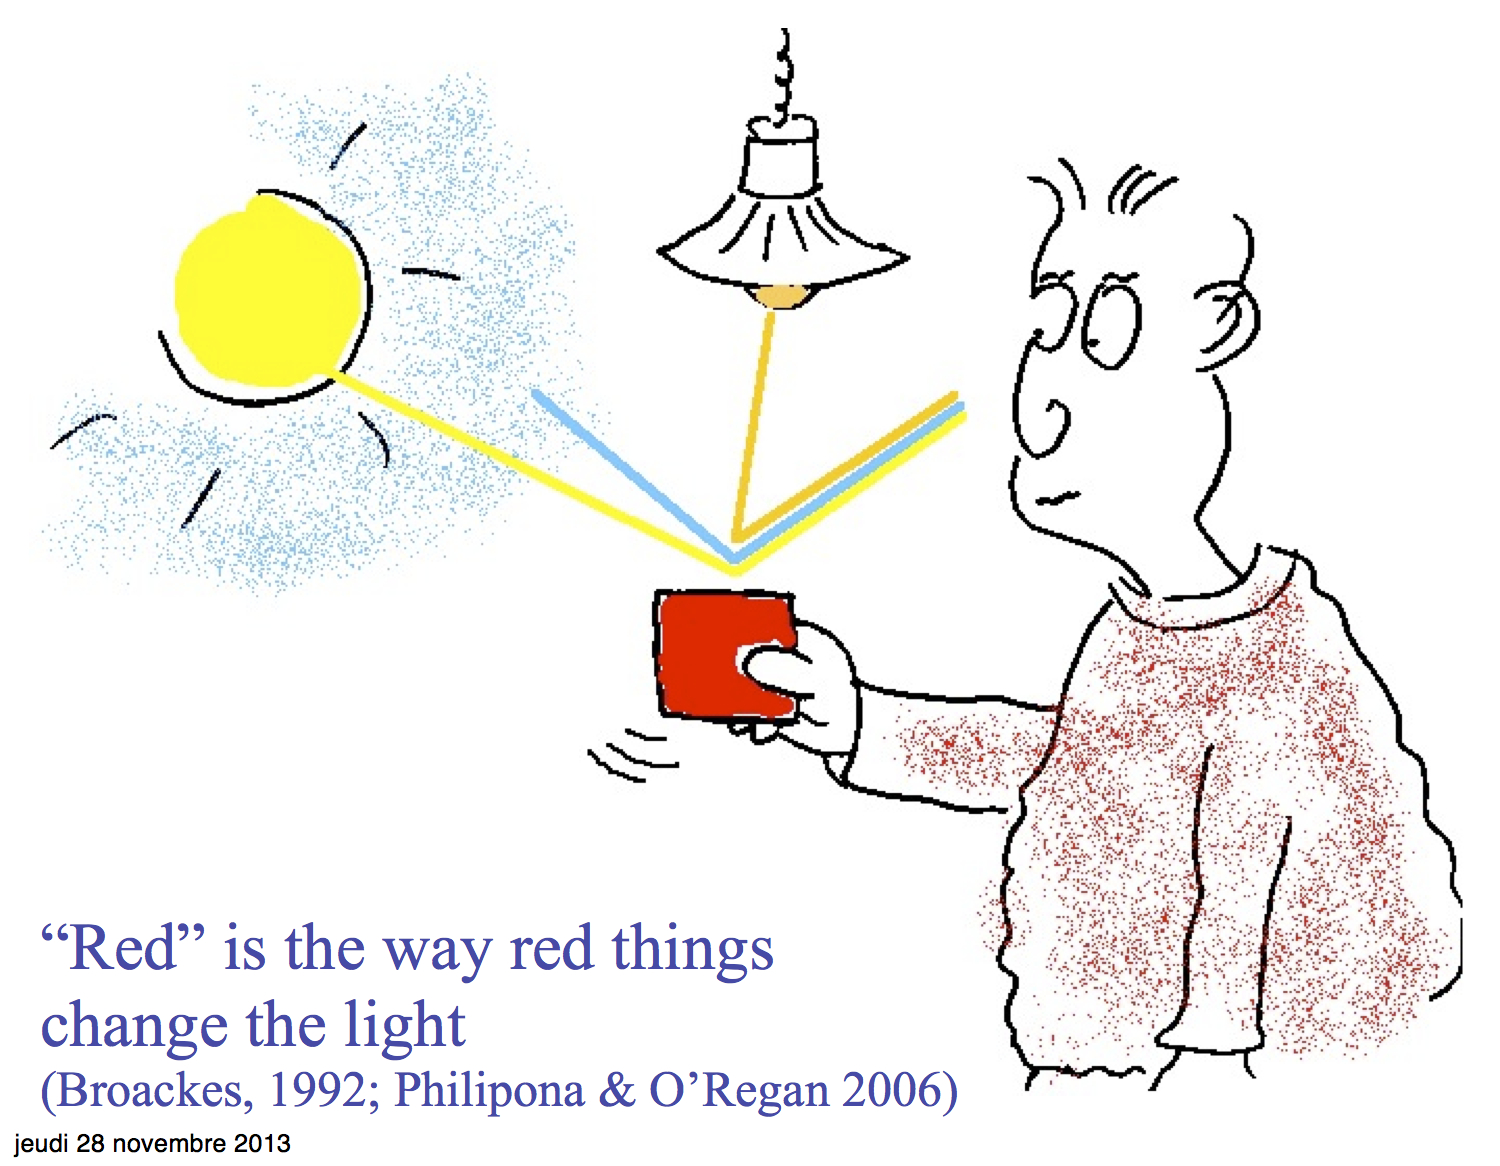
Prof. O’ Regan, former director of the Laboratoire Psychologie de la Perception, CNRS, Université Paris Descartes, in France, is a leading researcher on perception. He questioned established notions of the nature of visual perception and predicted, with collaborators, the phenomenon of “change blindness”. His current work involves exploring the empirical consequences of a new “sensorimotor” approach to vision and sensation in general.
In this talk he discusses the implications and perspectives of ‘phemomenal consciousness’. What colour is ‘red’? Why doesn’t red ‘sound like a bell’? Watch Kevin’s talk:
Guest Lecture – “Visual Servo Control of Cable-Driven Soft Robotic Manipulator” by Hesheng Wang
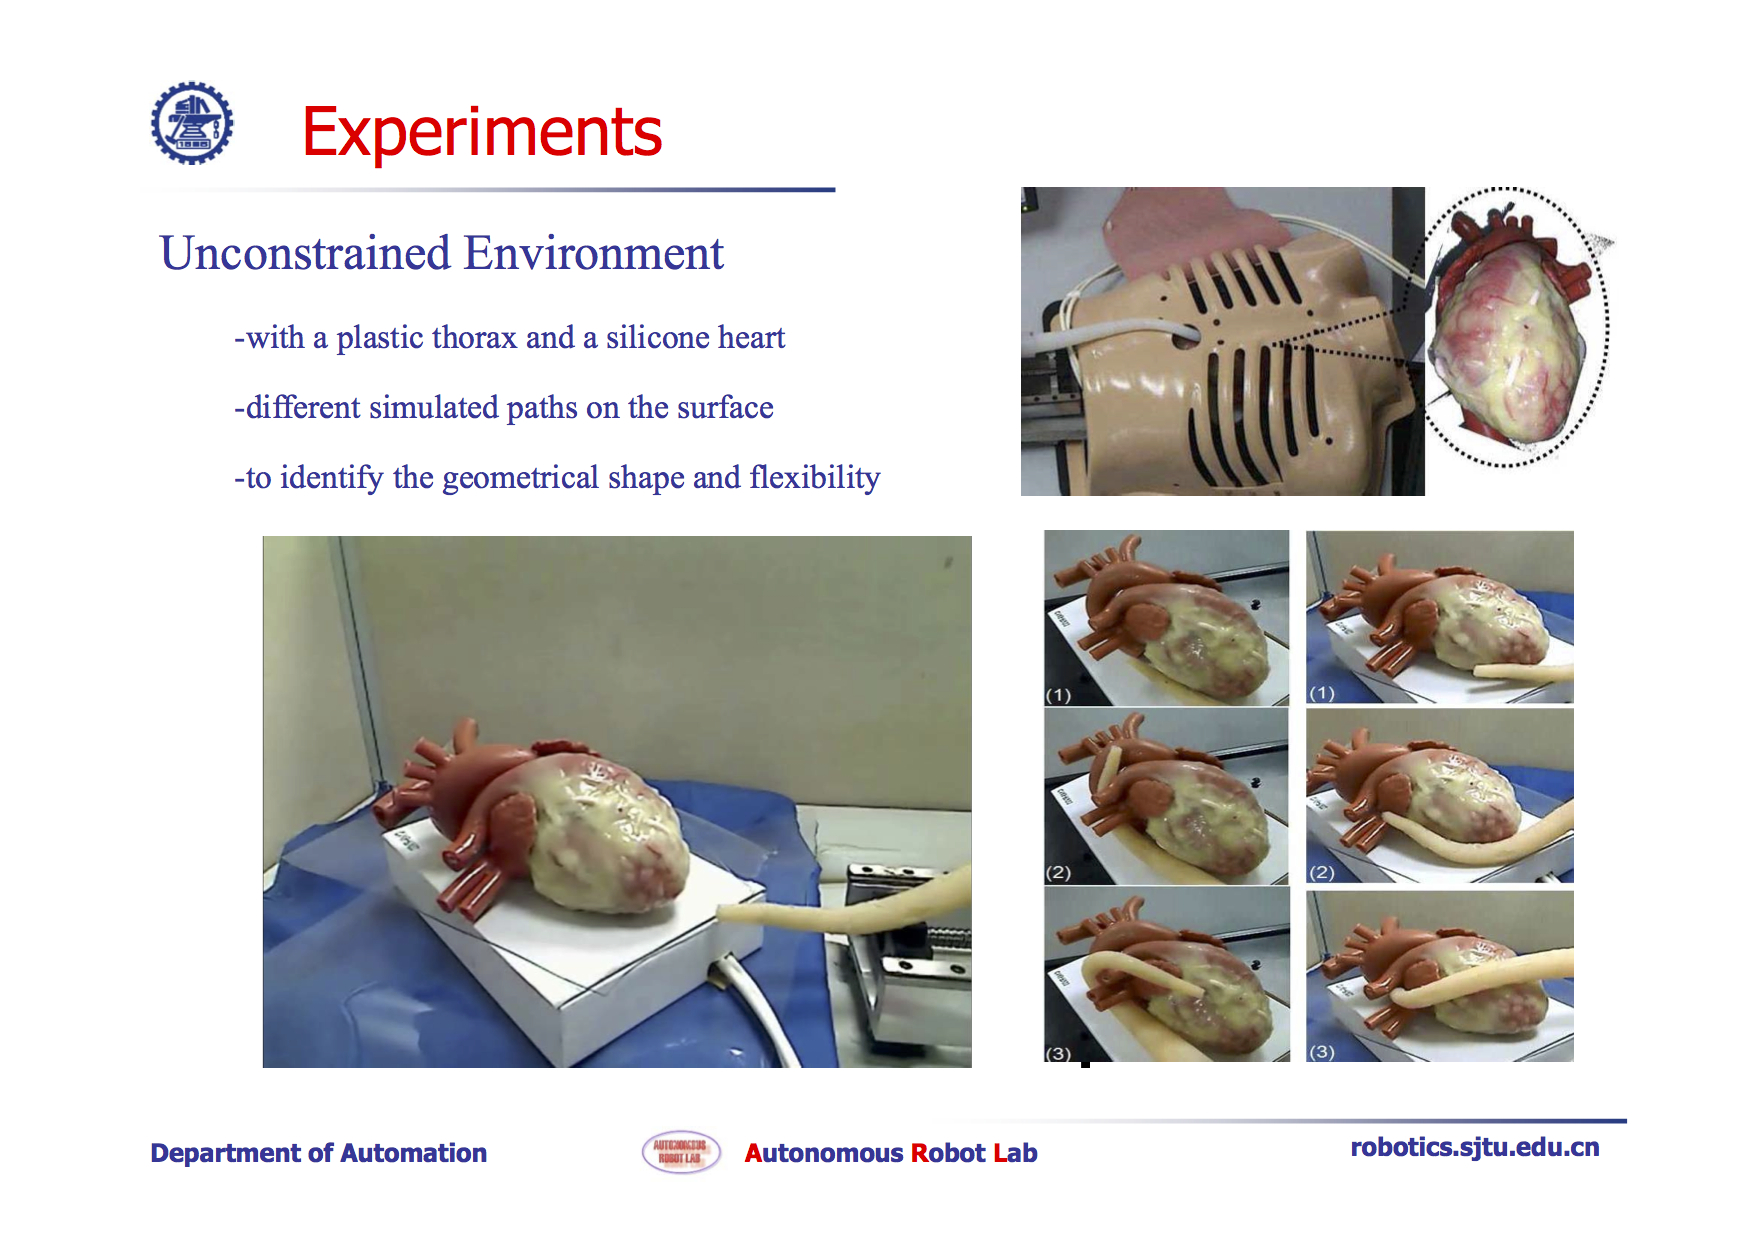
In previous talks we explored issues of designing soft robot arm. In this talk Prof. Wang from the Autonomous Robot Lab at the Shanghai Jiao Tong University shows how to control them:
You may notice that the approach is fairly classic, and that we are still lacking the models to do it from a morphological computation and self-organization standpoint – although I and some of the other ShanghAI lecturers have some ideas about how to do this.
About the ShanghAI Lectures
While in the classical approach “intelligence” was essentially viewed as information processing taking place in the brain, the more recent insight that interaction with the environment is of central importance is gaining acceptance. This has led to the metaphor of embodiment, i.e., that intelligence is always a property of an entire organism — an idea that has far-reaching implications and often leads to surprising insights, but which has not so far been widely exploited in industry practice.
The ShanghAI Lectures project aims to:
- Build a sustainable community of students and researchers in the area of Embodied Intelligence
- Make education and knowledge on cutting-edge scientific topics accessible to everyone
- Explore novel methods of knowledge transfer
- Overcome the complexity of a multi-cultural and interdisciplinary learning context
- Bring global teaching to a new level
These lectures about Natural and Artificial Intelligence have been held via videoconference at the University Carlos III of Madrid in Spain, the University of Zurich in Switzerland, Scuola Superiore Sant’Anna of Pisa, Italy, Humboldt University Berlin in Germany, University of Plymouth and University of Salford in the UK, and 10 other universities around the globe. Students from the participating universities are still working together on the exercises, using Webots by Cyberbotics, and Ludobots by the University of Vermont.
The lectures have also been streamed to allow remote participation to anybody.
The ShanghAI Lectures differ from ‘conventional’ MOOCs as they exploit telecommunication technology to build a global, distributed lecture hall that allows rich interaction rather than simply implementing the good old fashioned TV broadcasting model on a different medium. They also differ from other AI courses as they propose a new paradigm approach to embodied cognition (a.k.a. AI and Robotics). It is a kind of Copernican revolution with respect to GOFAI and its robotics application — and thus a research program for the coming decades.
This year I coordinated the lectures, with help from Prof. Rolf Pfeifer and Dr. Nathan Labhart at the University of Zurich . Rolf Pfeifer and I provided the context (introduction, moderation, and conclusion). As always, there were 2-3 invited guest lectures each week.
tags: embodied intelligence, Fabio Bonsignorio, Josh Bongard, lectures & seminars, ShanghAI Lectures, ShanghAI Lectures 2013
AUAI is supported by:










