Robohub.org
 

The Year of CoCoRo Video #40/52: Adaptive layers water column

by
06 October 2015


share this:
Cocoro40

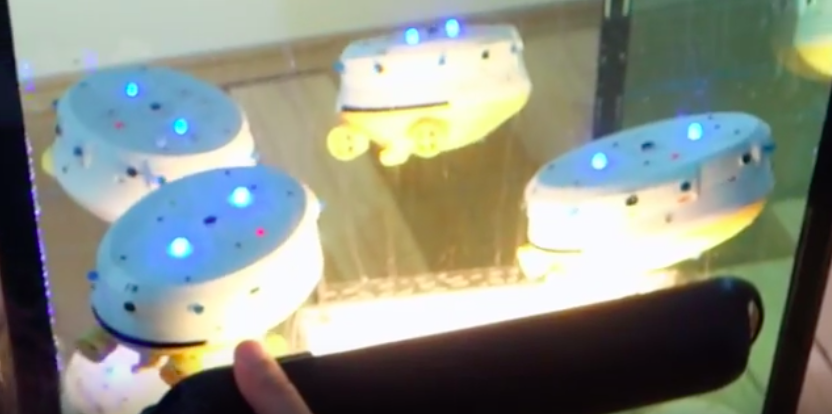
The EU-funded Collective Cognitive Robotics (CoCoRo) project has built a swarm of 41 autonomous underwater vehicles (AVs) that show collective cognition. Throughout 2015 – The Year of CooRo – we’ll be uploading a new weekly video detailing the latest stage in its development. This week’s video shows the mechanisms used in the “social inhibition algorithm” in more detail and our experiments with swarms of robots in a vertical aquarium. 

Last week we introduced the “social inhibition algorithm” we developed for our CoCoRo robot swarm. This is an algorithm for regulating division of labour, inspired by the self-organized regulation of physiological age in honeybee colonies.

The week the robots regulate an internal variable, X, by interacting with other robots, and split the swarm into three cohorts, allocating themselves to different depths in the aquarium. We added and removed robots. Their regulation of the internal variable leads to an automatic rearrangement of the swarm, so that there are always an equal number of robots at each depth.

We also added sources of interest: special robots or external lights, at different depth layers, and the swarm rearranges in a way that more robots are attracted to particularly interesting depths.

The algorithm shown here is promising due to its ability to automatically rearrange the robots to meet different demands, based only on local interactions. This makes it attractive for large scale applications where several sub-groups of the swarm need to act at different depth levels performing different tasks.


tags: , , , , ,


Thomas Schmickl is an Associate Professor at Karl-Franzens University, Graz, Austria, and a lecturer at the University for Applied Sciences in St. Pölten, Austria.

            AUAI is supported by:


Subscribe to Robohub newsletter on substack


Related posts :

Robot Talk Episode 167 – Automating construction, with Jan Petrš

  23 Oct 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Jan Petrš from École Polytechnique Fédérale de Lausanne about novel robot designs for construction and architecture.

ACM SIGAI Autonomous Agents Award 2027 open for nominations

  20 Oct 2026
Nominations are solicited for the 2027 ACM SIGAI Autonomous Agents Research Award.

Powered by muscle cells, a paper-thin robot swims through watery maze

  19 Oct 2026
MIT engineers’ new aquabot offers a way to design small, efficient “biohybrid” robots.

Robot Talk Episode 166 – Evolving robot bodies and brains, with Rika Antonova

  16 Oct 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Rika Antonova from the University of Cambridge about using artificial intelligence to develop complimentary robot hardware and algorithms.

Humanoid robots can sprint and box – but the real test is doing the laundry

  12 Oct 2026
No robot system can yet reliably handle the whole laundry process. Even folding remains a challenge.

Robot Talk Episode 165 – Robots behind the research, with Kushant Patel

  09 Oct 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Kushant Patel from Brookhaven National Laboratory about robots that work in scientific facilities, such as particle accelerators.

What three days building a robot taught me

and   07 Oct 2026
The brief sounded simple: build a small autonomous robot, then make it survive increasingly difficult mazes. Simple... right? Until you actually have to build one.


↑


AUAI is supported by:


Subscribe to Robohub newsletter on substack


©2026.05 - Association for the Understanding of Artificial Intelligence