Robohub.org
 

Grasping with robots – which object is in reach?


by
17 August 2014


share this:

This post is part of our ongoing efforts to make the latest papers in robotics accessible to a general audience.

Imagine a robot reaching for a mug on the table, only to realize that it is too far, or that it would need to bend its arm joint backwards to get there. Understanding which objects are within reach and how to grasp them is an essential requirement if robots are to operate in our everyday environments. To solve this problem, a recent Autonomous Robots paper by Vahrenkamp et al. proposes a new approach to build a comprehensive representation of the capabilities of a robot related to reaching and grasping.

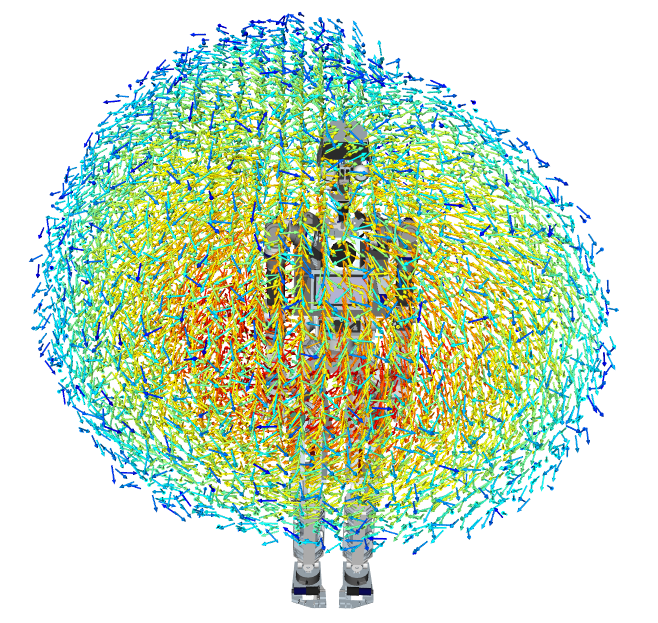
The “manipulability” representation shown below allows the robot to know where it can reach in 6D with its right arm. That means it knows which x,y,z positions it can reach, as well as the orientation of the robot hand that is best for manipulation. The representation takes into account constraints due to joints in the arm. The manipulability is encoded by color (blue: low, red: high).
armar4_rightarm6

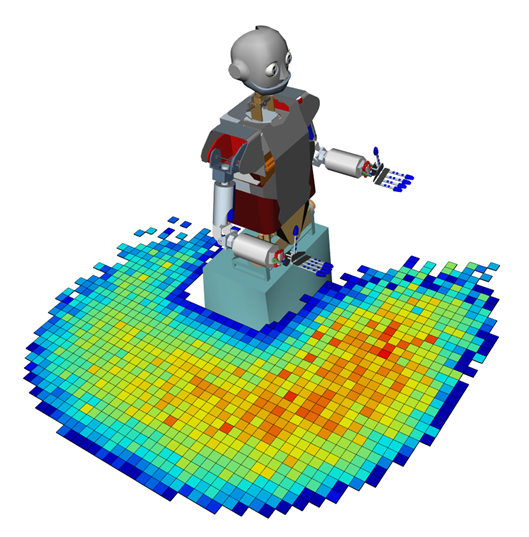
A cut through one of these vector clouds looks like this.
manip_armar2

In addition to single handed grasping, the authors discuss how the approach can be extended to grasping with two arms. Experiments were run in simulation on the humanoid robots ARMAR-III and ARMAR-IV.

And in case you want to try this at home, there is an open source version of this work here.

For more information, you can read the paper Representing the robot’s workspace through constrained manipulability analysis (Nikolaus Vahrenkamp and Tamim Asfour, Autonomous Robots – Springer US, July 2014) or ask questions below!


tags:


Autonomous Robots Blog Latest publications in the journal Autonomous Robots (Springer).

            AUAI is supported by:


Subscribe to Robohub newsletter on substack


Related posts :

Robot Talk Episode 171 – Programming robot behaviour, with Sebastian Castro

  20 Nov 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Sebastian Castro about developing open-source software for robot task planning and behaviour.

Soft exosuit makes it easier to stand up

Robotic system helps users stand up and walk more efficiently.

Robot swarms trained by trial and error in simulation keep working on real robots

  17 Nov 2026
Researchers have developed a new approach to reinforcement learning that helps robot swarms, allowing behaviours learned in simulation to transfer reliably to real-world robots.

Watch the IROS 2026 plenary and keynote talks

  16 Nov 2026
Catch up on the invited presentations from the International Conference on Intelligent Robots and Systems.

Robot Talk Episode 170 – Robots in the real world, with Daniela Shchegelskaya

  13 Nov 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Daniela Shchegelskaya from the University of Twente about getting robots to operate reliably in safety-critical environments.

AI100 report released: embodied AI highlighted as grand challenge

  11 Nov 2026
Embodied AI is listed as one of the most inspiring open grand challenges.

AIhub coffee corner: Are humanoids the future of embodied AI?

  09 Nov 2026
The AIhub coffee corner captures the musings of AI experts over a short conversation.

Robot Talk Episode 169 – Robot sensing inspired by nature, with Dexter Shepherd

  06 Nov 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Dexter Shepherd from the University of Sussex about using artificial intelligence to help robots understand and adapt to their environment.


↑


AUAI is supported by:


Subscribe to Robohub newsletter on substack


©2026.05 - Association for the Understanding of Artificial Intelligence