
Robohub.org
The Year of CoCoRo Video #39/52: Adaptive layers in a pool
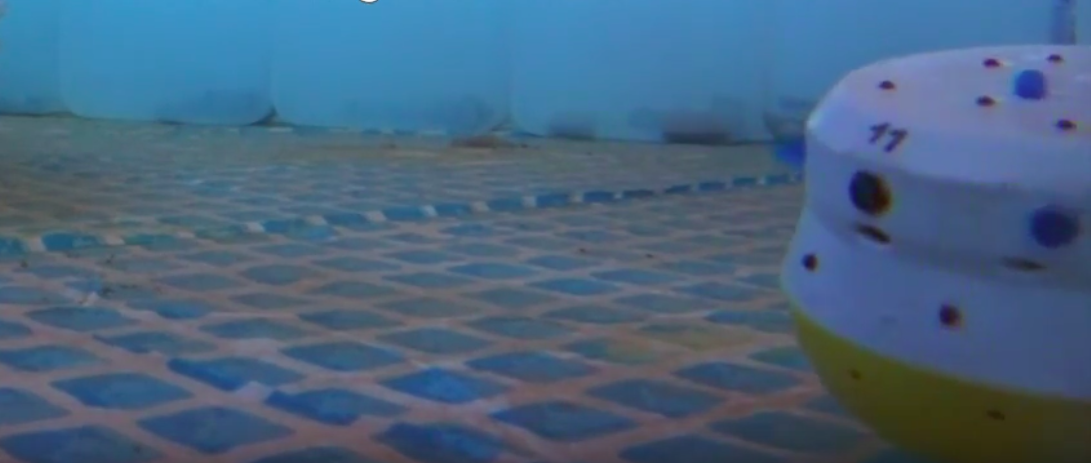
The EU-funded Collective Cognitive Robotics (CoCoRo) project has built a swarm of 41 autonomous underwater vehicles (AVs) that show collective cognition. Throughout 2015 – The Year of CooRo – we’ll be uploading a new weekly video detailing the latest stage in its development. This week’s video shows the “social inhibition algorithm.” Inspired by honeybees, it’s a mechanism to regulate division of labour by socially inhibiting physiological age progression.
The more older bees there are, the slower younger bees will progress in their age-dependant work schedule. The more often the younger bees meet the older ones, the faster these older bees will progress, thus they will age faster physiologically. In this way the physiological age is self-regulated in the honeybee colony and ultimately also the division of labour.
We implemented these mechanisms into our robot swarm. Each robot holds a variable, X, representing its “physiological age.” If two robots meet, these values can change a bit, depending on their past experiences. Over time all robots will have quite different values of X. The work to be performed or, in this case, the depth to which the robot dives, is based on the value of its X.
If robots are removed or added at specific depths, the contact rates of some will change and, in turn, their X values, ultimately re-arranging the whole swarm in a homeostatic way. By casting lights at some robots we increased the “work load demand” at a particular depth layer and automatically more robots were recruited to that layer. The video shows our first experiments with this algorithm in a pool, with the robots at two different depths: near the surface and close to the ground.
tags: AUV, c-Research-Innovation, CoCoRo, EU robotics industry news, UAV, underwater video
AUAI is supported by:









