Robohub.org
 

The Year of CoCoRo Video #39/52: Adaptive layers in a pool

by
29 September 2015


share this:
cocoro39b

The EU-funded Collective Cognitive Robotics (CoCoRo) project has built a swarm of 41 autonomous underwater vehicles (AVs) that show collective cognition. Throughout 2015 – The Year of CooRo – we’ll be uploading a new weekly video detailing the latest stage in its development. This week’s video shows the “social inhibition algorithm.” Inspired by honeybees, it’s a mechanism to regulate division of labour by socially inhibiting physiological age progression.

The more older bees there are, the slower younger bees will progress in their age-dependant work schedule. The more often the younger bees meet the older ones, the faster these older bees will progress, thus they will age faster physiologically. In this way the physiological age is self-regulated in the honeybee colony and ultimately also the division of labour.

We implemented these mechanisms into our robot swarm. Each robot holds a variable, X, representing its “physiological age.” If two robots meet, these values can change a bit, depending on their past experiences. Over time all robots will have quite different values of X. The work to be performed or, in this case, the depth to which the robot dives, is based on the value of its X.

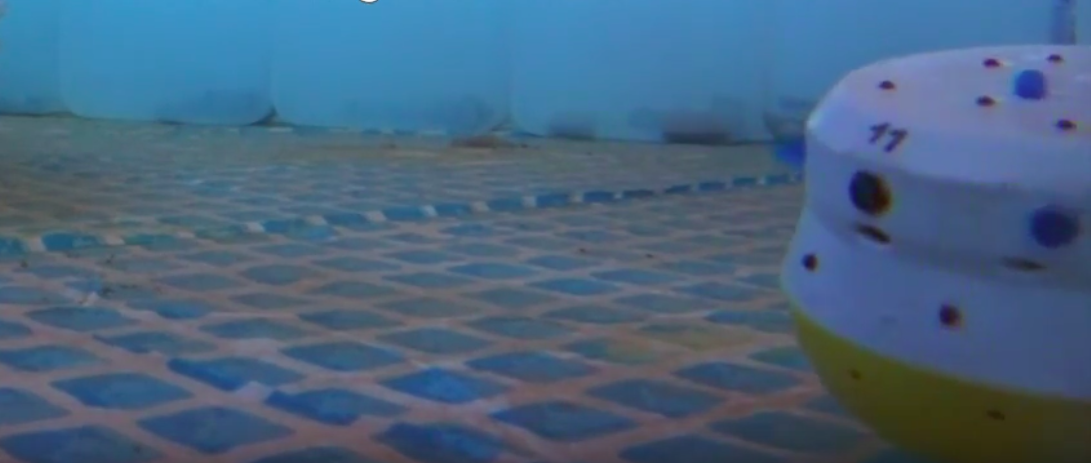
If robots are removed or added at specific depths, the contact rates of some will change and, in turn, their X values, ultimately re-arranging the whole swarm in a homeostatic way. By casting lights at some robots we increased the “work load demand” at a particular depth layer and automatically more robots were recruited to that layer. The video shows our first experiments with this algorithm in a pool, with the robots at two different depths: near the surface and close to the ground.


tags: , , , , ,


Thomas Schmickl is an Associate Professor at Karl-Franzens University, Graz, Austria, and a lecturer at the University for Applied Sciences in St. Pölten, Austria.

            AUAI is supported by:


Subscribe to Robohub newsletter on substack


Related posts :

Robot Talk Episode 164 – Accelerating robot learning, with Michelle Lu

  02 Oct 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Michelle Lu from Vsim Technology about using simulation and artificial intelligence to teach robots new skills.

Robotics and automation? Informal reflections on familiar terms

IEEE experts reflect on what is meant by the term "robotics and automation".

Small, medium or large, a robotic fish maintains its swimming ability

  28 Sep 2026
Researchers at EPFL and New York University have developed a robotic fish that can be made in various sizes for studying shallow creeks to open water.

Robot Talk Episode 163 – Robots helping people, with Aaron Edsinger

  25 Sep 2026
In the first episode of Robot Talk season 7, Claire chatted to Aaron Edsinger from Hello Robot about their Stretch robots that can help people with mobility issues live more independently.

An open source approach to physical AI from Intrinsic

  25 Sep 2026
Find out more about the capabilities of Intrinsic Core.

What’s coming up at #IROS2026?

  24 Sep 2026
Find out what the International Conference on Intelligent Robots and Systems has in store.

Robotics roadmaps from around the world spotlight of the month: China

China is targeting the next industrial revolution by doubling down on embodied AI and humanoid robotics, building directly on its vast manufacturing infrastructure.

Mars rovers give scientists a ground-level view of the red planet – peek inside their NASA control room

  21 Sep 2026
NASA created Curiosity to search for evidence of ancient habitable environments.


↑


AUAI is supported by:


Subscribe to Robohub newsletter on substack


©2026.05 - Association for the Understanding of Artificial Intelligence