Robohub.org
 

Disney’s one-legged untethered hopping robot

by
12 October 2016


share this:
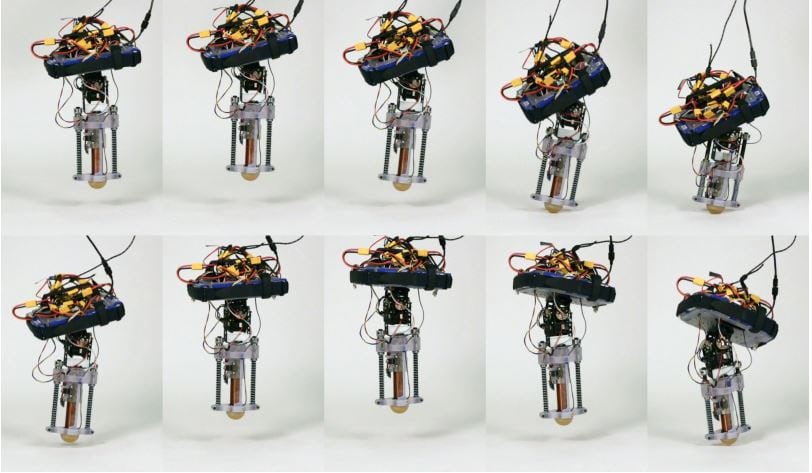
The Disney hopping robot in action (Credit: Disney Research)

The Disney hopping robot in action (Credit: Disney Research)

Disney Research presents their design and control for an untethered, energetically autonomous single-legged hopping robot. While this isn’t the first hopping robot to be built, it is the first not to rely on a tether or external power source for its hopping.

From their website:

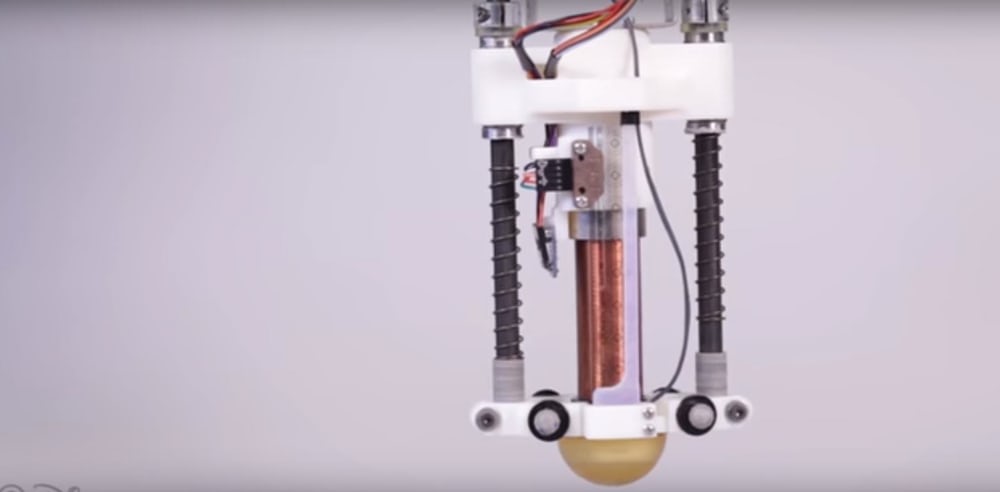
“The thrust-producing mechanism of the robot’s leg is an actuated prismatic joint, called a linear elastic actuator in parallel (LEAP). The LEAP mechanism comprises of a voice-coil actuator in parallel with two compression springs, which gives our robot passive compliance. An actuated gimbal hip joint is realized by two standard servomotors.”
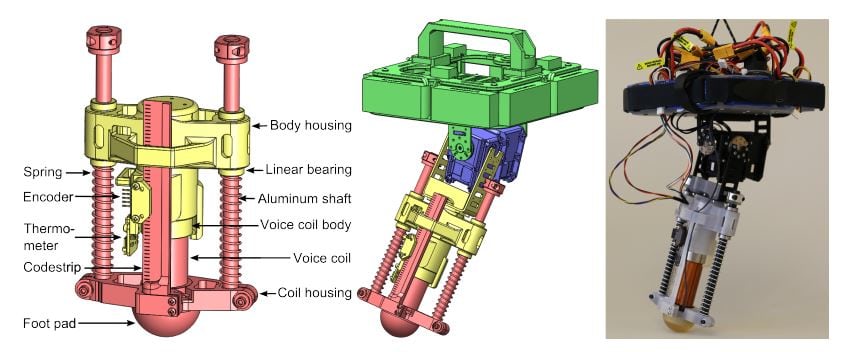
Diagram of the Disney hopping robot (Credit: Disney Research)

Diagram of the Disney hopping robot (Credit: Disney Research)

The researchers adapted a Raibert’s hopping controller to control the robot and found it could maintain balance in place for up to 7 seconds, or 19 hops, while continuously hopping.

Here are a few more pictures of the hopping robot:
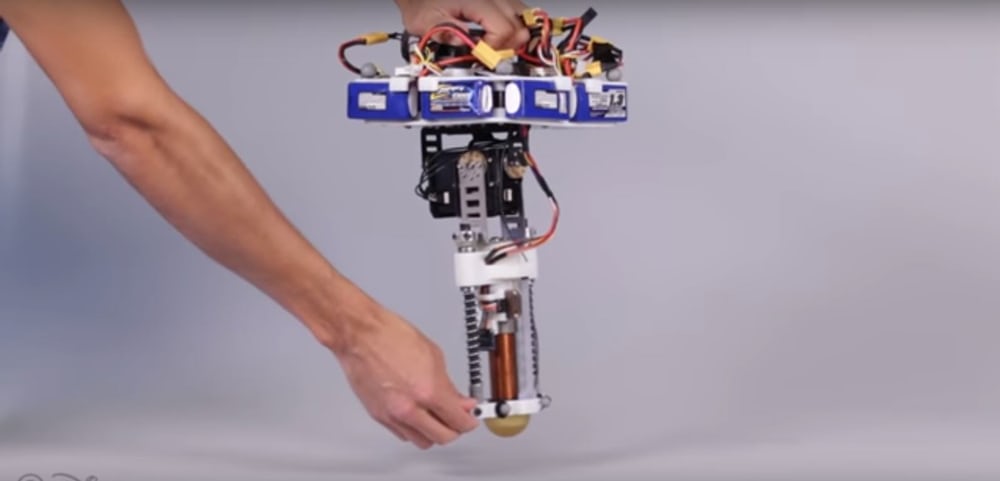
The Disney hopping robot is the first built since 2007 (Credit: Disney Research)
The Disney hopping robot is the first built since 2007 (Credit: Disney Research)

Robot's leg (Credit: Disney Research)

Robot’s leg (Credit: Disney Research)
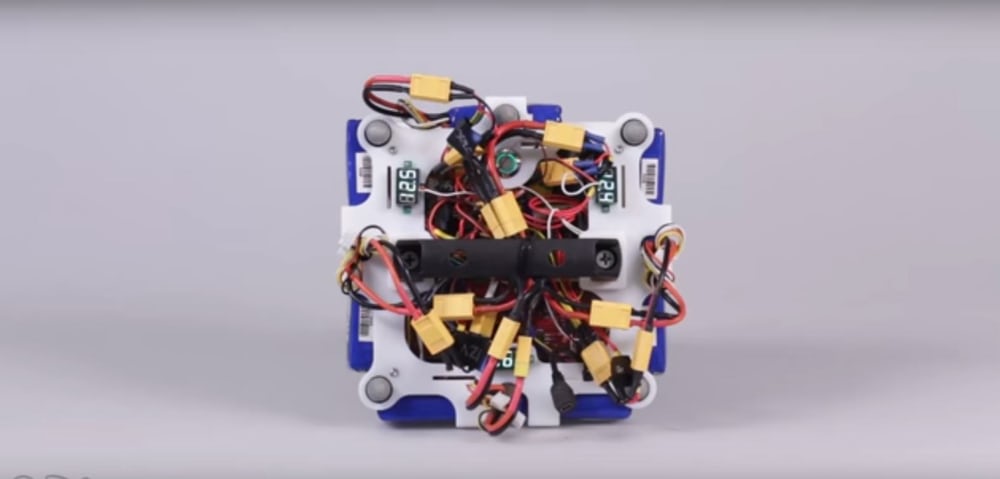
Robot's control unit (Credit: Disney Research)

Robot’s control unit (Credit: Disney Research)

Download the paper here or visit the Disney Research website.


If you liked this article, you may also want to read:

See all the latest robotics news on Robohub, or sign up for our weekly newsletter.


tags:


Robohub Editors

            AUAI is supported by:


Subscribe to Robohub newsletter on substack


Related posts :

Robot swarms trained by trial and error in simulation keep working on real robots

  17 Nov 2026
Researchers have developed a new approach to reinforcement learning that helps robot swarms, allowing behaviours learned in simulation to transfer reliably to real-world robots.

Watch the IROS 2026 plenary and keynote talks

  16 Nov 2026
Catch up on the invited presentations from the International Conference on Intelligent Robots and Systems.

Robot Talk Episode 170 – Robots in the real world, with Daniela Shchegelskaya

  13 Nov 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Daniela Shchegelskaya from the University of Twente about getting robots to operate reliably in safety-critical environments.

AI100 report released: embodied AI highlighted as grand challenge

  11 Nov 2026
Embodied AI is listed as one of the most inspiring open grand challenges.

AIhub coffee corner: Are humanoids the future of embodied AI?

  09 Nov 2026
The AIhub coffee corner captures the musings of AI experts over a short conversation.

Robot Talk Episode 169 – Robot sensing inspired by nature, with Dexter Shepherd

  06 Nov 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Dexter Shepherd from the University of Sussex about using artificial intelligence to help robots understand and adapt to their environment.

Robots in society, business and culture: October 2026

We showcase a selection of robotics stories from society, business, research and culture.

Muscle coordination can be mimicked by electric motors – it could lead to improved robots

  02 Nov 2026
Researchers built a physical model using ordinary electric motors to try and simulate how muscles may perform tasks.


↑


AUAI is supported by:


Subscribe to Robohub newsletter on substack


©2026.05 - Association for the Understanding of Artificial Intelligence