
Robohub.org
Interview with Hae-Won Park, Seungwoo Hong and Yong Um about MARVEL, a robot that can climb on various inclined steel surfaces
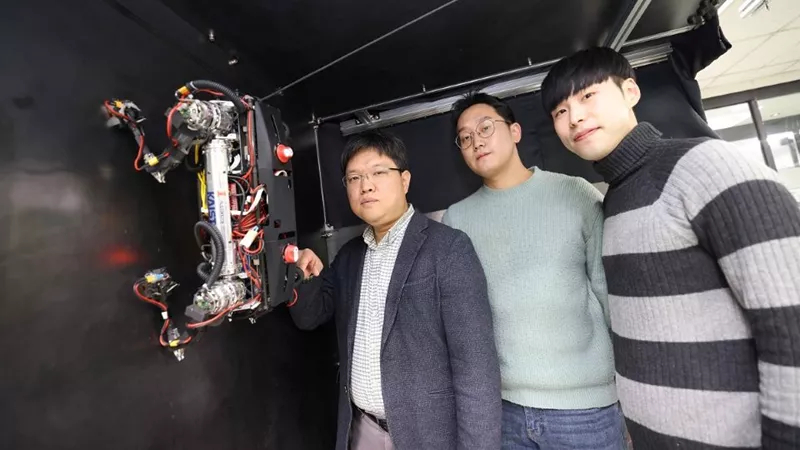
Prof. Hae-Won Park (left), Ph.D. Student Yong Um (centre), Ph.D. Student Seungwoo Hong (right). Credits: KAIST
We had the chance to interview Hae-Won Park, Seungwoo Hong and Yong Um, authors of the paper “Agile and versatile climbing on ferromagnetic surfaces with a quadrupedal robot”, recently published in Science Robotics.
What is the topic of the research in your paper?
The main topic of our work is that the robot we have developed can move agilely, not only on flat ground but also on vertical walls and ceilings made of ferromagnetic materials. Also, it has the ability to perform dexterous maneuvers such as crossing gaps, overcoming obstacles, and transitioning upon corners.
Could you tell us about the implications of your research and why it is an interesting area for study?
Such agile and dexterous locomotion capabilities will be able to expand the robot’s operational workspace and approach places that are difficult or dangerous for human operators to access directly. For example, inspection and welding operations in heavy industries such as shipbuilding, steel bridges, and storage tanks.
Could you explain your methodology? What were your main findings?
Our magnet foot can switch the on/off state in a short period of time (5 ms) and in an energy-efficient way, thanks to the novel geometry design of EPM. At the same time, the magnet foot can provide large holding forces in both shear and normal directions due to the MRE footpad. Also, our actuators can provide balanced speed/torque characteristics, high-bandwidth torque control capability, and the ability to mediate high impulsive force. To control vertical and inverted locomotion as well as various versatile motions, we have utilized a control framework (model predictive control) that can generate reliable and robust reaction forces to track desired body motions in 3D space while preventing slippage or tipping-over occurs. We found that all the elements mentioned earlier are imperative to perform dynamic maneuvers against gravity.
What further work are you planning in this area?
So far, the robot is able to move on smooth surfaces with moderate curvature. To enable the robot to move on irregularly shaped surfaces, we are working on designing a compliantly-integrated multiple miniaturized EPMs with MRE footpads that can increase the effective contact area to provide robust adhesion. Also, a vision system with high-level navigation algorithms will be included to enable the robot to move autonomously in the near future.
About the authors
|
Hae-Won Park received the B.S. and M.S. degrees from Yonsei University, Seoul, South Korea, in 2005 and 2007, respectively, and the Ph.D. degree from the University of Michigan, Ann Arbor, MI, USA, in 2012, all in mechanical engineering. He is an Associate Professor of mechanical engineering with the Korea Advanced Institute of Science and Technology, Daejeon, South Korea. His research interests include the intersection of control, dynamics, and mechanical design of robotic systems, with special emphasis on legged locomotion robots. Dr. Park is the recipient of the 2018 National Science Foundation (NSF) CAREER Award and NSF most prestigious awards in support of early-career faculty. |
|
Seungwoo Hong received the B.S. degree from Shanghai Jiao Tong University, Shanghai, China, in July 2014, and the M.S. degree from Korea Advanced Institute of Science and Technology (KAIST), Daejeon, Korea, in August 2017, all in mechanical engineering. He is currently a Ph.D. candidate with the Department of Mechanical Engineering, KAIST, Daejeon, Korea. His current research interests include model-based optimization, motion planning and control of legged robotic systems. |
|
Yong Um received the B.S. degree in mechanical engineering from the Korea Advanced Institute of Science and Technology, Daejeon, South Korea, in 2020. He is currently working toward the Ph.D. degree in mechanical engineering in Korea Advanced Institute of Science and Technology. His research interests include mechanical system and magnetic device design for legged robot. |
tags: research
AUAI is supported by:









