
Robohub.org
Robocars at CES: Supervised traffic jam assist
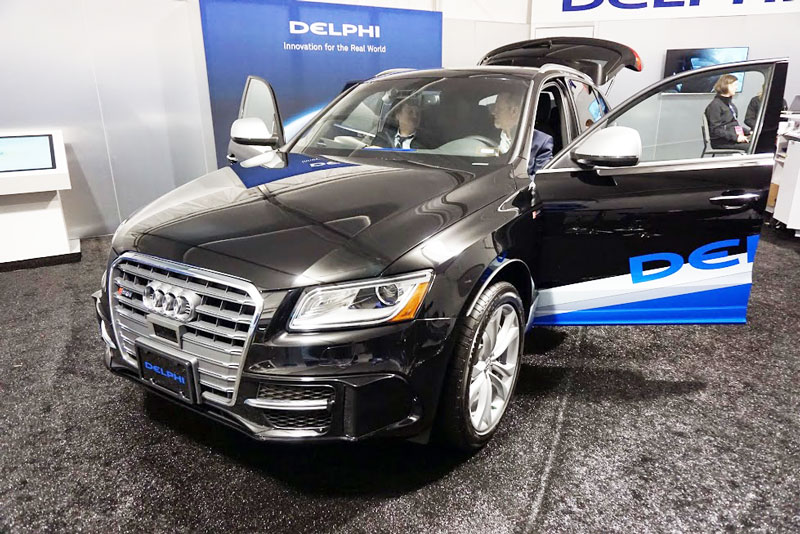
Delphi’s car bristling with sensors — 6 LIDARS and even more radars. Photo credit: Brad Templeton.
After a short day looking at robocars at CES, a more full day was full of the usual equipment — cameras, TVs, audio and the like and visits to several car booths.
I’ve expanded my gallery of notable things with captions with cars and other technology.
Lots of people were making demonstrations of traffic jam assist at CES — simple self-driving at low speeds among other cars. All the demos were of a supervised traffic jam assist. This style of product (as well as supervised highway cruising) is the first thing that car companies are delivering (though they are also delivering various parking assist and valet parking systems).
This makes sense as it’s an easy problem to solve. So easy, in fact, that many of them now admit they are working on making a real traffic jam assist, which will drive the jam for you while you do e-mail or read a book. This is a readily solvable problem today — you really just have to follow the other cars, and you are going slow enough that, short of a catastrophic error like going full throttle, you aren’t going to hurt people no matter what you do … at least on a highway where there are no pedestrians or cyclists. As such, a full auto traffic jam assist should be the first product we see form car companies.
None of them will say when they might do this. The barrier is not so much technological as corporate — concern about liability and image. It’s a shame, because frankly the supervised cruise and traffic jam assist products are just in the “pleasant extra feature” category. They may help you relax a bit (if you trust them) as cruise control does, but they give you little else. A “read a book” level system would give people back time, and signal the true dawn of robocars. It would probably sell for lots more money, too.
The most impressive car is Delphi’s, a collaboration with folks out of CMU. The Delphi car, a modified Audi SUV, has no fewer than 6 4-plane LIDARs and an even larger number of radars. It helps if you make the radars, as otherwise this is an expensive bill of materials. With all the radars, the vehicle can look left and right, and back left and back right, as well as forward, which is what you need for dealing with intersections where cross traffic doesn’t stop, and for changing lanes at high speed.
As a refresher: Radar gives you great information, including speed on moving objects, and sucks on stationary ones. It goes very far and sees through all weather. It has terrible resolution. LIDAR has more resolution but does not see as far, and does not directly give you speed. Together they do great stuff.
For notes and photos, browse the gallery.
A version of this article originally appeared on robocars.com.
tags: automotive, CES 2015, events

AUAI is supported by:










