Robohub.org
ep.

089

podcast
 

Demonstrations at IROS with Péter Fankhauser and Mike Rubenstein


by
21 October 2011


share this:

In today’s show, we hear about two demonstrations that caught our attention at the IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS). Péter Fankhauser from the ETHZ in Zurich tells us about the Rezero ballbot, a balancing robot that speeds around on a sphere. Mike Rubenstein from the Self-organizing Systems Research Group at Harvard then tells us about their efforts to make swarms of 1024 robots a reality with the kilobot project.

Péter Fankhauser
© Karl Hug Ringier AG

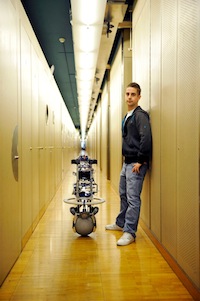
Péter Fankhauser is the leader of the Rezero ballbot project. The Rezero project was one of last year’s “Focus Projects” during which Bachelor students in Mechanical Engineering at ETHZ have the opportunity to develop a product from scratch. The project was supervised by Prof. Siegwart from the Autonomous Systems Laboratory. Rezero brought together eight future mechanical engineers, two electrical engineers studying at the ZHAW as well as Industrial Designers from ZHdK.

The interdisciplinary team developed the ballbot, a robot that balances and drives around on a ball. Using a single ball instead of wheels allows the robot to move spontaneously in any direction, fit into tight spaces, and achieve high speeds. The robot was often seen zipping through the hallways at IROS earlier this month.

Fankhauser tells us about his learning experience, challenges in working in large crossdisciplinary teams, the secret behind the ballbot capabilities and the future steps in making the ballbot a commercial reailty.


Mike Rubenstein
Mike Rubenstein is a postdoctoral researcher from the Self-organizing Systems Research Group at Harvard. In an effort to make large swarms of robots a reality, he’s been building 1024 coin-sized robots dubbed kilobots. Challenges include making the robots low-cost and easy to assemble, recharge, reprogram and control. The final system is made with only $14 worth of parts, takes 5 minutes to assemble and can be operated in less than a minute. The open source release of all the electronics and assembly documents is expected near the end of this year.

After bording a plane with 100+ robots, Rubenstein was able to demonstrate the system at IROS.

In the future, Rubenstein hopes to implement his thesis work on “Self-assembly and self-healing for robotic collectives” on the kilobots. An example of such a system is show in the video below.


Links:


tags: ,


Podcast team The ROBOTS Podcast brings you the latest news and views in robotics through its bi-weekly interviews with leaders in the field.

            AUAI is supported by:


Subscribe to Robohub newsletter on substack


Related posts :

Robot Talk Episode 171 – Programming robot behaviour, with Sebastian Castro

  20 Nov 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Sebastian Castro about developing open-source software for robot task planning and behaviour.

Soft exosuit makes it easier to stand up

Robotic system helps users stand up and walk more efficiently.

Robot swarms trained by trial and error in simulation keep working on real robots

  17 Nov 2026
Researchers have developed a new approach to reinforcement learning that helps robot swarms, allowing behaviours learned in simulation to transfer reliably to real-world robots.

Watch the IROS 2026 plenary and keynote talks

  16 Nov 2026
Catch up on the invited presentations from the International Conference on Intelligent Robots and Systems.

Robot Talk Episode 170 – Robots in the real world, with Daniela Shchegelskaya

  13 Nov 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Daniela Shchegelskaya from the University of Twente about getting robots to operate reliably in safety-critical environments.

AI100 report released: embodied AI highlighted as grand challenge

  11 Nov 2026
Embodied AI is listed as one of the most inspiring open grand challenges.

AIhub coffee corner: Are humanoids the future of embodied AI?

  09 Nov 2026
The AIhub coffee corner captures the musings of AI experts over a short conversation.

Robot Talk Episode 169 – Robot sensing inspired by nature, with Dexter Shepherd

  06 Nov 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Dexter Shepherd from the University of Sussex about using artificial intelligence to help robots understand and adapt to their environment.


↑


AUAI is supported by:


Subscribe to Robohub newsletter on substack


©2026.05 - Association for the Understanding of Artificial Intelligence