
Robohub.org
Safety concerns for collaborative robots
At a daylong workshop on Collaborative Robots by the Robotic Industries Association (RIA), two main themes were expressed: worker safety and almost universal expectation for rapid deployment of collaborative robots.
Yaskawa Motoman’s USA Technology Director Erik Nieves proved that collaborative robotics are more complex than one would imagine as he described the need for and methods of providing safe working environments when robots and humans come close to one another. He coined a new term: “BC” referring to Before Collaboration, and used that term to describe present-day safety methods prescribed by international safety regulations – in this case ISO 10218. These are the regulations that advocate fencing, other physical barriers and the big red stop button. The regulations also mandate formal risk assessment, a complex and time consuming process.
Nieves described the four modes prescribed by the safety regulations for human-robot collaboration:
- Stopped state monitoring – the robot just stops when a human enters a scanned area but continues to monitor until the human leaves, at which time it resumes working
- Speed and separation monitoring – slows down when a human comes near and may stop if the human gets too close
- Hand guiding – the user is in direct contact with the robot while he is guiding and training it
- Power and force limiting – safety is achieved through restricting the amount of force available in the system either through electrical means or mechanical compliance such as the use of elastic actuators
The third and fourth mode is the one that current providers of collaborative robots are using to go cage-less. It is also the reason why they have a maximum payload of 22 pounds and that their speed does even come close to workhorse caged robots. Bigger and faster wouldn’t be possible with present day safety standards.
Esben Østergaard, CTO and founder of Universal Robots, a Danish company, somewhat debunked the need for such extreme safety precautions with the newer collaborative robots such as Universal Robots’ and those from Rethink Robotics. He suggested that if the regulations are too stringent, their very cumbersome and paper-bound requirements will preclude the deployment of the co-robots, particularly in small and medium-sized enterprises, which are their main marketplace and the area that can benefit most from these plug-and-play and easy to program robots.
Rodney Brooks, CTO, Chairman and founder of Rethink Robotics, the maker of the Baxter robot, suggested that collaborative robotics were on the cusp of massive change and explained how co-bots are a necessary tool for SMEs around the world. Brooks, over the years since he started Heartland Robotics (later renamed Rethink Robotics), has been defining the market (SMEs) and describing the applications and products (Baxter) that can service those SMEs, namely collaborative robots.
Brooks’ on-target and clear descriptions have educated the media and SME marketplace as they have made a strong case for the use of collaborative robotics. Universal Robots has been a significant beneficiary of Brooks’ efforts. Their growth has been phenomenal: they are now shipping over 150 robots per month, have 300 distributors worldwide, have more than 125 employees, and anticipate shipping 600 robots per month by 2017. Rethink’s growth has been less dramatic and their figures are not available for comparison.
Brooks also described the working thesis for Baxter robots – a thesis shared by many other robot makers and somewhat explaining why they are opening offices in Silicon Valley: to improve speed and precision without changing the hardware through the use of regularly improved software. Brooks said, “Software always does better in increasing usability and reducing costs than hardware.”
Other speakers at the RIA workshop described collaborative mobile robots and the unique issues they bring to the table, and spoke more on the new updated safety standards (ISO 15066), which will be released in early 2015. This new standard will better pinpoint the special concerns of co-bots and mobile bots.
Rich Mahoney, Director of Robotics at SRI, reminded us that component technologies are redefining collaborative robotics and will continue to do so in the years to come. He also made a plea for unified buses and software platforms so that the industry could grow faster.
Almost every speaker was an enthusiastic proponent of collaborative robots and predicted spectacular near-term growth as these safe, low-cost, high performance robots enhance their software, operating platforms and interoperability… and through software, sensors and regulations, respect and safeguard the boundaries of their human co-workers.
PS: On the same day as the workshop, RIA writer Tanya Anandan, posted an in-depth article entitled Major Robot OEMs Fast-tracking Co-bots that elaborates on the interest and momentum of collaborative robotics.
__________________
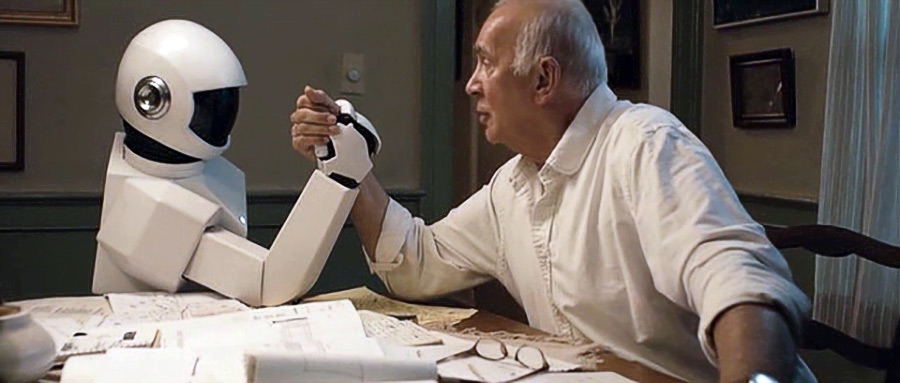
Image from movie “Robot and Frank,” a fictional futuristic glimpse of what an eldercare robot is likely to do and how it will interact with the person it is assigned to care for.
tags: co-robots, collaborative robots, events, human-robot interaction, ISO

AUAI is supported by:









