
Robohub.org
Sea creatures inspire marine robots which can operate in extra-terrestrial oceans
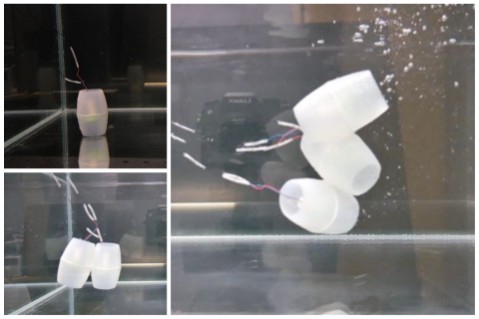
RoboSalps in action. Credits: Valentina Lo Gatto
These robotic units called RoboSalps, after their animal namesakes, have been engineered to operate in unknown and extreme environments such as extra-terrestrial oceans.
Although salps resemble jellyfish with their semi-transparent barrel-shaped bodies, they belong to the family of Tunicata and have a complex life cycle, changing between solitary and aggregate generations where they connect to form colonies.
RoboSalps have similarly light, tubular bodies and can link to each other to form ‘colonies’ which gives them new capabilities that can only be achieved because they work together.
Researcher Valentina Lo Gatto of Bristol’s Department of Aerospace Engineering is leading the study. She is also a student at the EPSRC Centre of Doctoral Training in Future Autonomous and Robotic Systems (FARSCOPE CDT).
She said: “RoboSalp is the first modular salp-inspired robot. Each module is made of a very light-weight soft tubular structure and a drone propeller which enables them to swim. These simple modules can be combined into ‘colonies’ that are much more robust and have the potential to carry out complex tasks. Because of their low weight and their robustness, they are ideal for extra-terrestrial underwater exploration missions, for example, in the subsurface ocean on the Jupiter moon Europa.”
RoboSalps are unique as each individual module can swim on its own. This is possible because of a small motor with rotor blades – typically used for drones – inserted into the soft tubular structure.
When swimming on their own, RoboSalps modules are difficult to control, but after joining them together to form colonies, they become more stable and show sophisticated movements.
In addition, by having multiple units joined together, scientists automatically obtain a redundant system, which makes it more robust against failure. If one module breaks, the whole colony can still move.
A colony of soft robots is a relatively novel concept with a wide range of interesting applications. RoboSalps are soft, potentially quite energy efficient, and robust due to inherent redundancy. This makes them ideal for autonomous missions where a direct and immediate human control might not be feasible.
Dr Helmut Hauser of Bristol’s Department of Engineering Maths, explained: “These include the exploration of remote submarine environments, sewage tunnels, and industrial cooling systems. Due to the low weight and softness of the RoboSalp modules, they are also ideal for extra-terrestrial missions. They can easily be stored in a reduced volume, ideal for reducing global space mission payloads.”
A compliant body also provides safer interaction with potentially delicate ecosystems, both on earth and extra-terrestrial, reducing the risk of environmental damage. The possibility to detach units or segments, and rearrange them, gives the system adaptability: once the target environment is reached, the colony could be deployed to start its exploration.
At a certain point, it could split into multiple segments, each exploring in a different direction, and afterwards reassemble in a new configuration to achieve a different objective such as manipulation or sample collection.
Prof Jonathan Rossiter added: “We are also developing control approaches that are able to exploit the compliance of the modules with the goal of achieving energy efficient movements close to those observed in biological salps.”
tags: bio-inspired
AUAI is supported by:










