
Robohub.org
ShanghAI Lectures 2013, Lecture 4 – Evolution: Cognition from scratch
This week we publish the fourth of the ShanghAI Lectures 2013 Edition on Robohub — we will release a new lecture from this series every Monday until the series is complete. Please use the comments section below to send us your questions, and we will do our best to respond! You can learn more about the ShanghAI lectures here.
Lecture 4 – Evolution: Cognition from scratch
If you believe that it’s too difficult to develop the mathematical models required to arrive at a new concept of embodied AI and robotics, this lecture will offer you hope. In her talk, Prof. Verena Hafner, from Humboldt University in Berlin, discusses the concept of ‘body maps’ from an embodied intelligence perspective, and shows how they can emerge from sensorimotor flow, through information distances in the data flow and/or an internal simulation. In this context the ‘body map’ is not a symbolic ‘representation’ of the agent’s body, but rather an emerging structure used by the agent in its interaction with its environment.
“Creating body maps” by Verena Hafner
“Evolution: cognition from scratch” by Rolf Pfeifer
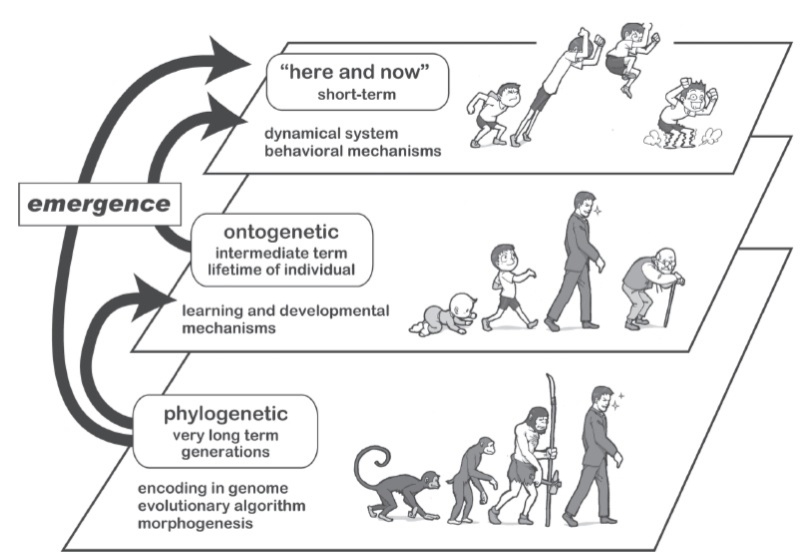
In the second talk, Rolf Pfeifer shows how evolutionary processes at different time scales drive the development of embodied intelligence in nature, and how they can be mimicked (with surprisingly good results) for the development of artificial systems, including … pipes and antennas!
How can we exploit Gene Regulatory Networks for the development of a new paradigm for robots?
Guest Lecture – “How can we test for artificial life? Complexity and computation in Nature” by Hector Zenil
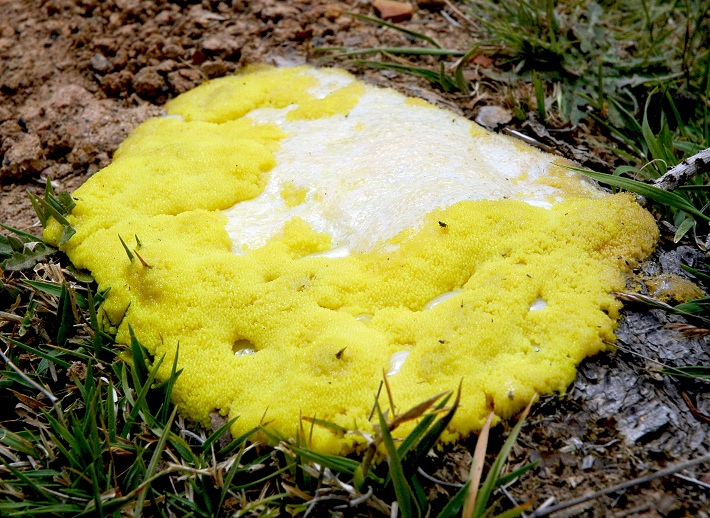
An unlikely yellow ‘computer’?
The skeptics will think that certain concepts such as ‘life’ or ‘self-organization’ are too elusive and ill-defined to be useful to AI. Hector Zeni, from the Karolinska Institute in Stockolm, Sweden, does cutting-edge research on the applications of Algorithmic Information Theory to the modeling of life and cognition. Witness how AIT might come to the rescue with this lecture, also hosted by Humboldt University Berlin …
About the ShanghAI Lectures
While in the classical approach “intelligence” was essentially viewed as information processing taking place in the brain, the more recent insight that interaction with the environment is of central importance is gaining acceptance. This has led to the metaphor of embodiment, i.e., that intelligence is always a property of an entire organism — an idea that has far-reaching implications and often leads to surprising insights, but which has not so far been widely exploited in industry practice.
The ShanghAI Lectures project aims to:
- Build a sustainable community of students and researchers in the area of Embodied Intelligence
- Make education and knowledge on cutting-edge scientific topics accessible to everyone
- Explore novel methods of knowledge transfer
- Overcome the complexity of a multi-cultural and interdisciplinary learning context
- Bring global teaching to a new level
These lectures about Natural and Artificial Intelligence have been held via videoconference at the University Carlos III of Madrid in Spain, the University of Zurich in Switzerland, Scuola Superiore Sant’Anna of Pisa, Italy, Humboldt University Berlin in Germany, University of Plymouth and University of Salford in the UK, and 10 other universities around the globe. Students from the participating universities are still working together on the exercises, using Webots by Cyberbotics, and Ludobots by the University of Vermont.
The lectures have also been streamed to allow remote participation to anybody.
The ShanghAI Lectures differ from ‘conventional’ MOOCs as they exploit telecommunication technology to build a global, distributed lecture hall that allows rich interaction rather than simply implementing the good old fashioned TV broadcasting model on a different medium. They also differ from other AI courses as they propose a new paradigm approach to embodied cognition (a.k.a. AI and Robotics). It is a kind of Copernican revolution with respect to GOFAI and its robotics application — and thus a research program for the coming decades.
This year I coordinated the lectures, with help from Prof. Rolf Pfeifer and Dr. Nathan Labhart at the University of Zurich . Rolf Pfeifer and I provided the context (introduction, moderation, and conclusion). As always, there were 2-3 invited guest lectures each week.
tags: AI-cognition, Embodied Cognition, lectures & seminars, research, Rolf Pfeifer, ShanghAI Lectures, ShanghAI Lectures 2013
AUAI is supported by:









