Robohub.org
 

The one-wheel Cubli


by and
30 June 2022


share this:

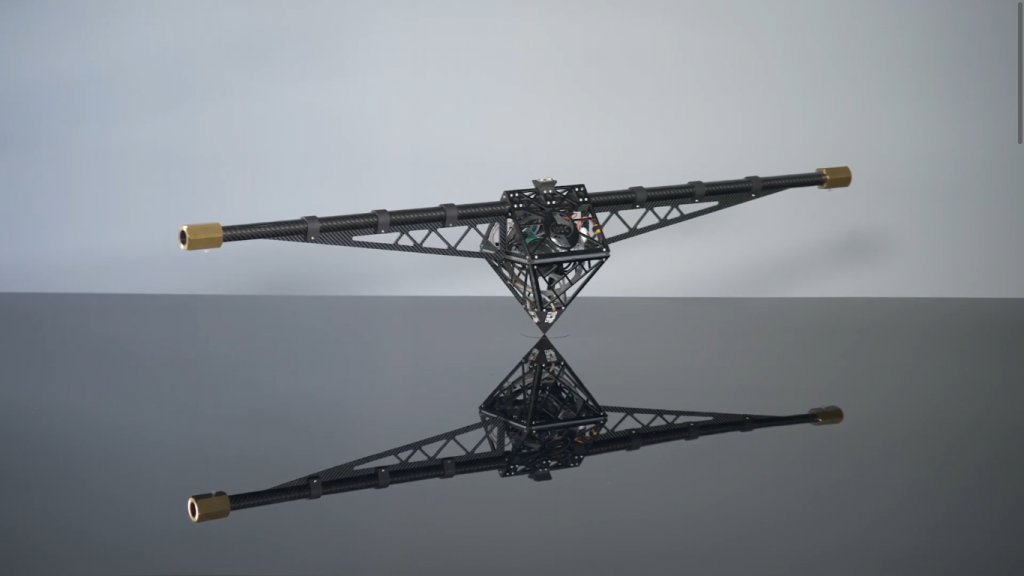
Researchers Matthias Hofer, Michael Muehlebach and Raffaello D’Andrea have developed the one-wheel Cubli, a three-dimensional pendulum system that can balance on its pivot using a single reaction wheel. How is it possible to stabilize the two tilt angles of the system with only a single reaction wheel?

The key is to design the system such that the inertia in one direction is higher than in the other direction by attaching two masses far away from the center. As a consequence, the system moves faster in the direction with the lower inertia and slower in the direction with the higher inertia. The controller can leverage this property and stabilize both directions simultaneously.

This work was carried out at the Institute for Dynamic Systems and Control, ETH Zurich, Switzerland.

Almost a decade has passed since the first Cubli

The Cubli robot started with a simple idea: Can we build a 15cm sided cube that can jump up, balance on its corner, and walk across our desk using off-the-shelf motors, batteries, and electronic components? The educational article Cubli – A cube that can jump up, balance, and walk across your desk shows all the design principles and prototypes that led to the development of the robot.
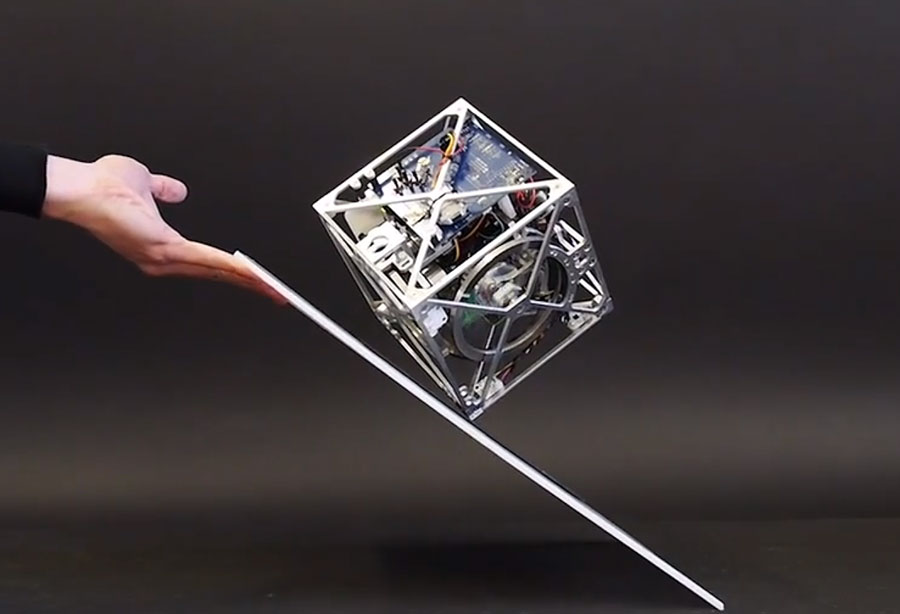
Cubli, from ETH Zurich.


tags:


ETH Zurich is one of the leading international universities for technology and the natural sciences.

Daniel Carrillo-Zapata was awared his PhD in swarm robotics at the Bristol Robotics Lab in 2020. He now fosters the culture of "scientific agitation" to engage in two-way conversations between researchers and society.

            AUAI is supported by:


Subscribe to Robohub newsletter on substack


Related posts :

Robot Talk Episode 170 – Robots in the real world, with Daniela Shchegelskaya

  13 Nov 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Daniela Shchegelskaya from the University of Twente about getting robots to operate reliably in safety-critical environments.

AI100 report released: embodied AI highlighted as grand challenge

  11 Nov 2026
Embodied AI is listed as one of the most inspiring open grand challenges.

AIhub coffee corner: Are humanoids the future of embodied AI?

  09 Nov 2026
The AIhub coffee corner captures the musings of AI experts over a short conversation.

Robot Talk Episode 169 – Robot sensing inspired by nature, with Dexter Shepherd

  06 Nov 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Dexter Shepherd from the University of Sussex about using artificial intelligence to help robots understand and adapt to their environment.

Robots in society, business and culture: October 2026

We showcase a selection of robotics stories from society, business, research and culture.

Muscle coordination can be mimicked by electric motors – it could lead to improved robots

  02 Nov 2026
Researchers built a physical model using ordinary electric motors to try and simulate how muscles may perform tasks.

Robot Talk Episode 168 – Advancing robotics with novel electronics, with Zlatka Stoeva

  30 Oct 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Zlatka Stoeva from DZP Technologies about flexible, stretchable and soft printed electronics for dexterous robots.

Competing in RoboCup@Home and winning the 2026 best paper award: an interview with Raphael Memmesheimer

and   28 Oct 2026
Hear more about Raphael's research and his involvement in the RoboCup@Home league.


↑


AUAI is supported by:


Subscribe to Robohub newsletter on substack


©2026.05 - Association for the Understanding of Artificial Intelligence