Robohub.org
 

The Year of CoCoRo Video #36/52: Relay swarm

by
08 September 2015


share this:

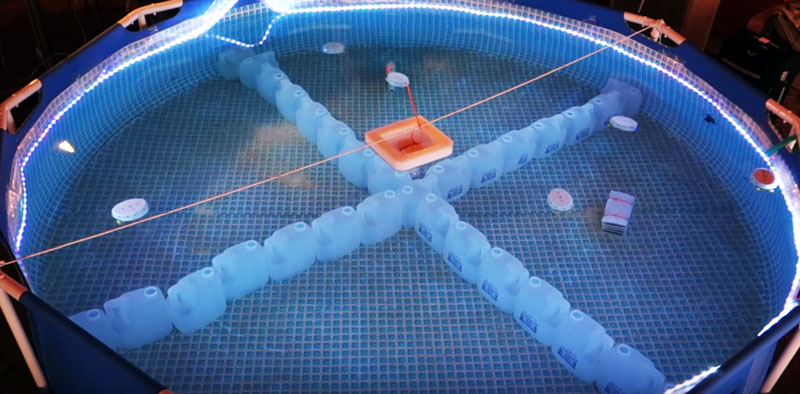
TYOC-36b-52--CoCoRo-RelaySwarm---YouTubeThe EU-funded Collective Cognitive Robotics (CoCoRo) project has built a swarm of 41 autonomous underwater vehicles (AVs) that show collective cognition. Throughout 2015 – The Year of CoCoRo – we’ll be uploading a new weekly video detailing the latest stage in its development. Over the last four posts we demonstrated how the robots use a relay chain to communicate between the sea ground and the surface station. The following two videos show an alternative to this communication principle. The “relay swarm” scenario uses a swarm of Lily robots performing random walks in 3D for transmitting information about the status of the search swarm of Jeff robots on the ground. 

This first video explains the scenario in a computer animation:

The second video shows the real-world experiments performed in the “relay swarm” scenario. First Jeff robots search the ground of a fragmented habitat for a magnetic target. As soon as it finds the target it signals this locally with blue-light LEDs. Lily robots that also roam the habitat can pick up the signal from this Jeff robot. The info can also spread from Lily robot to Lily robot as they meet, spreading like an infectious process. Finally, Lily robots inform the surface station that the Jeff robot on the ground has found an interesting target. Future extensions foresee that after informing the surface station another phase starts: a second signal spreads from the surface station through the Lily robots back to the Jeff robot on the ground, and ultimately makes the Jeff robot to go up to the surface above the found target.


tags: , , , , ,


Thomas Schmickl is an Associate Professor at Karl-Franzens University, Graz, Austria, and a lecturer at the University for Applied Sciences in St. Pölten, Austria.

            AUAI is supported by:


Subscribe to Robohub newsletter on substack


Related posts :

Robot Talk Episode 166 – Evolving robot bodies and brains, with Rika Antonova

  16 Oct 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Rika Antonova from the University of Cambridge about using artificial intelligence to develop complimentary robot hardware and algorithms.

Humanoid robots can sprint and box – but the real test is doing the laundry

  12 Oct 2026
No robot system can yet reliably handle the whole laundry process. Even folding remains a challenge.

Robot Talk Episode 165 – Robots behind the research, with Kushant Patel

  09 Oct 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Kushant Patel from Brookhaven National Laboratory about robots that work in scientific facilities, such as particle accelerators.

What three days building a robot taught me

and   07 Oct 2026
The brief sounded simple: build a small autonomous robot, then make it survive increasingly difficult mazes. Simple... right? Until you actually have to build one.

Research could guide the future design of social robots

  05 Oct 2026
Giving robot companions animal-like or anime-style faces and voices could maximise their emotional appeal to users, according to new research which could help guide the growing field of social robotics.

Robot Talk Episode 164 – Accelerating robot learning, with Michelle Lu

  02 Oct 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Michelle Lu from Vsim Technology about using simulation and artificial intelligence to teach robots new skills.

Robotics and automation? Informal reflections on familiar terms

IEEE experts reflect on what is meant by the term "robotics and automation".


↑


AUAI is supported by:


Subscribe to Robohub newsletter on substack


©2026.05 - Association for the Understanding of Artificial Intelligence