Robohub.org
 

The Year of CoCoRo Video #38/52: BEECLUST

by
22 September 2015


share this:

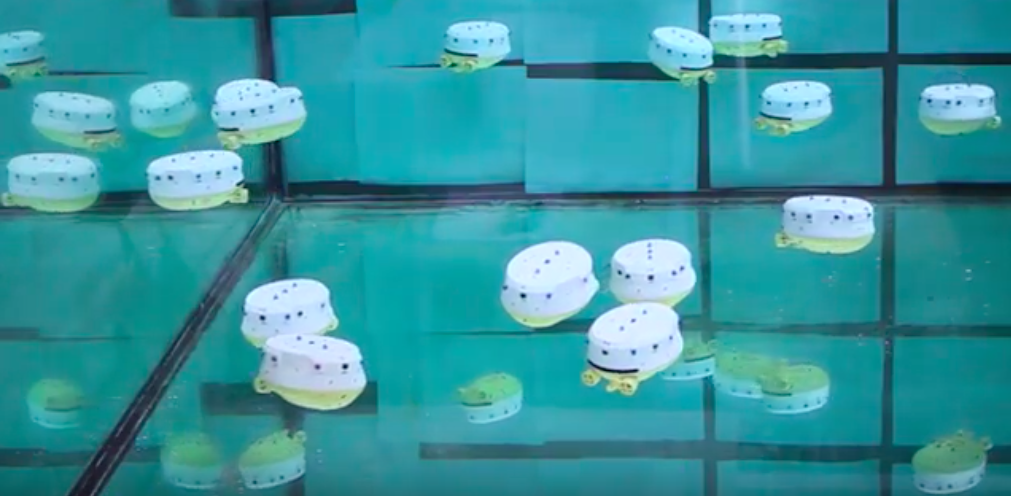
cocoro38b The EU-funded Collective Cognitive Robotics (CoCoRo) project has built a swarm of 41 autonomous underwater vehicles (AVs) that show collective cognition. Throughout 2015 – The Year of CooRo – we’ll be uploading a new weekly video detailing the latest stage in its development. This week we show an early laboratory experiment using the BEECLUST algorithm on a swarm of Lily robots.

The BEECLUST is a simple swarm algorithm derived from the walking and resting behavior of young honeybees, who can compare several temperature spots in their environment and collectively choose the optimal (warmest) spot. In our video, the algorithm was translated to underwater robots.

The robots move randomly in their habitat. When they meet another robot, they measure how deep the water below is. The more shallow the water, the longer they stay in place.

By running this algorithm, the swarm is able to identify shallow places and collectively choose the shallowest. The same algorithm can be used to find the deepest point, the darkest or the brightest, simply by correlating the resting time of the robots with other local environmental properties.

The BEECLUST is one of the simplest swarm algorithms possible, possibly even THE simplest. However, an algorithm like this does not suit every application: in our experiments we found that, in contrast to crawling honeybees in the hive or driving wheeled robots on the ground, it is very tricky for an AUV to stay in place in water because of drift and turbulence. Even in an aquarium this is an issue, with a number of robots moving around, so we concluded that, for a more turbulent underwater habitat, we needed a better algorithm than the classical BEECLUST.


tags: , , , , ,


Thomas Schmickl is an Associate Professor at Karl-Franzens University, Graz, Austria, and a lecturer at the University for Applied Sciences in St. Pölten, Austria.

            AUAI is supported by:


Subscribe to Robohub newsletter on substack


Related posts :

AIhub coffee corner: Are humanoids the future of embodied AI?

  09 Nov 2026
The AIhub coffee corner captures the musings of AI experts over a short conversation.

Robot Talk Episode 169 – Robot sensing inspired by nature, with Dexter Shepherd

  06 Nov 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Dexter Shepherd from the University of Sussex about using artificial intelligence to help robots understand and adapt to their environment.

Robots in society, business and culture: October 2026

We showcase a selection of robotics stories from society, business, research and culture.

Muscle coordination can be mimicked by electric motors – it could lead to improved robots

  02 Nov 2026
Researchers built a physical model using ordinary electric motors to try and simulate how muscles may perform tasks.

Robot Talk Episode 168 – Advancing robotics with novel electronics, with Zlatka Stoeva

  30 Oct 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Zlatka Stoeva from DZP Technologies about flexible, stretchable and soft printed electronics for dexterous robots.

Competing in RoboCup@Home and winning the 2026 best paper award: an interview with Raphael Memmesheimer

and   28 Oct 2026
Hear more about Raphael's research and his involvement in the RoboCup@Home league.

Robots in society, business and culture: September 2026

We showcase a selection of robotics stories from society, business, research and culture.

Robot Talk Episode 167 – Automating construction, with Jan Petrš

  23 Oct 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Jan Petrš from École Polytechnique Fédérale de Lausanne about novel robot designs for construction and architecture.


↑


AUAI is supported by:


Subscribe to Robohub newsletter on substack


©2026.05 - Association for the Understanding of Artificial Intelligence