
Robohub.org
Touchy subject: 3D printed fingertip ‘feels’ like human skin
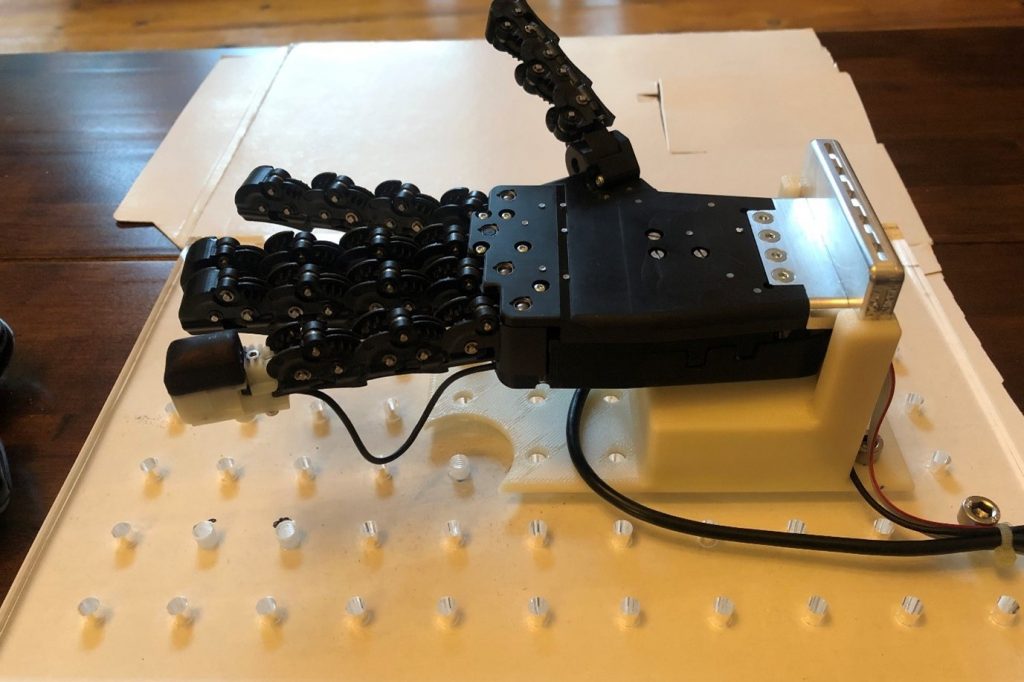
Robotic hand with a 3D-printed tactile fingertip on the little (pinky) finger. The white rigid back to the fingertip is covered with the black flexible 3D-printed skin.
Machines can beat the world’s best chess player, but they cannot handle a chess piece as well as an infant. This lack of robot dexterity is partly because artificial grippers lack the fine tactile sense of the human fingertip, which is used to guide our hands as we pick up and handle objects.
Two papers published in the Journal of the Royal Society Interface give the first in-depth comparison of an artificial fingertip with neural recordings of the human sense of touch. The research was led by Professor of Robotics & AI (Artificial Intelligence), Nathan Lepora, from the University of Bristol’s Department of Engineering Maths and based at the Bristol Robotics Laboratory.
“Our work helps uncover how the complex internal structure of human skin creates our human sense of touch. This is an exciting development in the field of soft robotics – being able to 3D-print tactile skin could create robots that are more dexterous or significantly improve the performance of prosthetic hands by giving them an in-built sense of touch,” said Professor Lepora.
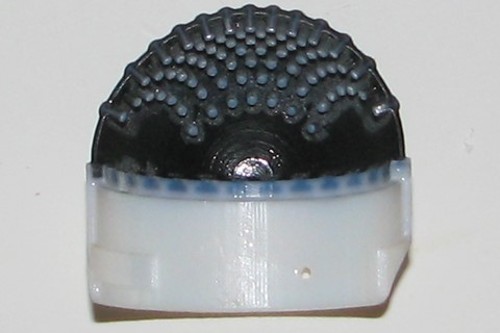
Cut-through section on the 3D-printed tactile skin. The white plastic is a rigid mount for the flexible black rubber skin. Both parts are made together on an advanced 3D-printer. The ‘pins’ on the inside of the skin replicate dermal papillae that are formed inside human skin.
Professor Lepora and colleagues created the sense of touch in the artificial fingertip using a 3D-printed mesh of pin-like papillae on the underside of the compliant skin, which mimic the dermal papillae found between the outer epidermal and inner dermal layers of human tactile skin. The papillae are made on advanced 3D-printers that can mix together soft and hard materials to create complicated structures like those found in biology.
“We found our 3D-printed tactile fingertip can produce artificial nerve signals that look like recordings from real, tactile neurons. Human tactile nerves transmit signals from various nerve endings called mechanoreceptors, which can signal the pressure and shape of a contact. Classic work by Phillips and Johnson in 1981 first plotted electrical recordings from these nerves to study ‘tactile spatial resolution’ using a set of standard ridged shapes used by psychologists. In our work, we tested our 3D-printed artificial fingertip as it ‘felt’ those same ridged shapes and discovered a startlingly close match to the neural data,” said Professor Lepora.
“For me, the most exciting moment was when we looked at our artificial nerve recordings from the 3D-printed fingertip and they looked like the real recordings from over 40 years ago! Those recordings are very complex with hills and dips over edges and ridges, and we saw the same pattern in our artificial tactile data,” said Professor Lepora.
While the research found a remarkably close match between the artificial fingertip and human nerve signals, it was not as sensitive to fine detail. Professor Lepora suspects this is because the 3D-printed skin is thicker than real skin and his team is now exploring how to 3D-print structures on the microscopic scale of human skin.
“Our aim is to make artificial skin as good – or even better – than real skin,” said Professor Lepora.
PAPERS
- Artificial SA-I, RA-I and RA-II/vibrotactile afferents for tactile sensing of texture. Nicholas Pestell and Nathan F. Lepora. Journal of The Royal Society Interface, 19, 20210603. http://doi.org/10.1098/rsif.2021.0603
- Artificial SA-I and RA-I afferents for tactile sensing of ridges and gratings. Nicholas Pestell, Thom Griffith and Nathan F. Lepora. Journal of The Royal Society Interface, 19, 20210822. https://doi.org/10.1098/rsif.2021.0822
tags: research
AUAI is supported by:










