Robohub.org
 

Watch this omnicopter fetch a ball

by
17 May 2017


share this:

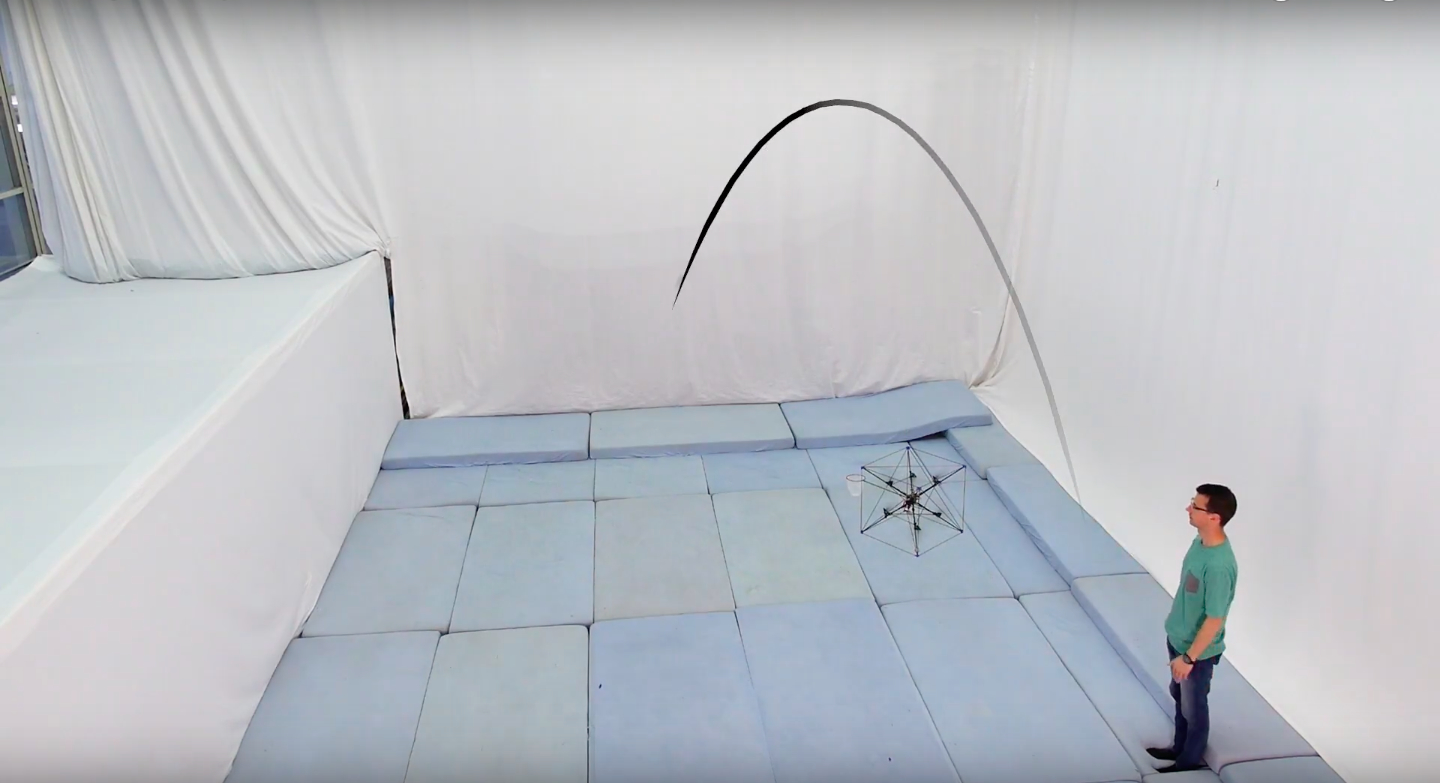
We have developed a computationally efficient trajectory generator for six degrees-of-freedom multirotor vehicles, i.e. vehicles that can independently control their position and attitude. The trajectory generator is capable of generating approximately 500’000 trajectories per second that guide the multirotor vehicle from any initial state, i.e. position, velocity and attitude, to any desired final state in a given time. In this video, we show an example application that requires the evaluation of a large number of trajectories in real time.

Multirotor vehicle

The multirotor vehicle used in the demonstration is an omni-directional eight-rotor vehicle. Its unique actuator configuration gives it full force and torque authority in all three dimensions, allowing it to fly novel maneuvers. For more details, please refer to the Youtube video or the research paper: “Design, Modeling and Control of an Omni-Directional Aerial Vehicle”, IEEE International Conference on Robotics and Automation (ICRA), 2016.

Researchers

Dario Brescianini and Raffaello D’Andrea
Institute for Dynamic Systems and Control (IDSC), ETH Zurich, Switzerland – http://www.idsc.ethz.ch

Location

Flying Machine Arena, ETH Zurich, Switzerland.

Acknowledgements

This work is supported by and builds upon prior contributions by numerous collaborators in the Flying Machine Arena project. See the list here. This research was supported by the Swiss National Science Foundation (SNSF).


tags: , , ,


Dario Brescianini began his PhD at the Institute of Dynamic Systems and Control at ETH Zürich.

            AUAI is supported by:


Subscribe to Robohub newsletter on substack


Related posts :

Soft exosuit makes it easier to stand up

Robotic system helps users stand up and walk more efficiently.

Robot swarms trained by trial and error in simulation keep working on real robots

  17 Nov 2026
Researchers have developed a new approach to reinforcement learning that helps robot swarms, allowing behaviours learned in simulation to transfer reliably to real-world robots.

Watch the IROS 2026 plenary and keynote talks

  16 Nov 2026
Catch up on the invited presentations from the International Conference on Intelligent Robots and Systems.

Robot Talk Episode 170 – Robots in the real world, with Daniela Shchegelskaya

  13 Nov 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Daniela Shchegelskaya from the University of Twente about getting robots to operate reliably in safety-critical environments.

AI100 report released: embodied AI highlighted as grand challenge

  11 Nov 2026
Embodied AI is listed as one of the most inspiring open grand challenges.

AIhub coffee corner: Are humanoids the future of embodied AI?

  09 Nov 2026
The AIhub coffee corner captures the musings of AI experts over a short conversation.

Robot Talk Episode 169 – Robot sensing inspired by nature, with Dexter Shepherd

  06 Nov 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Dexter Shepherd from the University of Sussex about using artificial intelligence to help robots understand and adapt to their environment.

Robots in society, business and culture: October 2026

We showcase a selection of robotics stories from society, business, research and culture.


↑


AUAI is supported by:


Subscribe to Robohub newsletter on substack


©2026.05 - Association for the Understanding of Artificial Intelligence