
Robohub.org
DALER: A bio-inspired robot that can both fly and walk
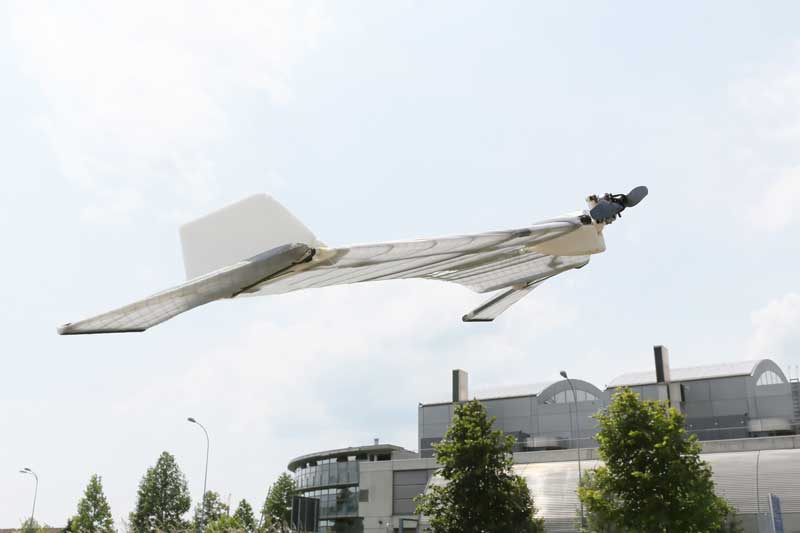
The DALER is a winged robot that can also walk.
The issue of how to use one robot across multiple terrains is an ongoing question in robotics research. In a paper published in Bioinspiration and Biomimetics today, a team from LIS, EPFL and NCCR Robotics propose a new kind of flying robot that can also walk. Called the DALER (Deployable Air-Land Exploration Robot), the robot uses adaptive morphology inspired by the common vampire bat, Desmodus rotundus, meaning that the wings have been actuated using a foldable skeleton mechanism covered with a soft fabric so that they can be used both as wings and as legs (whegs).
The DALER is being designed to be used in search and rescue operations, and its dual modes of locomotion will enable it to fly long distances to survey large spaces in a short timespan, and then to walk into dangerous or inaccessible areas.
One of the main problems in trying to get a flying robot to walk in small spaces is the surface areas of the wings. The wings of a flying robot must be wide in order to maintain flight, but this makes it difficult for them to fit into smaller spaces. After observing D. rotundus, the research team used a foldable actuator that allows the wings to fold into a smaller space, and to rotate around a hinge that attaches the whegs to the body in order to enable walking. D. rotundus doesn’t look very pretty when it walks, but it has certainly perfected the art of using all four limbs for two purposes.
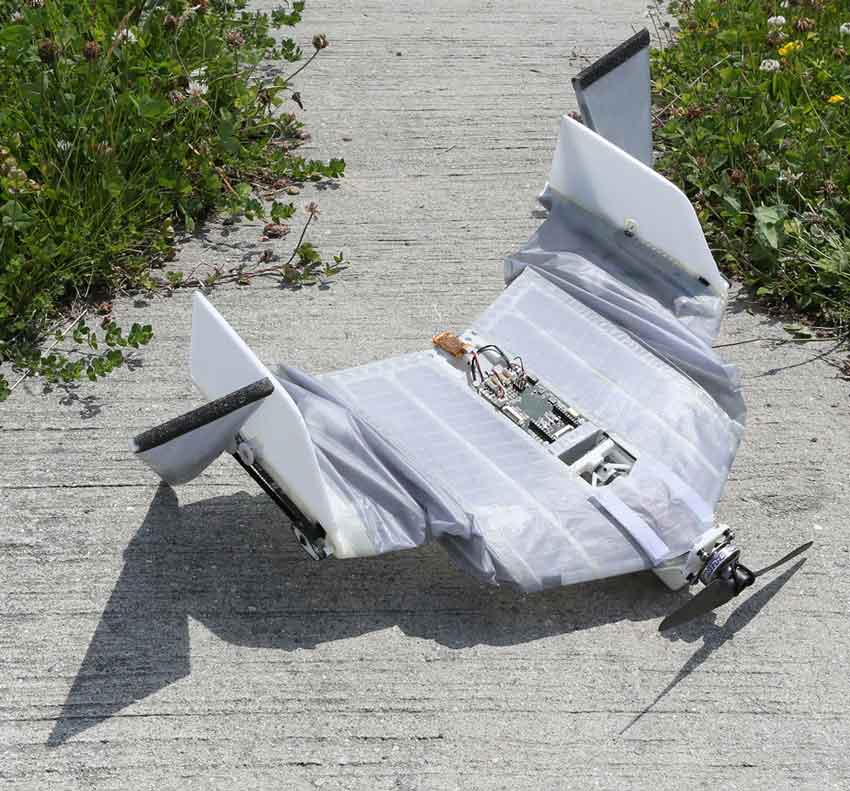
The DALER using its wings to walk. Wingerons at the end of the wings rotate to facilitate walking.
To design the robot, the team had to first designate the primary mode of locomotion – in this case flight, as the DALER will cover the longest distances this way. The wings were then adapted for walking, taking into consideration the need to not add extra weight when the DALER is in flight mode. The resulting wing is equipped with wingerons, with an axis of rotation close to their centre of aerodynamic pressure and physical centre, so as to satisfy the constraints of both ground locomotion and flight. The best shape found for these wingerons is a triangular one.
The addition of wingerons poses a problem regarding the use of actuators. Flight maneuverability requires rapid wingeron movements and low torque, whereas walking requires the opposite conditions. To cope with this problem, the DALER uses a terrestrial actuator configuration, but with an optimized wingeron size, to force the working point of flight control inside the operating range of the terrestrial actuator, while not compromising flight maneuverability.
A second issue in creating a fixed wing drone capable of walking on the ground is with the morphology, thanks to the different centre of mass requirements for the two modes of locomotion. For this reason the DALER is equipped with foldable wings, so, much like the bat that inspired it, the DALER can walk on its haunches. These adaptations mean that the DALER can reach 20m/s in the air and 6cm/s on the ground, with a maximum step distance of 6cm.
Researchers hope that in the future the DALER might be used to find victims in dangerous areas after a natural disaster, for example. They envision the DALER being remotely deployed to fly to an affected area, and then walking through a disaster zone (e.g. a damaged building) to locate victims so that human rescue teams can concentrate their efforts where they are needed, rather than using time to search for victims in a dangerous environment. Future development of the DALER will include the ability to hover and to take off autonomously from the ground – necessary features if the robot is to return safely to its home base after a mission.
If you liked this article, you may also be interested in:
- Multi-purpose wings allow flying robot to walk across rough terrain
- Robots Podcast: Origami robots
- Robot bodies and how to evolve them
- ShanghAI Lectures: Josh Bongard “Morphological Change in Machines Accelerates the Evolution of Robust Behavior”
- Robots Podcast: Bio-inspired locomotion
See all the latest robotics news on Robohub, or sign up for our weekly newsletter.
tags: bio-inspired, EPFL, LIS, research, Switzerland, UAVs & drones
AUAI is supported by:










