
Robohub.org
Push, pull, nudge: The control challenge of non-prehensile robotic manipulation
 In this new lecture series, controls expert Brian Douglas walks you through key concepts in control system theory. Focused on making control theory accessible and intuitive, this series is for anyone who wants to relate control concepts to robotic applications in the real world.
Presumably you are a human, an as such you have become really good at manipulating your environment by using your hands. You have these incredible actuators that allow you gently and nimbly grab an object, hold it tight, and then move it to a new location. So why wouldn’t you use your hands to grasp everything, and why wouldn’t you build a humanoid robot with hands so it could be as capable as you?
Well, this type of manipulation is called prehensile manipulation — or gasping manipulation — and it’s reasonable to expect a robot to be able to interact with the environment in this manner. However, you may not realize that as a human you are also performing a huge amount of non-prehensile manipulation everyday, both with and without your hands, such as pushing a swinging door open at the store, typing on your keyboard, or walking on two legs.
A robot that is expected to do well in our human built environment would need to be good at non-prehensile manipulation as well as the prehensile sort, and unfortunately it doesn’t always have a straightforward solution. The difficulty of getting a robot to move like a human was demonstrated at the DARPA Robotics Challenge (DRC), where the robot contestants were expected to perform activities like driving a car, opening a door, and closing a rotating valve. The robots successfully completed a number of very impressive feats, but it was also obvious from the number of robots falling down that we have a long way to go in our efforts to build a human-like robot; not the least of which is building agile bi-pedal robots.
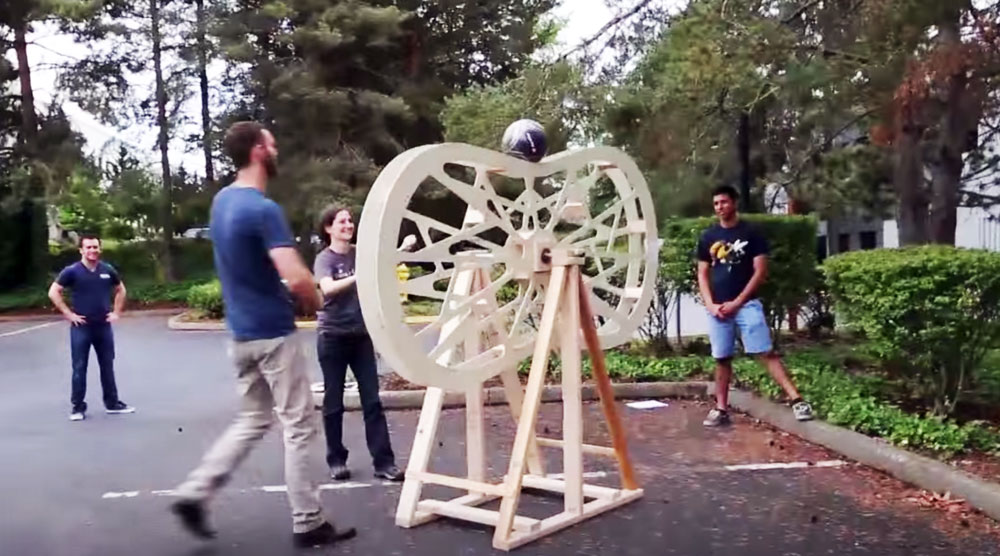
I was recently at the International Conference on Robotics and Automation (ICRA 2015) and I came across a very unassuming robot performing continuous non-prehensile manipulation of a ball around the edge of a butterfly-shaped link. Using a camera to sense the position of the ball, and a motor for actuation, the robot was able to continuously spin the butterfly shape while keeping the ball perched on top. Maksim Surov and Leonid Paramonov developed the algorithms that made this possible, and not only was their display mesmerizing, but their formalized approach to solving these types of problems could go to advancing our ability to generate continuous stability for an agile walking bipedal robot.
tags: control, ICRA 2015, research
AUAI is supported by:









