Robohub.org
 

Autonomous exploration planning using aerial robots

by and
23 May 2016


share this:
aerial-robot-robotics

Autonomous exploration of unknown environments corresponds to a critical ability and a major challenge for aerial robots. In many cases, we would like to rely on the ability of an intelligent flying system to completely and efficiently explore the previously unknown world and derive a consistent map of it. On top of this basic skill, one can then work on several tasks such as infrastructure inspection, hazard detection, and more.
Source: Kostas Alexis, UNR

Source: Dr Kostas Alexis, UNR

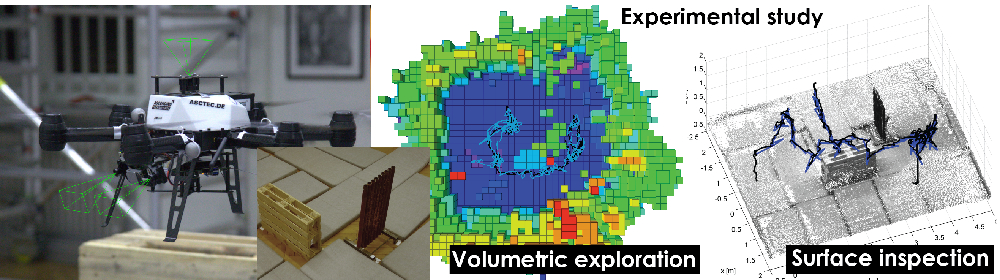
Our algorithm “Receding Horizon Next-Best-View Path Planning” is a recent contribution towards enabling the key goal of autonomous exploration. It achieves this by sampling finite-depth candidate paths within the environment, selecting the one that maximizes the amount of new space to be explored, and executes only the first step while then repeating the whole process in a receding horizon fashion. By performing multiple iterative steps of this process the space is fully and efficiently explored, and a volumetric representation is derived. Finally, one can afterwards launch a second mission for higher-fidelity surface inspection and more accurate 3D reconstruction of the environment.

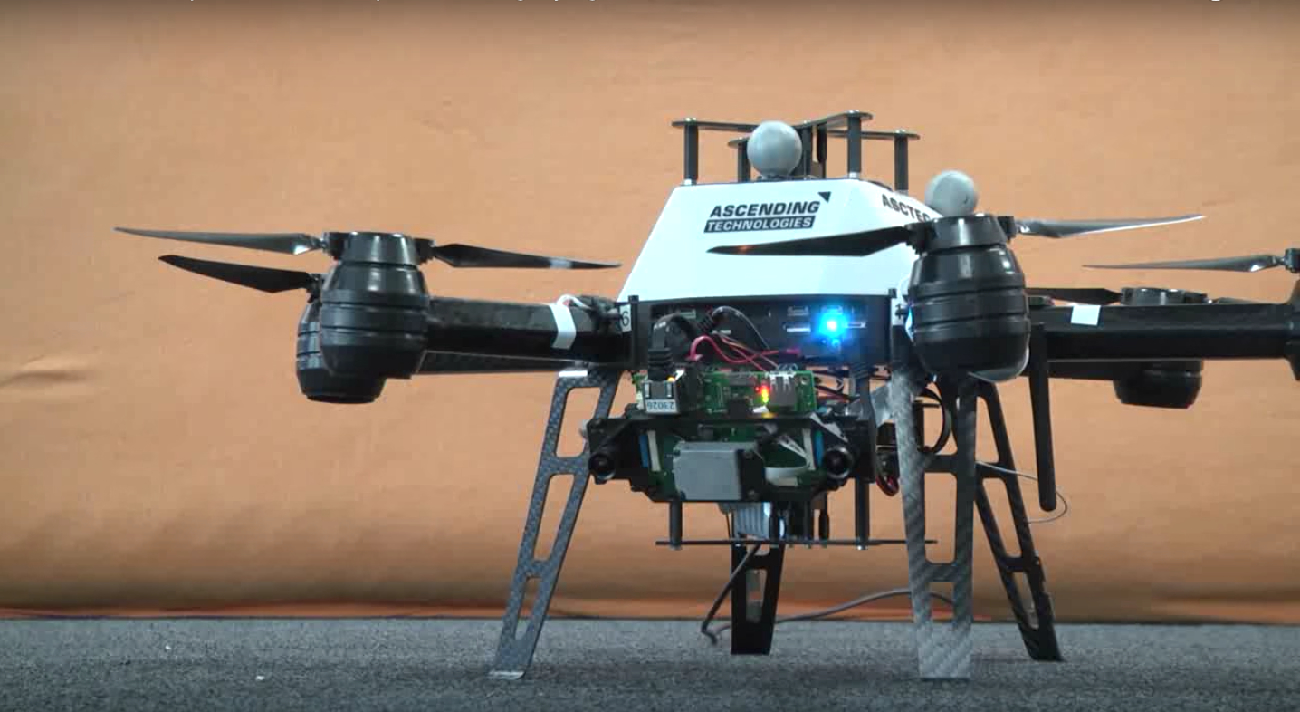
The algorithm has been experimentally verified with aerial robotic platforms equipped with a stereo visual-inertial system, as shown in our video:

Finally, to enable further developments, research collaboration and consistent comparison, we have released an open source version of our exploration planner, experimental datasets and interfaces to established simulation tools, including demo scenarios. To get the code, please visit: https://github.com/ethz-asl/nbvplanner/

This research was conducted at the Autonomous Systems Lab, ETH Zurich and the University of Nevada, Reno.


Reference:

  1. Bircher, M. Kamel, K. Alexis, H. Oleynikova, R. Siegwart, “Receding Horizon “Next-Best-View” Planner for 3D Exploration”, IEEE International Conference on Robotics and Automation 2016 (ICRA 2016), Stockholm, Sweden. Open-Source Git Repo: https://github.com/ethz-asl/nbvplanner


tags: ,


Kostas Alexis is an assistant professor at Computer Science & Engineering of the University of Nevada, Reno

Andreas Bircher is a research engineer at WingTra.

            AUAI is supported by:


Subscribe to Robohub newsletter on substack


Related posts :

Robot Talk Episode 167 – Automating construction, with Jan Petrš

  23 Oct 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Jan Petrš from École Polytechnique Fédérale de Lausanne about novel robot designs for construction and architecture.

ACM SIGAI Autonomous Agents Award 2027 open for nominations

  20 Oct 2026
Nominations are solicited for the 2027 ACM SIGAI Autonomous Agents Research Award.

Powered by muscle cells, a paper-thin robot swims through watery maze

  19 Oct 2026
MIT engineers’ new aquabot offers a way to design small, efficient “biohybrid” robots.

Robot Talk Episode 166 – Evolving robot bodies and brains, with Rika Antonova

  16 Oct 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Rika Antonova from the University of Cambridge about using artificial intelligence to develop complimentary robot hardware and algorithms.

Humanoid robots can sprint and box – but the real test is doing the laundry

  12 Oct 2026
No robot system can yet reliably handle the whole laundry process. Even folding remains a challenge.

Robot Talk Episode 165 – Robots behind the research, with Kushant Patel

  09 Oct 2026
In the latest episode of the Robot Talk podcast, Claire chatted to Kushant Patel from Brookhaven National Laboratory about robots that work in scientific facilities, such as particle accelerators.

What three days building a robot taught me

and   07 Oct 2026
The brief sounded simple: build a small autonomous robot, then make it survive increasingly difficult mazes. Simple... right? Until you actually have to build one.


↑


AUAI is supported by:


Subscribe to Robohub newsletter on substack


©2026.05 - Association for the Understanding of Artificial Intelligence